

Current Issue
Display Method:
2026, 51(8): 2927-2939.
doi: 10.3799/dqkx.2026.057
 PDF 5316KB
Abstract:
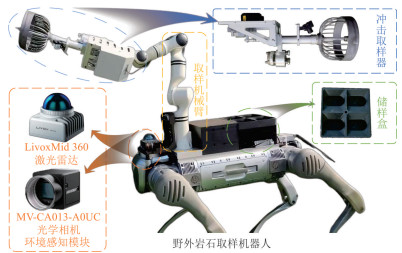
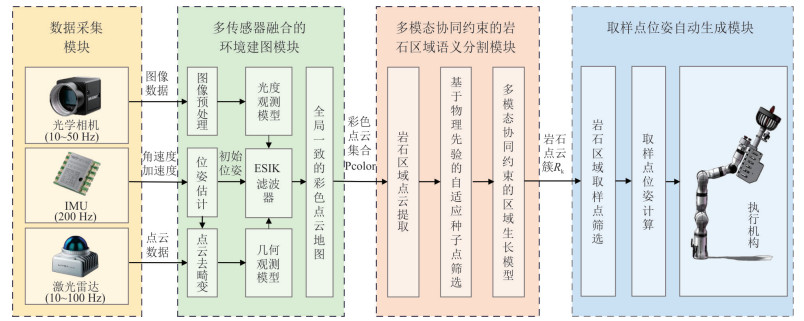
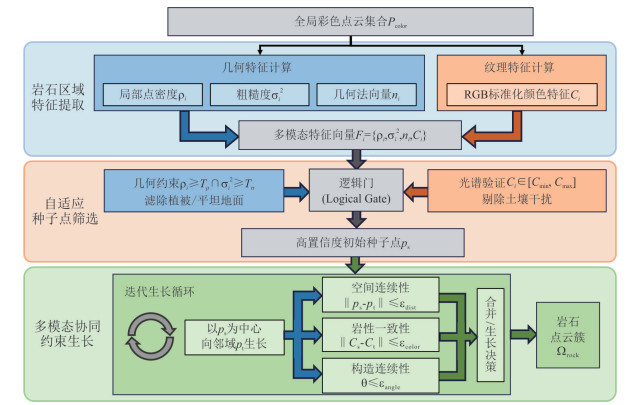
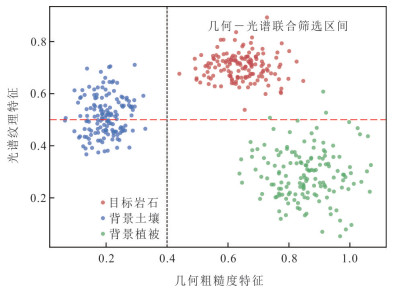
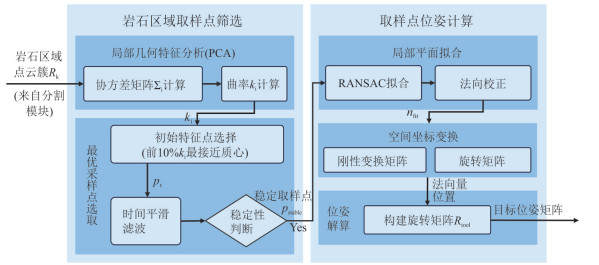
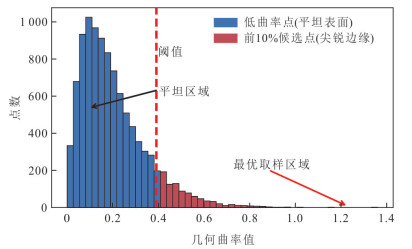
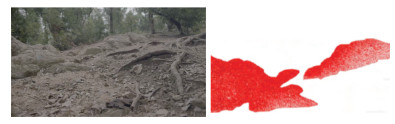
Rock-sampling robots are essential equipment for the intelligence of field geological exploration. However, in actual operations, robots face severe challenges such as unstructured field environments, intense illumination fluctuations, and highly variable rock lithology. Therefore, relying on a self-developed field rock-sampling robot platform, this paper proposes a multimodal fusion perception method for field environments to achieve high-precision segmentation of field rock regions and precise calculation of sampling poses. Addressing the issue of irregular terrain distribution, a multi-sensor fusion mapping method is employed to construct a 3D map with accurate geometric structures and rich texture colors. Based on this map, by integrating the geometric structures of point clouds with visual texture information, a multimodal collaborative constrained unsupervised rock segmentation algorithm is designed.This algorithm leverages physical priors to effectively overcome interference from drastic light changes and resolves the problem of insufficient annotated data caused by dynamic lithological variations. Furthermore, in light of the execution constraints of robotic sampling, an automated sampling-pose generation strategy is proposed. Through the parallel processes of local surface feature analysis of the rock region and kinematic constraint correction of the robot, the optimal sampling point is selected, enabling a precise mapping of the sampling point from the environmental space to the robotic operational space. Field experiments demonstrate that the rock segmentation accuracy reaches 89.57%, a significant improvement over the traditional region-growing method. Furthermore, the sampling-pose estimation achieves a mean position error of 0.696 cm and a normal vector error of 1.44°, which fulfills the precision requirements for autonomous rock sampling in the field.
Rock-sampling robots are essential equipment for the intelligence of field geological exploration. However, in actual operations, robots face severe challenges such as unstructured field environments, intense illumination fluctuations, and highly variable rock lithology. Therefore, relying on a self-developed field rock-sampling robot platform, this paper proposes a multimodal fusion perception method for field environments to achieve high-precision segmentation of field rock regions and precise calculation of sampling poses. Addressing the issue of irregular terrain distribution, a multi-sensor fusion mapping method is employed to construct a 3D map with accurate geometric structures and rich texture colors. Based on this map, by integrating the geometric structures of point clouds with visual texture information, a multimodal collaborative constrained unsupervised rock segmentation algorithm is designed.This algorithm leverages physical priors to effectively overcome interference from drastic light changes and resolves the problem of insufficient annotated data caused by dynamic lithological variations. Furthermore, in light of the execution constraints of robotic sampling, an automated sampling-pose generation strategy is proposed. Through the parallel processes of local surface feature analysis of the rock region and kinematic constraint correction of the robot, the optimal sampling point is selected, enabling a precise mapping of the sampling point from the environmental space to the robotic operational space. Field experiments demonstrate that the rock segmentation accuracy reaches 89.57%, a significant improvement over the traditional region-growing method. Furthermore, the sampling-pose estimation achieves a mean position error of 0.696 cm and a normal vector error of 1.44°, which fulfills the precision requirements for autonomous rock sampling in the field.
2026, 51(8): 2940-2950.
doi: 10.3799/dqkx.2026.024
Abstract:
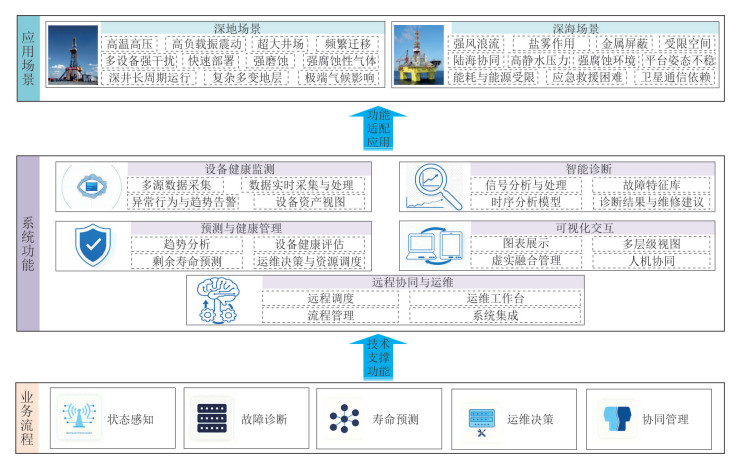
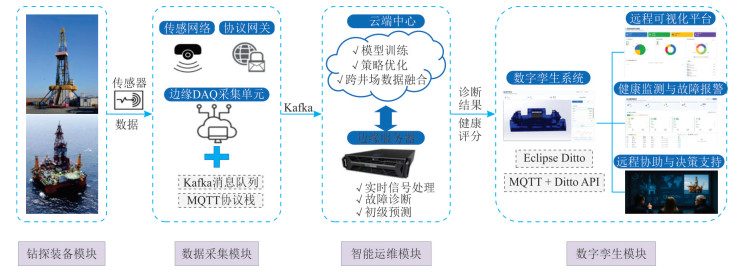
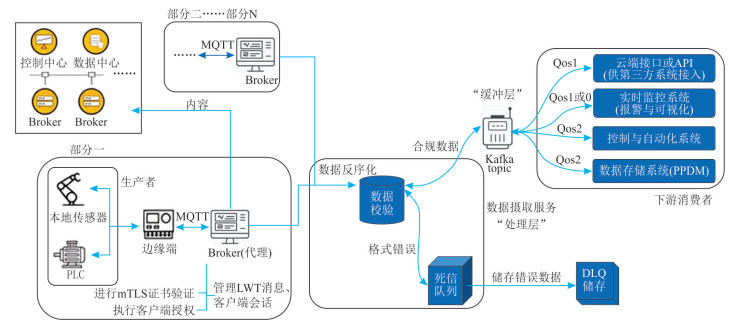
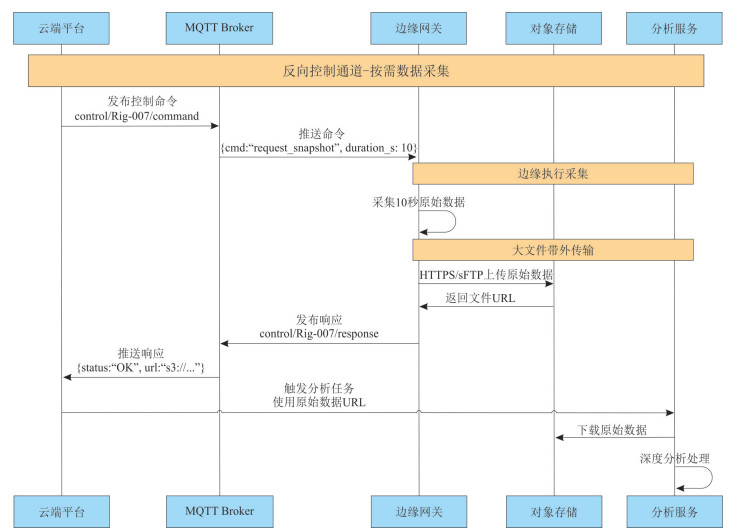
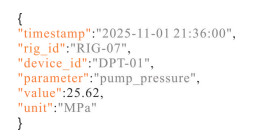
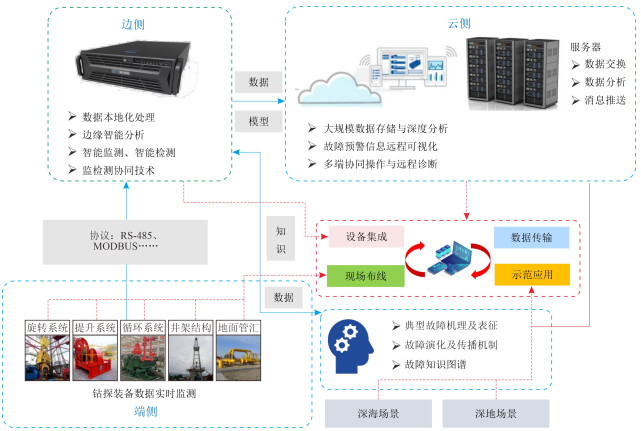
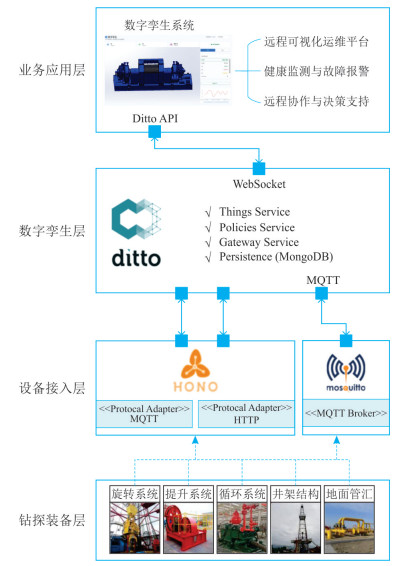
To improve the safe and reliable operation of deep drilling equipment under extreme working conditions, this study focuses on high-end drilling equipment that integrates automated execution, digital control, multi-source sensing, and high-reliability design. A cloud-edge-end collaborative intelligent operation and maintenance (O&M) architecture is developed. The proposed architecture consists of four modules, namely the drilling equipment module, the data acquisition module, the intelligent O&M module, and the digital twin module. A data workflow based on MQTT and Kafka is designed. A data modeling strategy is established through hierarchical topic classification and message schema specification. An edge-side feature reporting mechanism and a cloud-side on-demand data acquisition mechanism are further introduced to cope with network conditions characterized by low bandwidth, high latency, and intermittent connectivity. The architecture supports multi-source data access, unified deployment across multiple drilling sites, and remote visualization and interaction. It meets the requirements of equipment condition monitoring, fault diagnosis, and predictive maintenance, and provides a systematic reference for the design and implementation of intelligent O&M platforms for high-end drilling equipment.
To improve the safe and reliable operation of deep drilling equipment under extreme working conditions, this study focuses on high-end drilling equipment that integrates automated execution, digital control, multi-source sensing, and high-reliability design. A cloud-edge-end collaborative intelligent operation and maintenance (O&M) architecture is developed. The proposed architecture consists of four modules, namely the drilling equipment module, the data acquisition module, the intelligent O&M module, and the digital twin module. A data workflow based on MQTT and Kafka is designed. A data modeling strategy is established through hierarchical topic classification and message schema specification. An edge-side feature reporting mechanism and a cloud-side on-demand data acquisition mechanism are further introduced to cope with network conditions characterized by low bandwidth, high latency, and intermittent connectivity. The architecture supports multi-source data access, unified deployment across multiple drilling sites, and remote visualization and interaction. It meets the requirements of equipment condition monitoring, fault diagnosis, and predictive maintenance, and provides a systematic reference for the design and implementation of intelligent O&M platforms for high-end drilling equipment.
2026, 51(8): 2951-2966.
doi: 10.3799/dqkx.2026.121
Abstract:
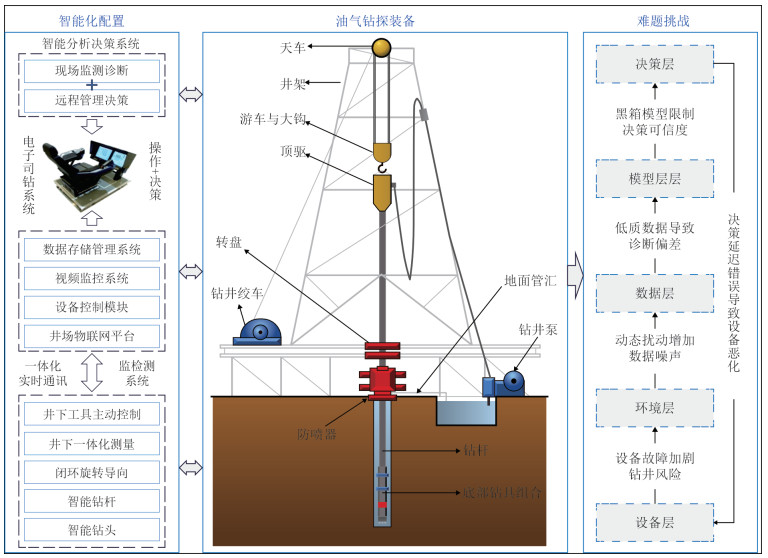
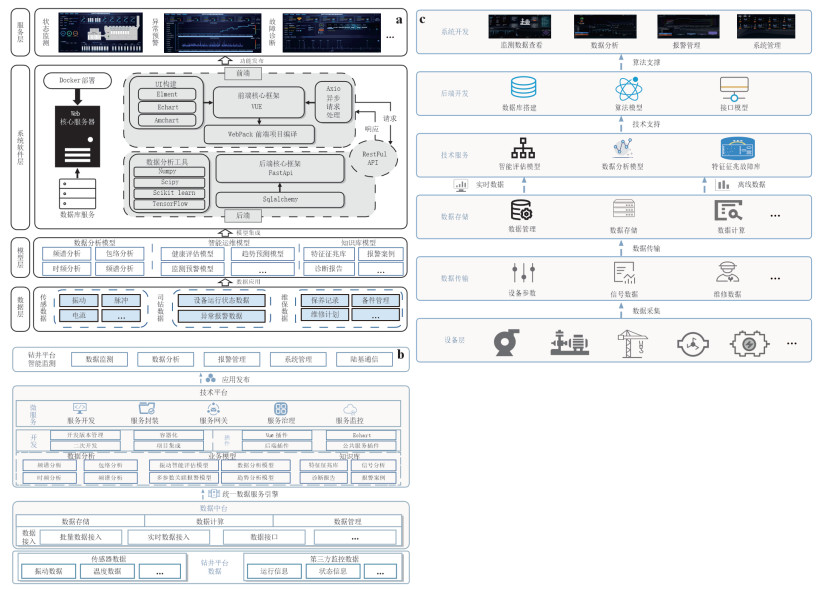
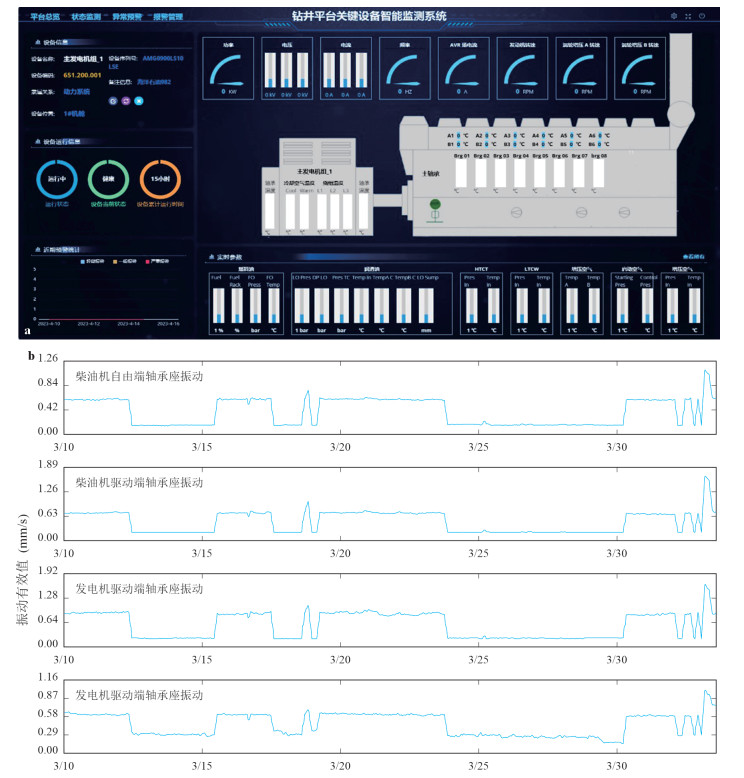
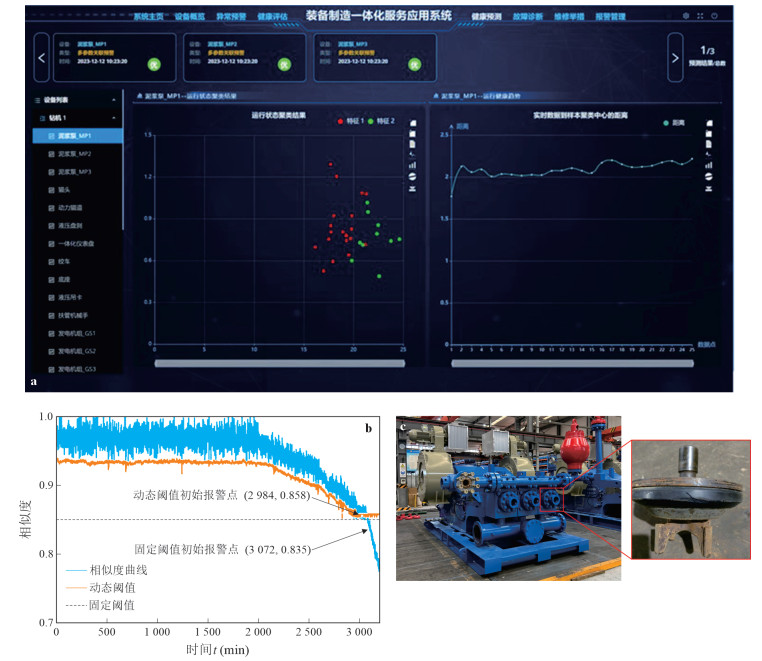
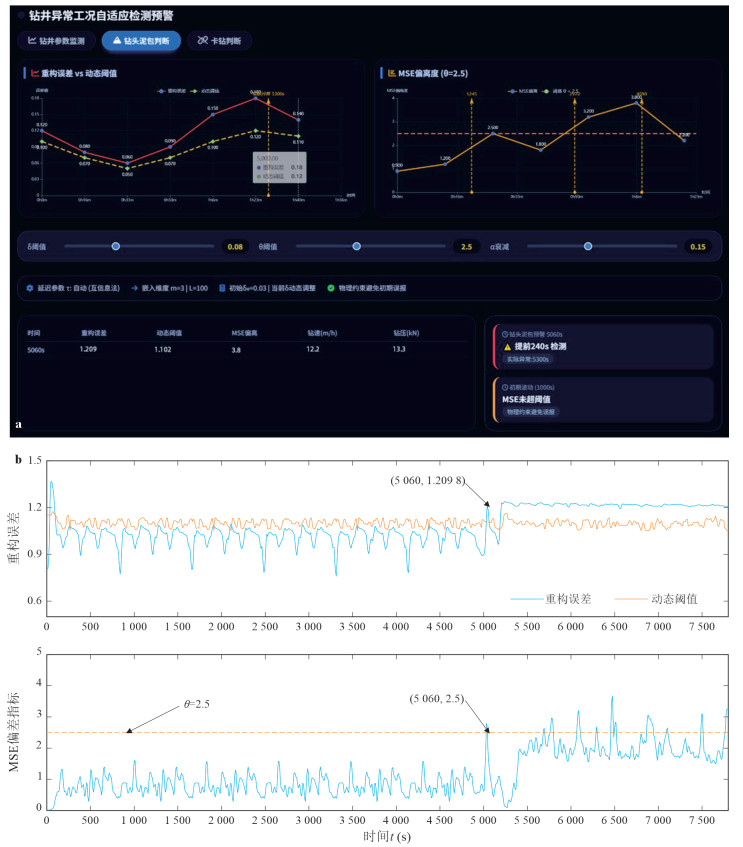
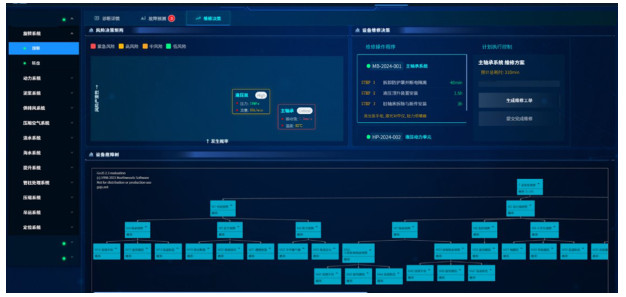
As the demand for deep and ultra-deep energy resource exploration continues to rise, high-end oil and gas drilling equipment faces significant challenges, including harsh environmental conditions, extreme operating scenarios, fault coupling, and maintenance difficulties. The current operation and maintenance practices largely rely on manual experience and periodic inspections, which fail to enable early fault prediction and timely response, leading to prominent safety concerns. To address the issues and challenges encountered during the operation and maintenance of high-end oil and gas drilling equipment, this paper proposes an innovative intelligent and safe operation and maintenance technology. Aiming for comprehensive, element-wide, and full life cycle operation and maintenance, the study constructs a closed-loop intelligent operation and maintenance process based on life cycle management and proactive maintenance optimization. By integrating digital empowerment technologies with domain-specific operation and maintenance technologies, the approach promotes the transformation from traditional to intelligent and safe operation and maintenance models for oil and gas drilling equipment. An intelligent and safe operation and maintenance system for drilling equipment is developed, incorporating functional modules for condition monitoring, health assessment, fault diagnosis, and intelligent decision-making. The system is successfully applied to the intelligent operation and maintenance of drilling equipment on an offshore drilling platform, providing a valuable reference for the rapid application of intelligent and safe operation and maintenance technologies in the oil and gas industry.
As the demand for deep and ultra-deep energy resource exploration continues to rise, high-end oil and gas drilling equipment faces significant challenges, including harsh environmental conditions, extreme operating scenarios, fault coupling, and maintenance difficulties. The current operation and maintenance practices largely rely on manual experience and periodic inspections, which fail to enable early fault prediction and timely response, leading to prominent safety concerns. To address the issues and challenges encountered during the operation and maintenance of high-end oil and gas drilling equipment, this paper proposes an innovative intelligent and safe operation and maintenance technology. Aiming for comprehensive, element-wide, and full life cycle operation and maintenance, the study constructs a closed-loop intelligent operation and maintenance process based on life cycle management and proactive maintenance optimization. By integrating digital empowerment technologies with domain-specific operation and maintenance technologies, the approach promotes the transformation from traditional to intelligent and safe operation and maintenance models for oil and gas drilling equipment. An intelligent and safe operation and maintenance system for drilling equipment is developed, incorporating functional modules for condition monitoring, health assessment, fault diagnosis, and intelligent decision-making. The system is successfully applied to the intelligent operation and maintenance of drilling equipment on an offshore drilling platform, providing a valuable reference for the rapid application of intelligent and safe operation and maintenance technologies in the oil and gas industry.
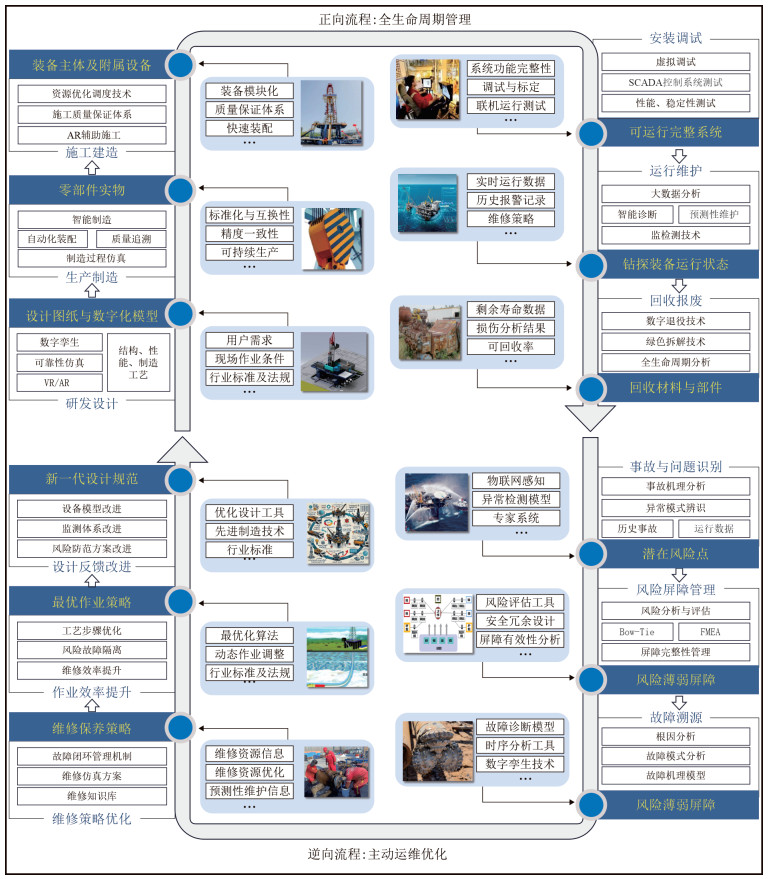
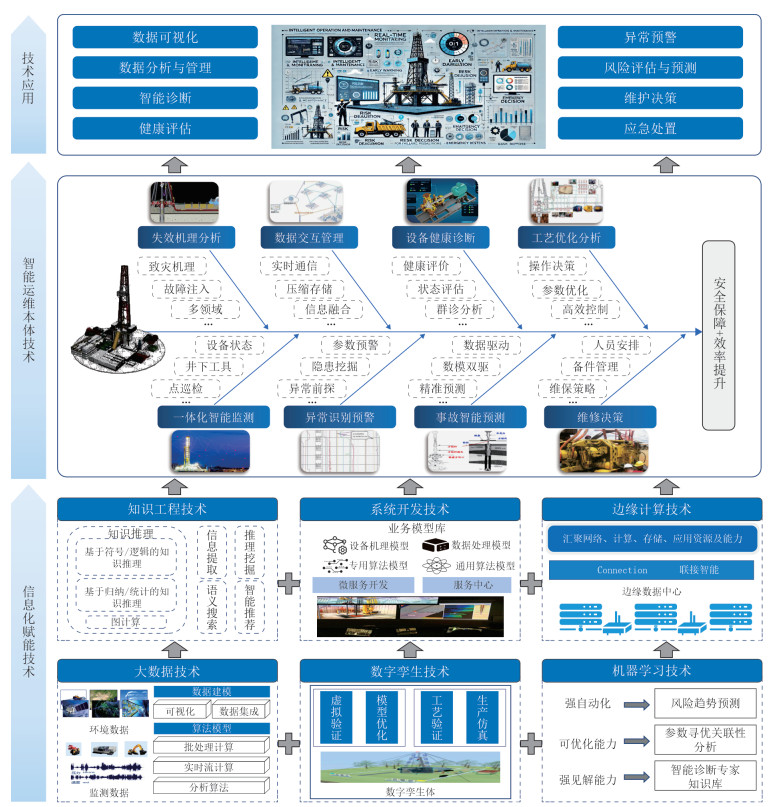
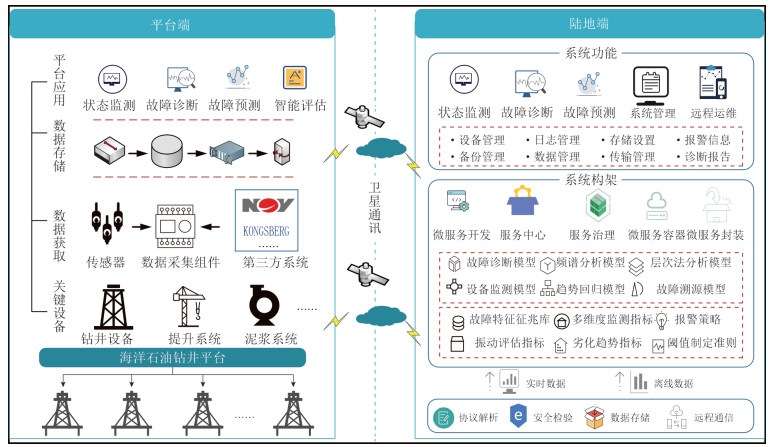
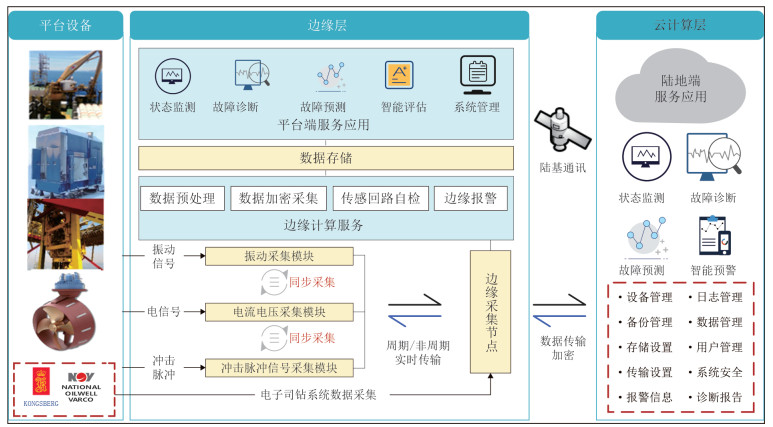
2026, 51(8): 2967-2976.
doi: 10.3799/dqkx.2026.245
Abstract:
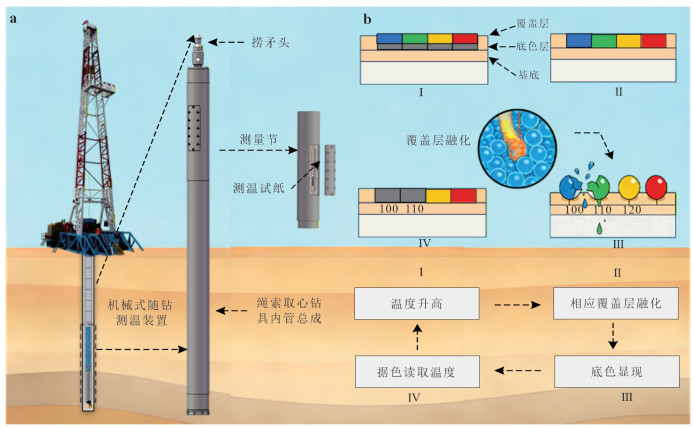
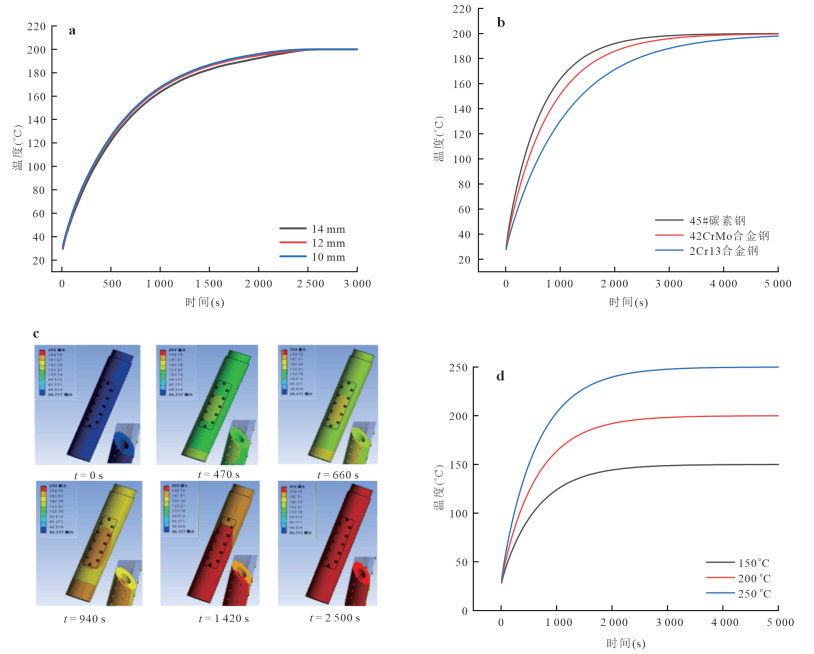
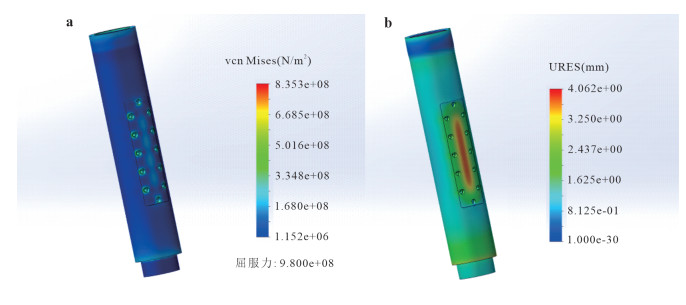
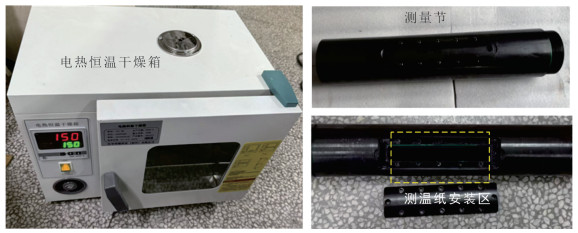
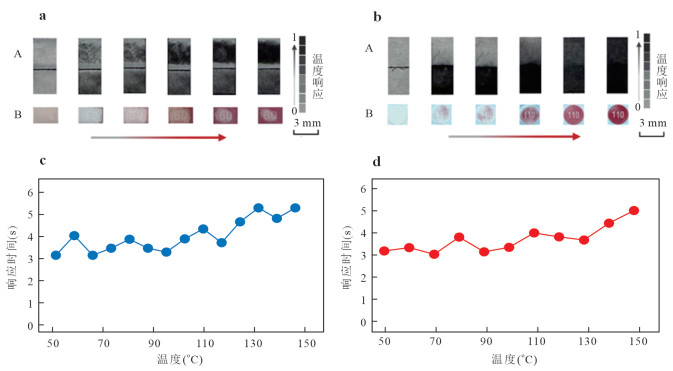
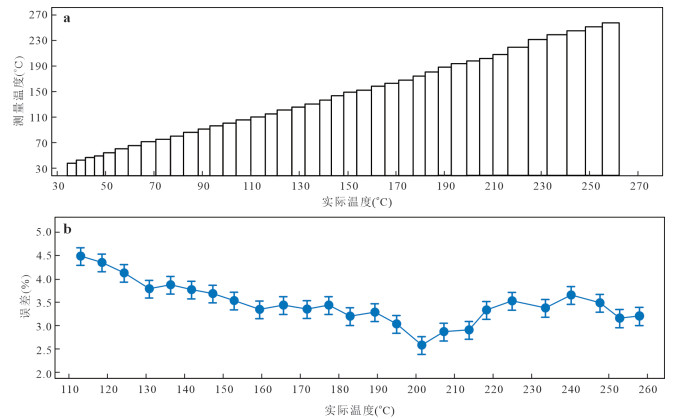
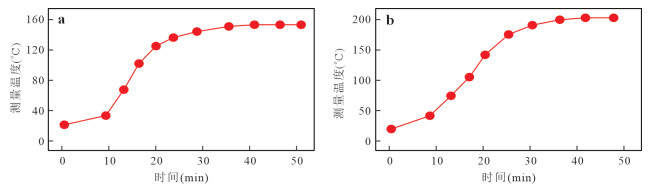
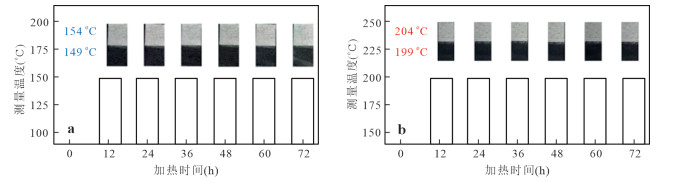
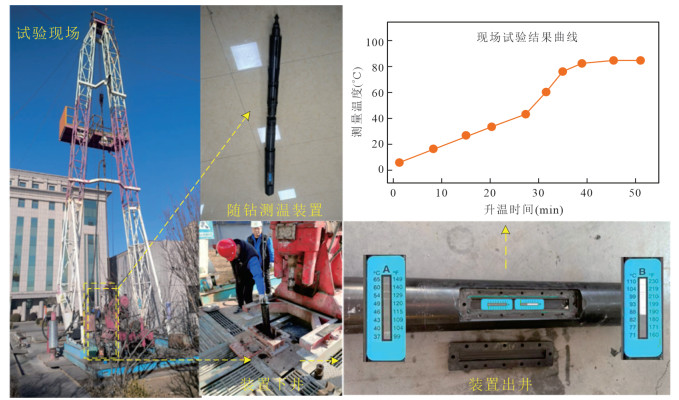
To address the failure of electronic temperature-measurement devices caused by extreme downhole temperatures in ultra-deep (10, 000-m-class) drilling, this study developed a mechanical temperature-measurement device for while-drilling applications based on an irreversible thermo-chromic (heat-sensitive color-development) principle. Integrated into the inner-tube assembly of a wireline coring drill, the device uses a color-developing coating composed of materials with specified melting points to record the maximum downhole temperature reached. After retrieval of the inner-tube assembly to the surface using an overshot, the temperature record can be read. Experimental results show that the device measures temperatures from 37 to 260 ℃, with measurement errors below 5% in the 110–260 ℃ range. The resolution is 3 ℃ from 37 to 65 ℃ and 6 ℃ from 65 to 260 ℃. In addition, the device requires about 30 minutes to reach thermal equilibrium for stable measurement, and a 72-hour constant-temperature test verified its excellent stability. Because it contains no electronic components, the mechanical device avoids the high-temperature limitations of ultra-deep wells and provides an effective method for while-drilling bottom-hole temperature measurement in drilling projects exceeding 10, 000 meters.
To address the failure of electronic temperature-measurement devices caused by extreme downhole temperatures in ultra-deep (10, 000-m-class) drilling, this study developed a mechanical temperature-measurement device for while-drilling applications based on an irreversible thermo-chromic (heat-sensitive color-development) principle. Integrated into the inner-tube assembly of a wireline coring drill, the device uses a color-developing coating composed of materials with specified melting points to record the maximum downhole temperature reached. After retrieval of the inner-tube assembly to the surface using an overshot, the temperature record can be read. Experimental results show that the device measures temperatures from 37 to 260 ℃, with measurement errors below 5% in the 110–260 ℃ range. The resolution is 3 ℃ from 37 to 65 ℃ and 6 ℃ from 65 to 260 ℃. In addition, the device requires about 30 minutes to reach thermal equilibrium for stable measurement, and a 72-hour constant-temperature test verified its excellent stability. Because it contains no electronic components, the mechanical device avoids the high-temperature limitations of ultra-deep wells and provides an effective method for while-drilling bottom-hole temperature measurement in drilling projects exceeding 10, 000 meters.
2026, 51(8): 2977-2989.
doi: 10.3799/dqkx.2025.274
Abstract:
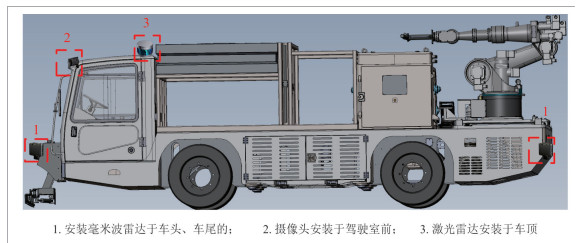
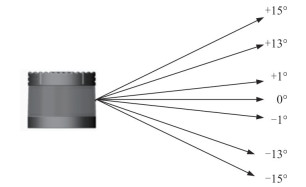
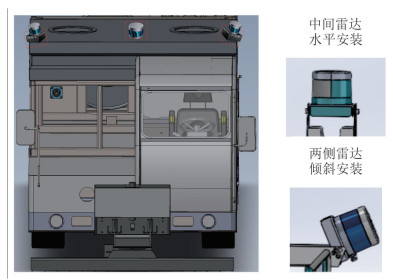
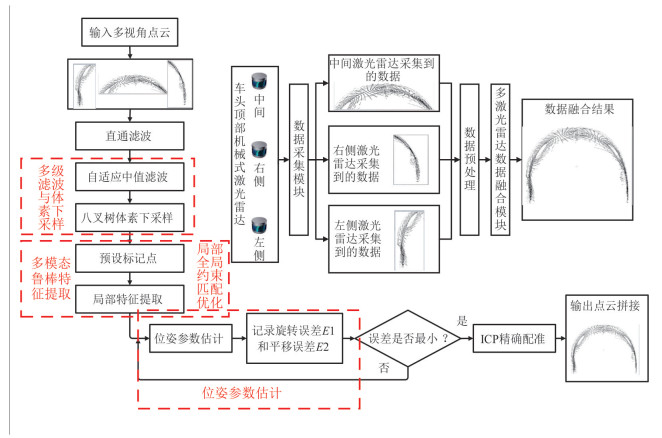
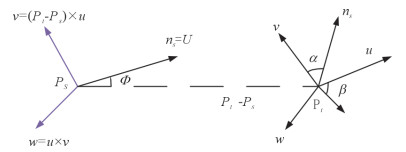
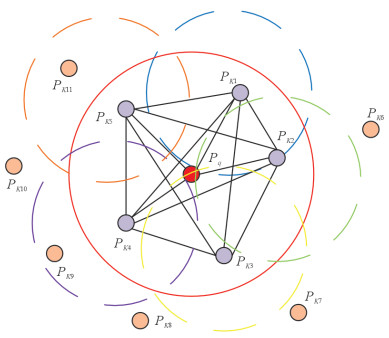
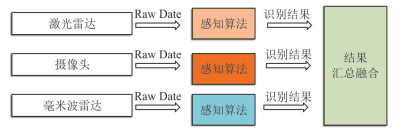
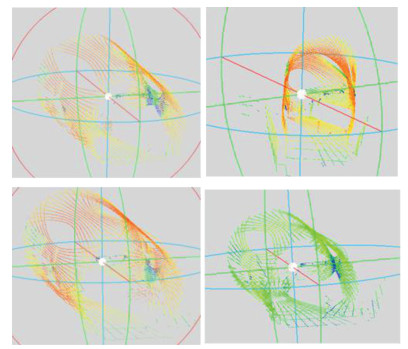
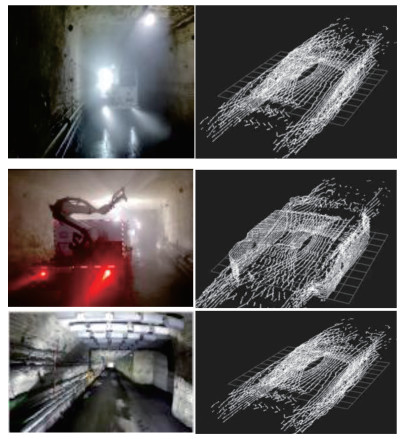
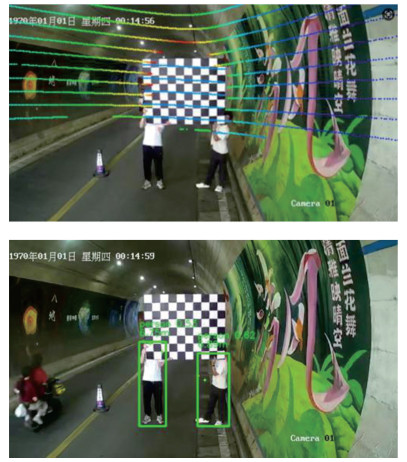
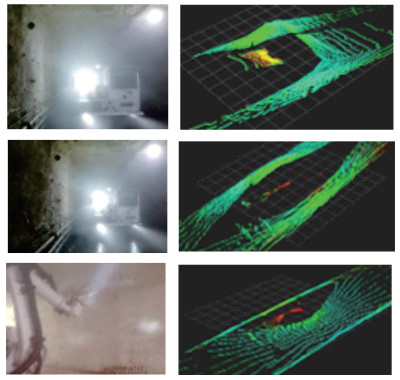
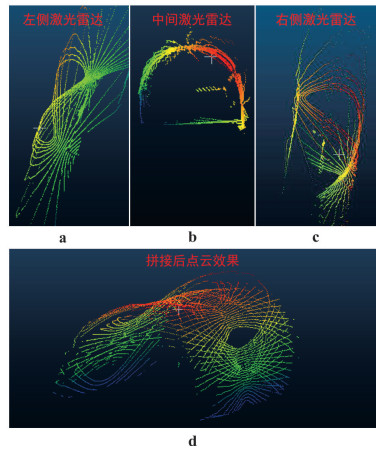
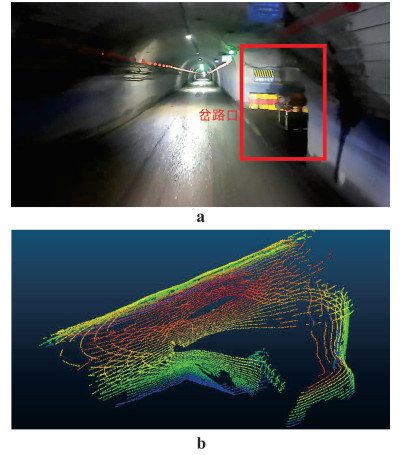
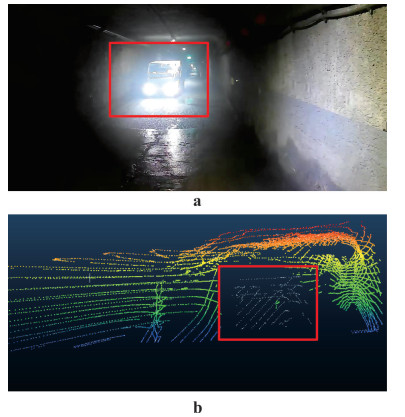
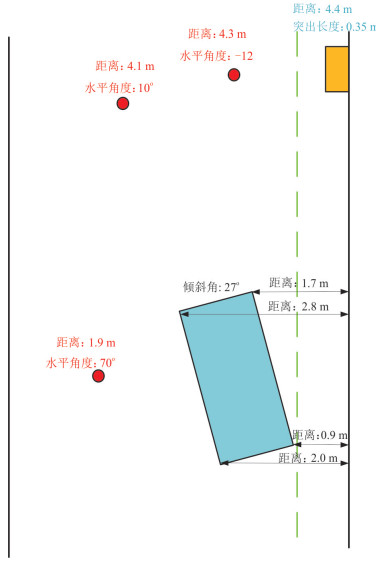
As a crucial energy resource, coal mines are characterized by complex structures, confined spaces, and insufficient illumination in their underground environments, posing significant challenges to fine-grained 3D perception and modeling. High-precision 3D reconstruction is not only a key factor in ensuring mining operation safety but also serves as an essential foundation for analyzing stratigraphic structures, constructing transparent geological systems, and monitoring dynamic environments. To address the limitations of traditional single-sensor approaches in underground scenarios, such as severe occlusion, high noise interference, and limited modeling accuracy: this paper proposes a multi-sensor fusion-based 3D modeling method. The approach involves deploying a multi-line LiDAR array on a roadway cleaning vehicle and integrating visual and millimeter-wave radar data. By employing an automatic stitching strategy that combines local feature description and parameter estimation, stable geometric and texture features from multi-source data are extracted. A two-stage fusion method is adopted, which integrates initial registration based on feature matching and fine registration optimized via probability distribution, effectively overcoming matching ambiguities caused by repetitive structures, dynamic interference, and varying lighting conditions in underground environments. This process progressively constructs a global 3D model of the underground roadway. Experimental results demonstrate that the proposed method achieves an average registration error of less than 0.12 m in coal mine roadway environments, improves stitching efficiency by approximately 47% compared to conventional methods, and reaches a target recognition accuracy of 92.7%. The findings confirm that multi-source information fusion significantly enhances the accuracy and robustness of 3D modeling in underground coal mines, providing reliable data support and technical reference for intelligent stratigraphic modeling, transparent geological construction, and the advancement of smart mining.
As a crucial energy resource, coal mines are characterized by complex structures, confined spaces, and insufficient illumination in their underground environments, posing significant challenges to fine-grained 3D perception and modeling. High-precision 3D reconstruction is not only a key factor in ensuring mining operation safety but also serves as an essential foundation for analyzing stratigraphic structures, constructing transparent geological systems, and monitoring dynamic environments. To address the limitations of traditional single-sensor approaches in underground scenarios, such as severe occlusion, high noise interference, and limited modeling accuracy: this paper proposes a multi-sensor fusion-based 3D modeling method. The approach involves deploying a multi-line LiDAR array on a roadway cleaning vehicle and integrating visual and millimeter-wave radar data. By employing an automatic stitching strategy that combines local feature description and parameter estimation, stable geometric and texture features from multi-source data are extracted. A two-stage fusion method is adopted, which integrates initial registration based on feature matching and fine registration optimized via probability distribution, effectively overcoming matching ambiguities caused by repetitive structures, dynamic interference, and varying lighting conditions in underground environments. This process progressively constructs a global 3D model of the underground roadway. Experimental results demonstrate that the proposed method achieves an average registration error of less than 0.12 m in coal mine roadway environments, improves stitching efficiency by approximately 47% compared to conventional methods, and reaches a target recognition accuracy of 92.7%. The findings confirm that multi-source information fusion significantly enhances the accuracy and robustness of 3D modeling in underground coal mines, providing reliable data support and technical reference for intelligent stratigraphic modeling, transparent geological construction, and the advancement of smart mining.
2026, 51(8): 2990-3003.
doi: 10.3799/dqkx.2026.197
Abstract:
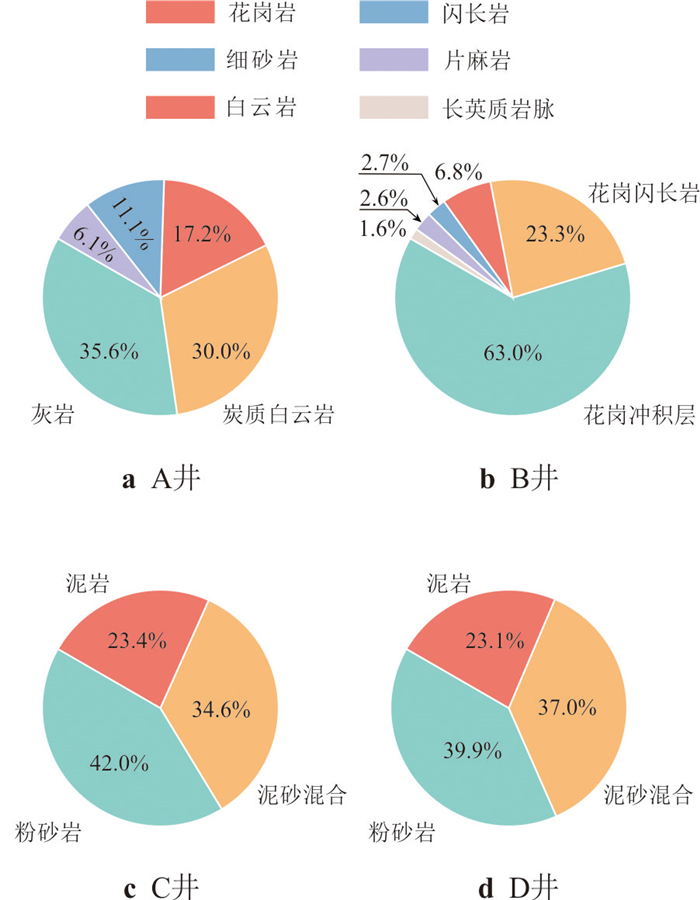
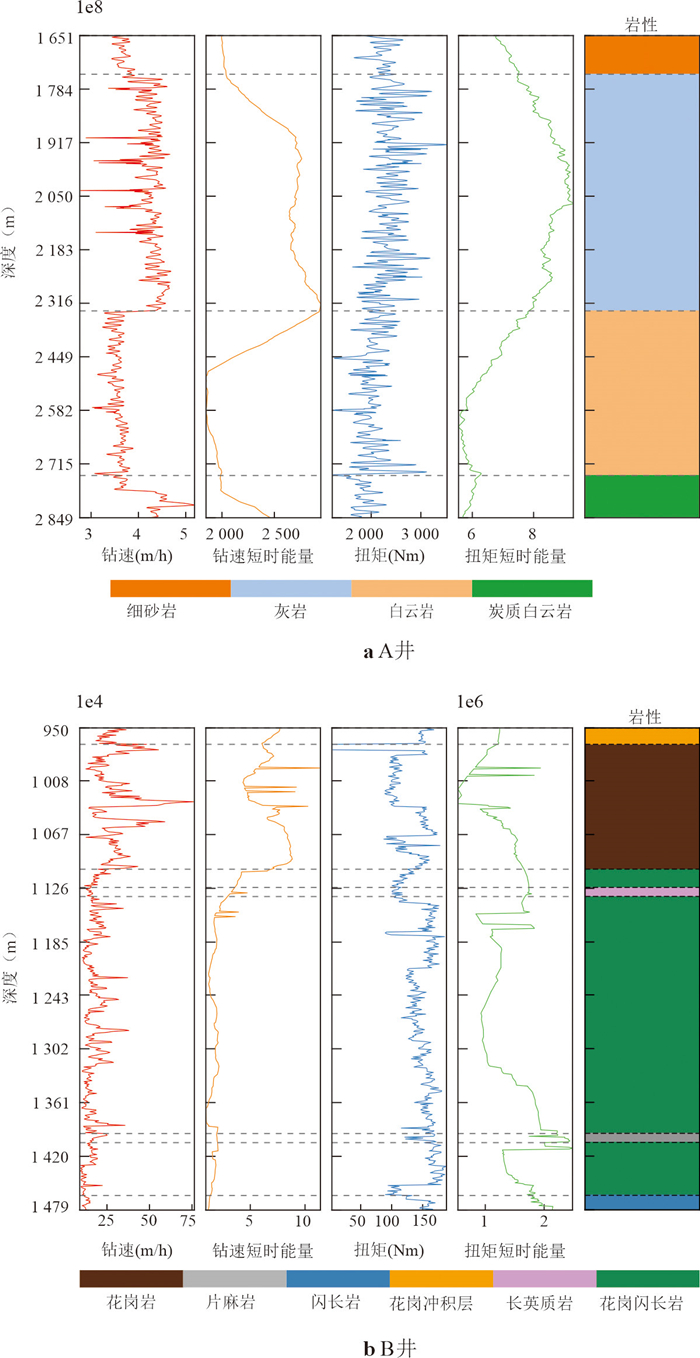
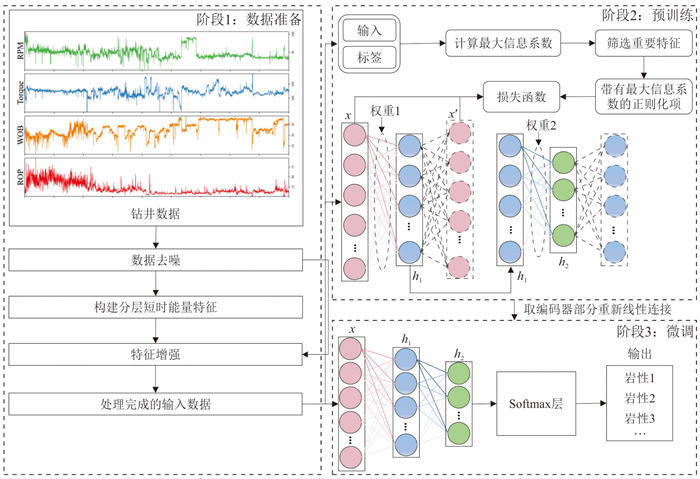
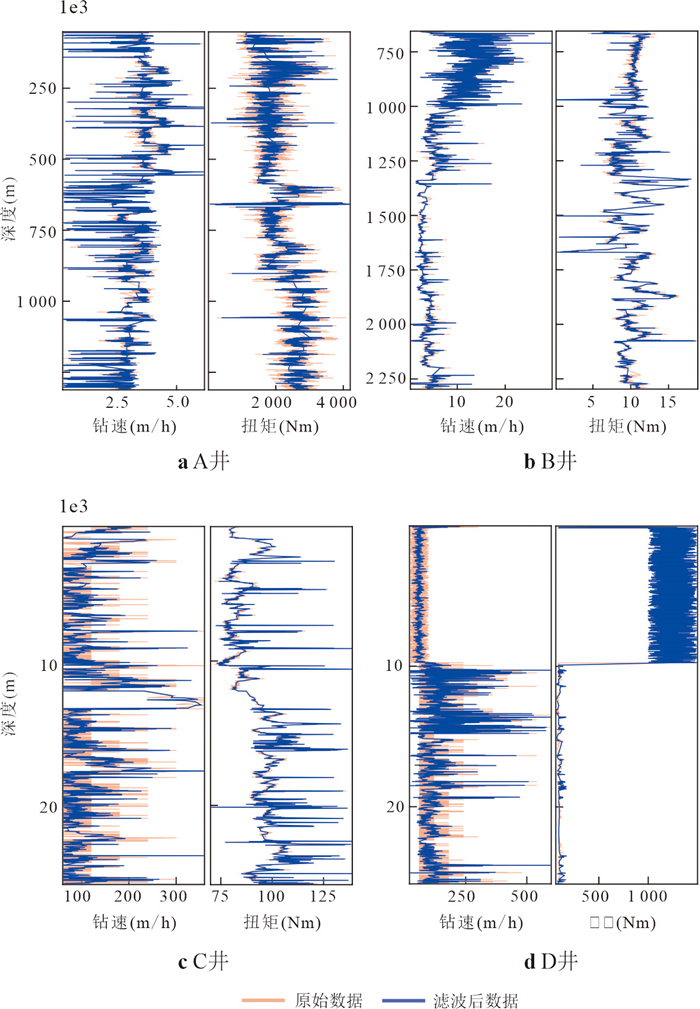
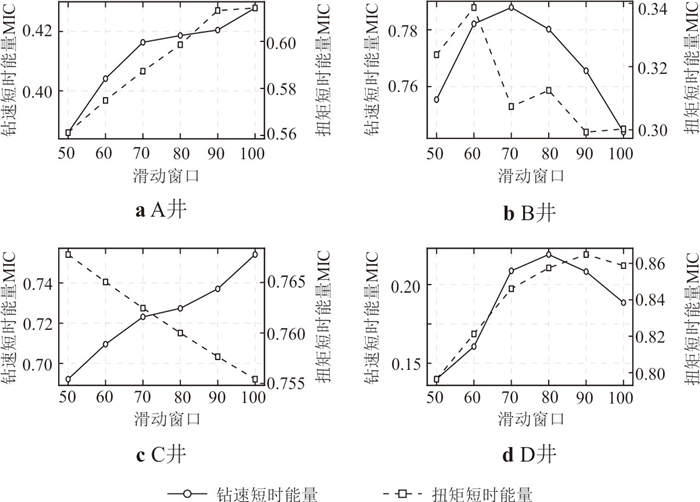
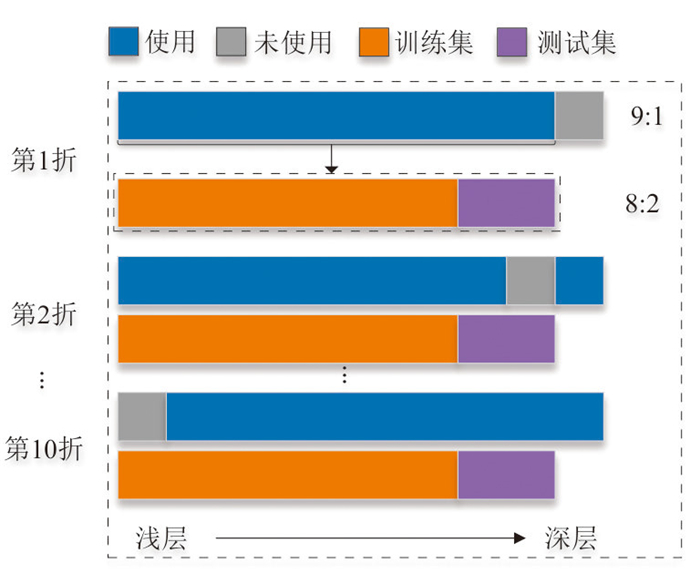
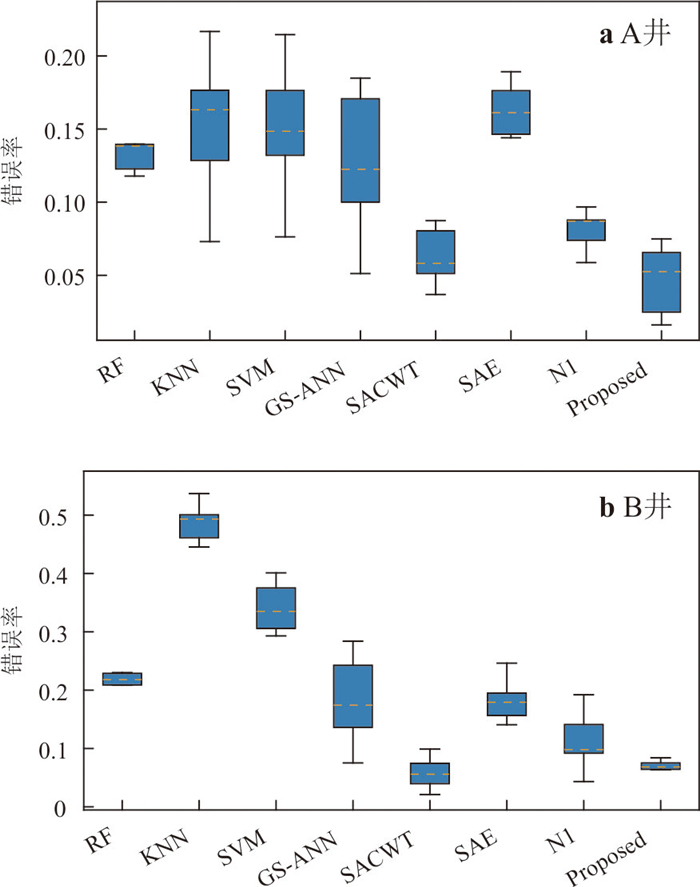
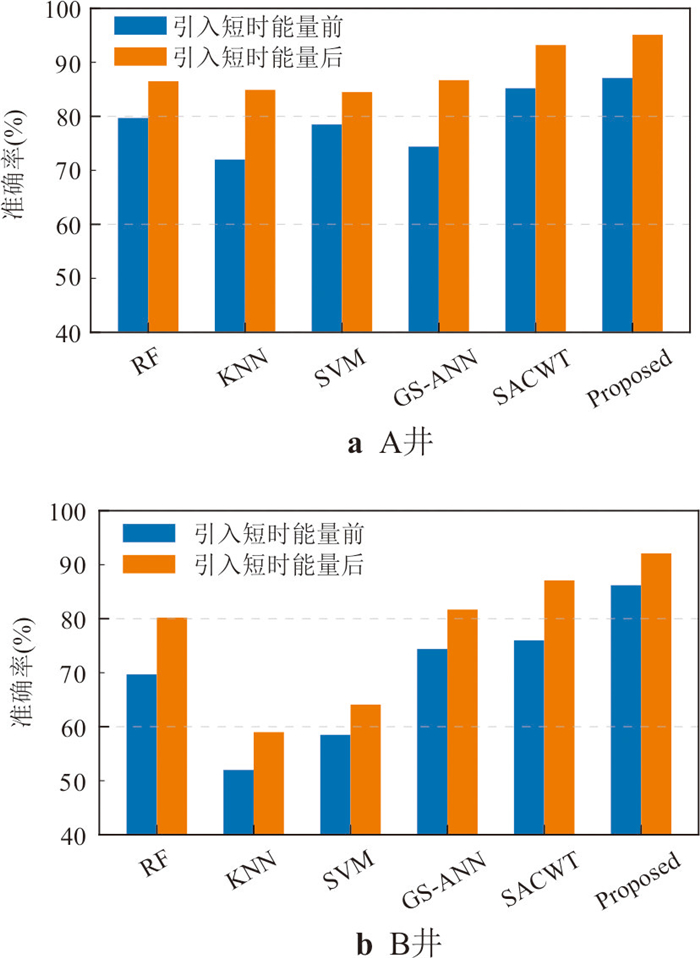
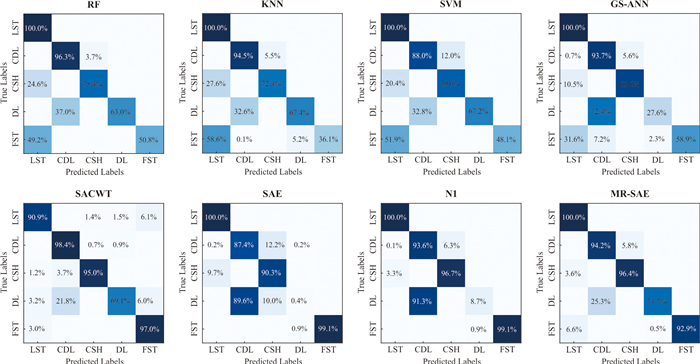
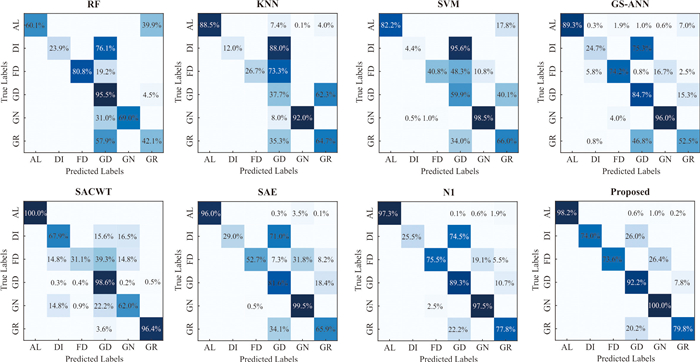
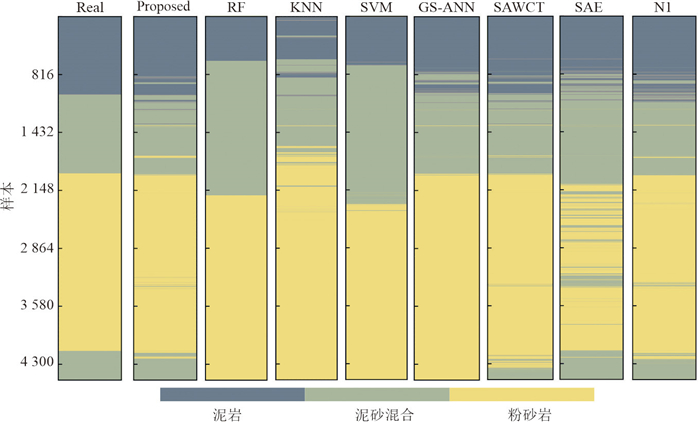
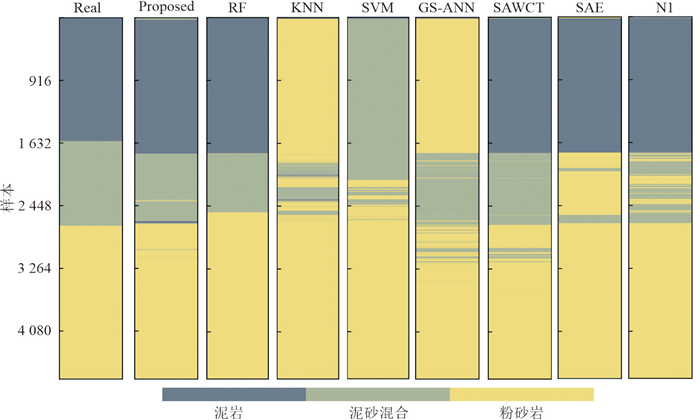
Lithology identification plays a crucial role in oil and gas exploration. Although drilling data can provides costeffective and realtime lithology characterization, its effectiveness is often constrained by weak lithological signals, strong feature coupling, and complex nonlinear relationships. To overcome these limitations, this study presents a hierarchical stacked autoencoderbased method for real-time lithology identification while drilling. The proposed method constructs a hierarchical feature learning framework composed of raw drilling parameters, shorttime energy intermediate features, and a maximal information coefficientdriven regularization mechanism. This framework enhances the representation of weak lithological information in drilling data and guides the model to preferentially learn features with stronger correlations to lithology. Experimental validation on four drilling datasets demonstrates that the proposed method outperforms seven benchmark methods overall. The proposed model achieved 95.1% accuracy with an F1 score of 93.6% on Well A and 92.1% accuracy with an F1 score of 86.0% on Well B. Moreover, the model exhibited good generalization capability in crosswell prediction, yielding accuracies of 94.2% for Well C and 95.4% for Well D, offering a robust solution for realtime lithology identification.
Lithology identification plays a crucial role in oil and gas exploration. Although drilling data can provides costeffective and realtime lithology characterization, its effectiveness is often constrained by weak lithological signals, strong feature coupling, and complex nonlinear relationships. To overcome these limitations, this study presents a hierarchical stacked autoencoderbased method for real-time lithology identification while drilling. The proposed method constructs a hierarchical feature learning framework composed of raw drilling parameters, shorttime energy intermediate features, and a maximal information coefficientdriven regularization mechanism. This framework enhances the representation of weak lithological information in drilling data and guides the model to preferentially learn features with stronger correlations to lithology. Experimental validation on four drilling datasets demonstrates that the proposed method outperforms seven benchmark methods overall. The proposed model achieved 95.1% accuracy with an F1 score of 93.6% on Well A and 92.1% accuracy with an F1 score of 86.0% on Well B. Moreover, the model exhibited good generalization capability in crosswell prediction, yielding accuracies of 94.2% for Well C and 95.4% for Well D, offering a robust solution for realtime lithology identification.
2026, 51(8): 3004-3016.
doi: 10.3799/dqkx.2026.172
Abstract:
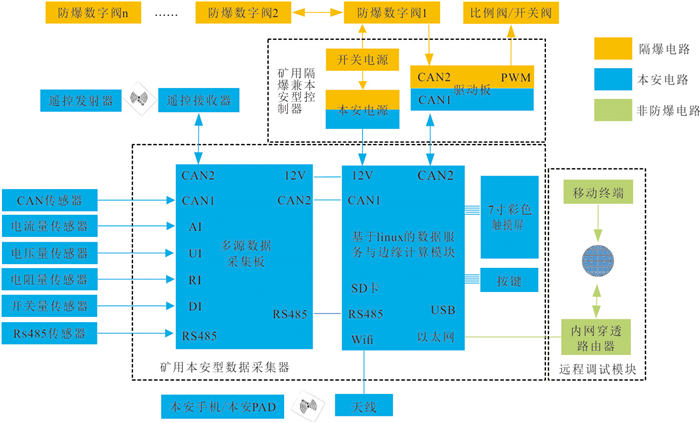
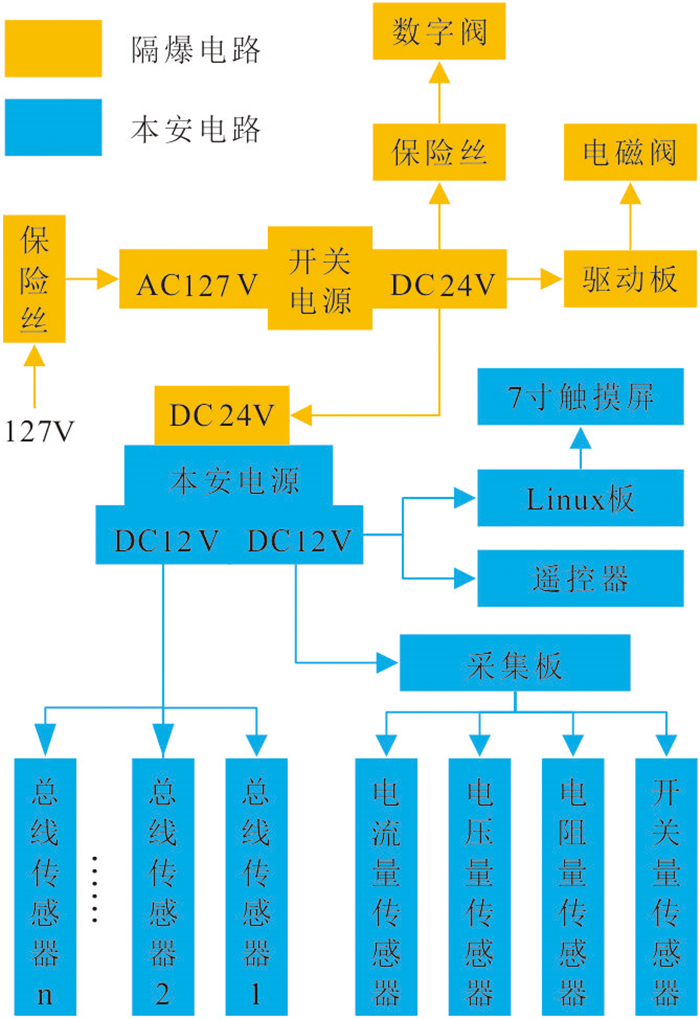
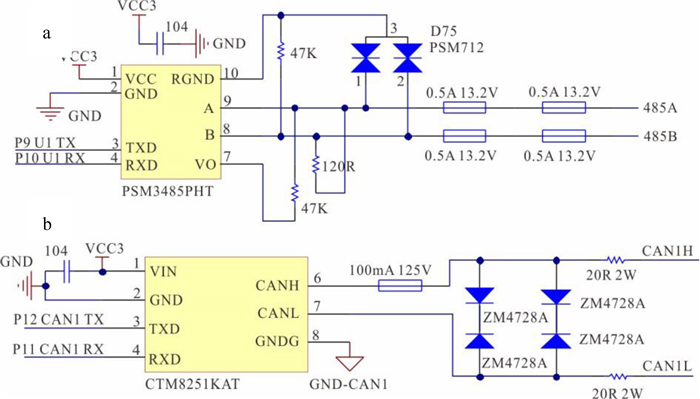
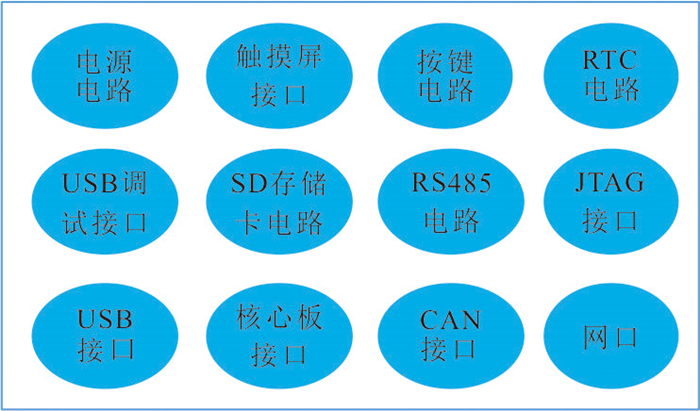
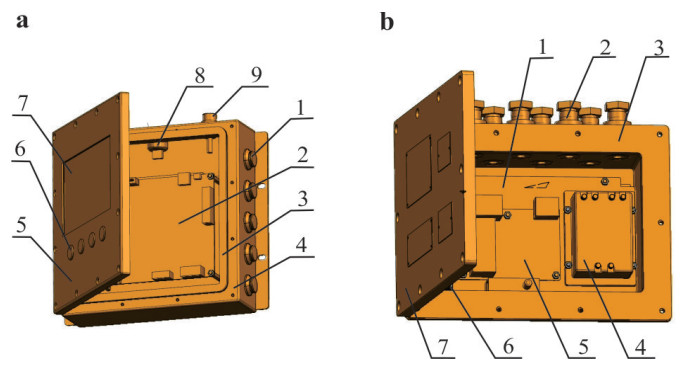
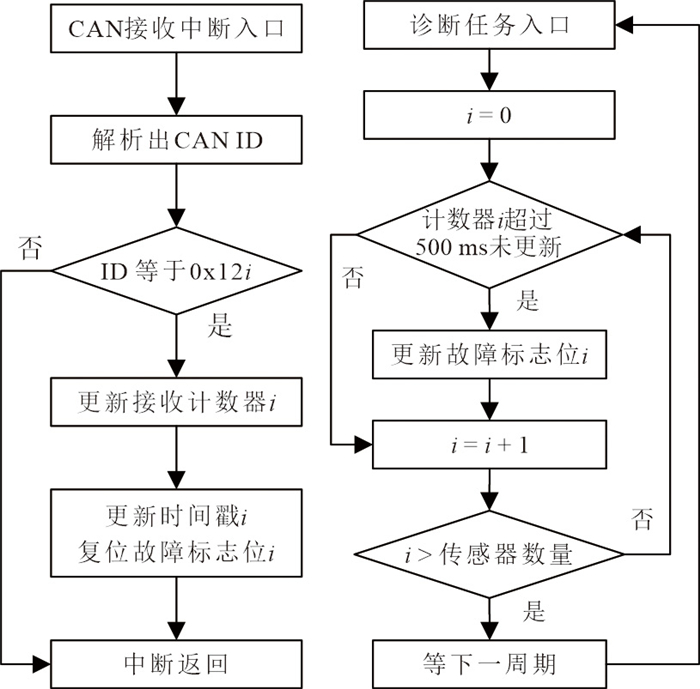
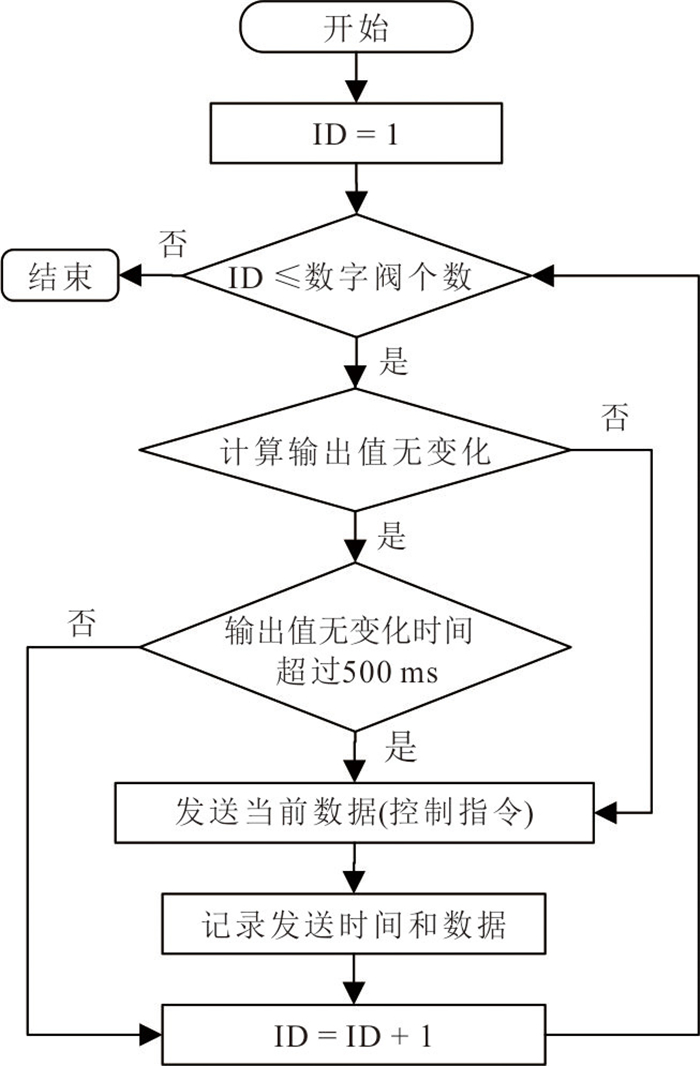
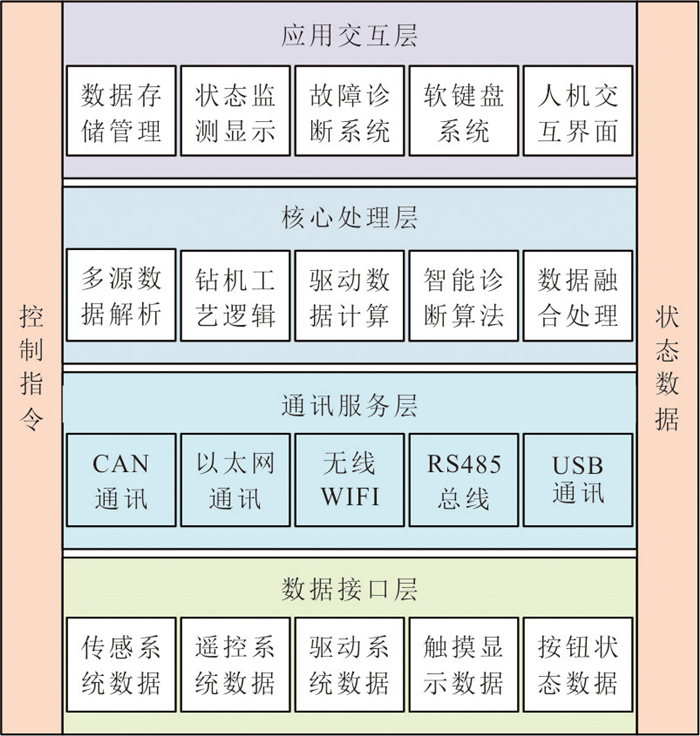
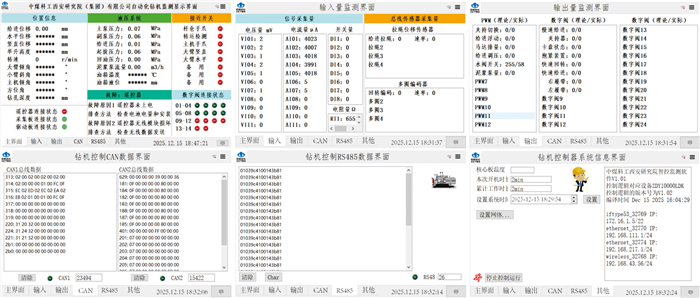
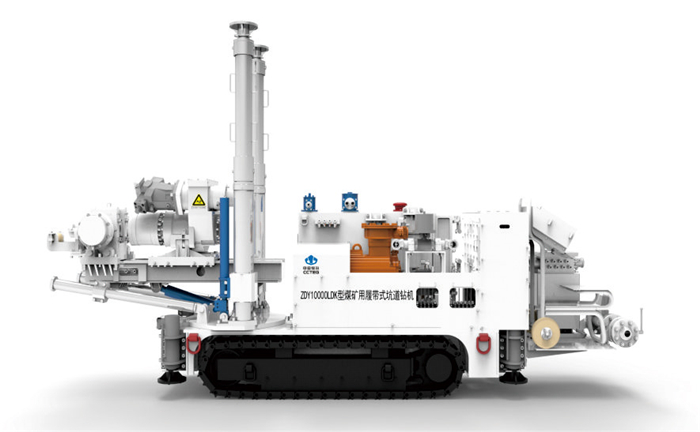
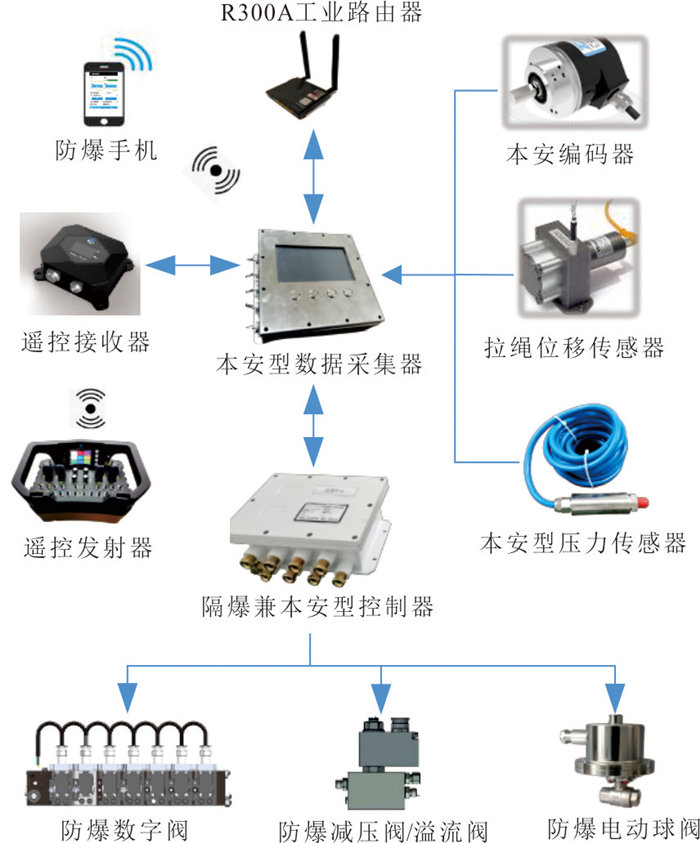
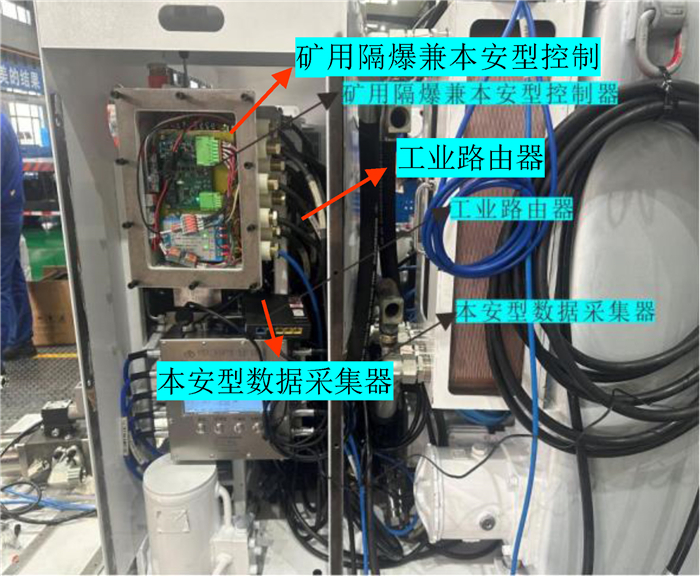
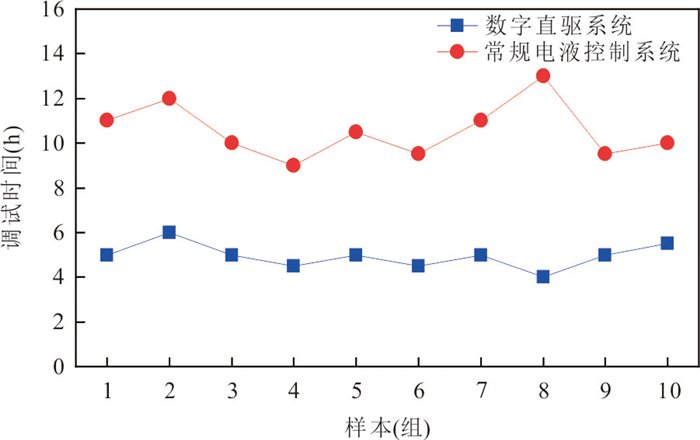
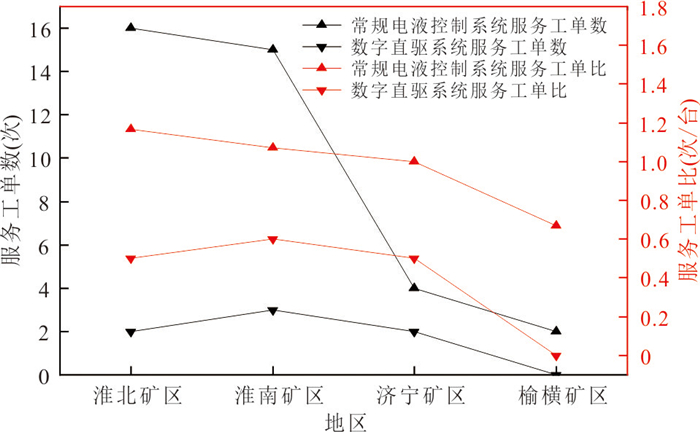
To address the issues of low integration, lengthy on-site commissioning cycles, and inefficient fault localization in conventional electric control systems for coal mine drilling rigs, a digital direct-drive electro-hydraulic control system for coal mine drilling rigs is designed. A distributed architecture is adopted, and a dual-channel isolated CAN bus communication network is constructed. Data service and edge computing modules, multi-source heterogeneous data acquisition boards, and digital valve-based drive circuits are developed. A dedicated communication protocol is established, along with algorithms for bus online monitoring, sensor fault diagnosis, and variable-triggered control command transmission. Remote networking and IAP remote upgrade technologies are integrated to enable remote system commissioning and maintenance. The system is applied to various types of mine drilling rigs. Compared with traditional electro-hydraulic control systems, the average commissioning cycle is shortened by approximately 50%, the fault identification rate for conventional electric control systems under non-power-short-circuit conditions reaches 100%, and after-sales service frequency is reduced by about 50%. This study effectively enhances the digitalization level and system maintainability of electrically controlled drilling rigs, offering a feasible solution for the digital upgrade of mining drilling rigs.
To address the issues of low integration, lengthy on-site commissioning cycles, and inefficient fault localization in conventional electric control systems for coal mine drilling rigs, a digital direct-drive electro-hydraulic control system for coal mine drilling rigs is designed. A distributed architecture is adopted, and a dual-channel isolated CAN bus communication network is constructed. Data service and edge computing modules, multi-source heterogeneous data acquisition boards, and digital valve-based drive circuits are developed. A dedicated communication protocol is established, along with algorithms for bus online monitoring, sensor fault diagnosis, and variable-triggered control command transmission. Remote networking and IAP remote upgrade technologies are integrated to enable remote system commissioning and maintenance. The system is applied to various types of mine drilling rigs. Compared with traditional electro-hydraulic control systems, the average commissioning cycle is shortened by approximately 50%, the fault identification rate for conventional electric control systems under non-power-short-circuit conditions reaches 100%, and after-sales service frequency is reduced by about 50%. This study effectively enhances the digitalization level and system maintainability of electrically controlled drilling rigs, offering a feasible solution for the digital upgrade of mining drilling rigs.
2026, 51(8): 3017-3026.
doi: 10.3799/dqkx.2026.117
Abstract:
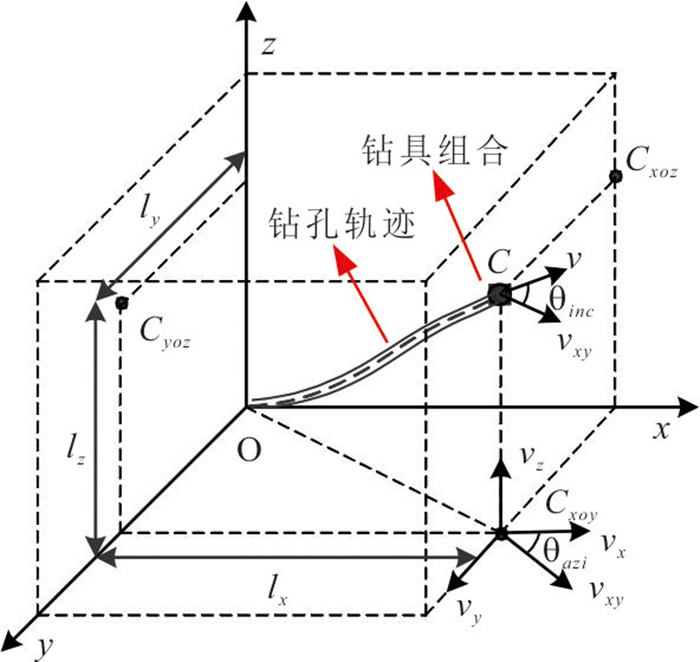
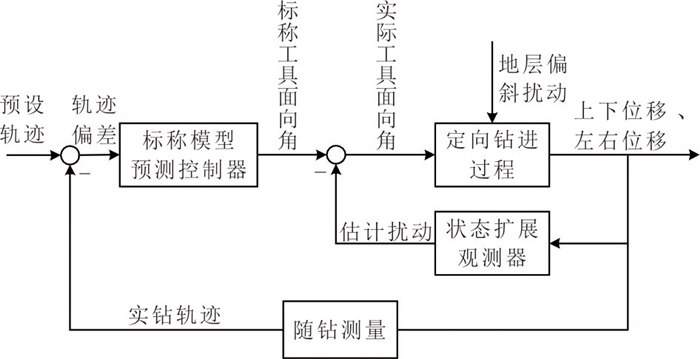
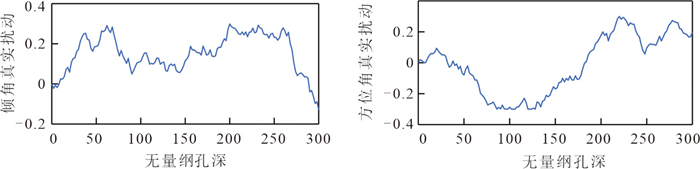
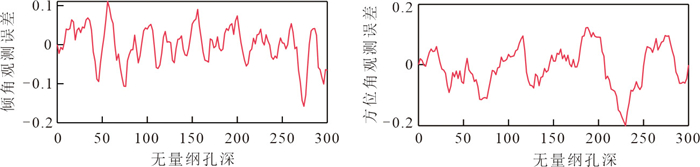
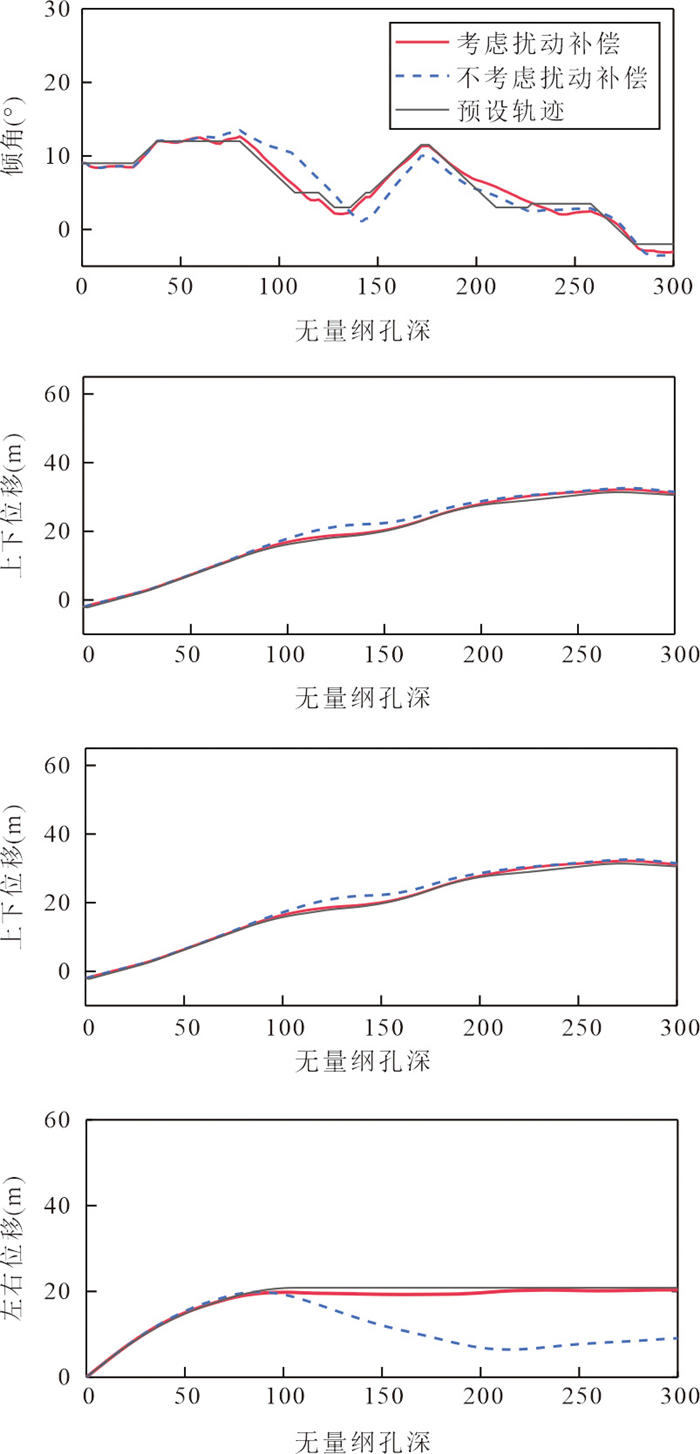
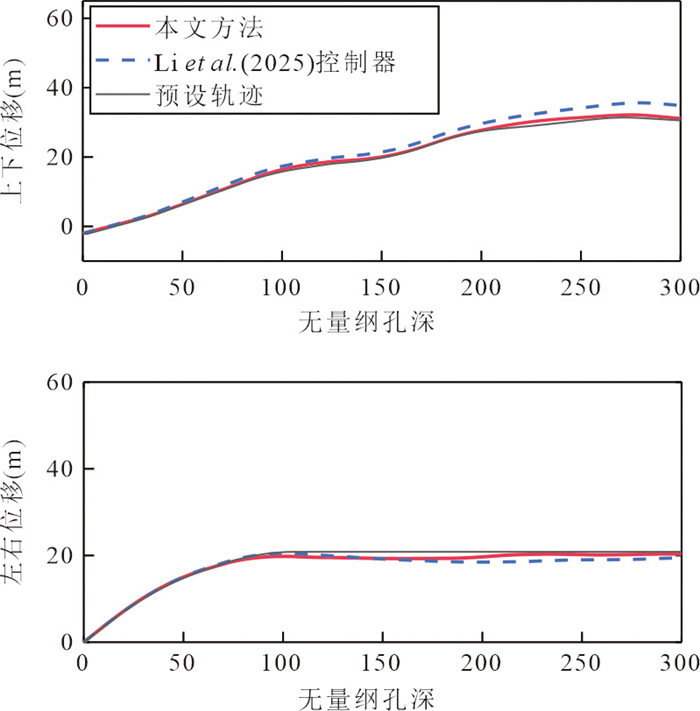
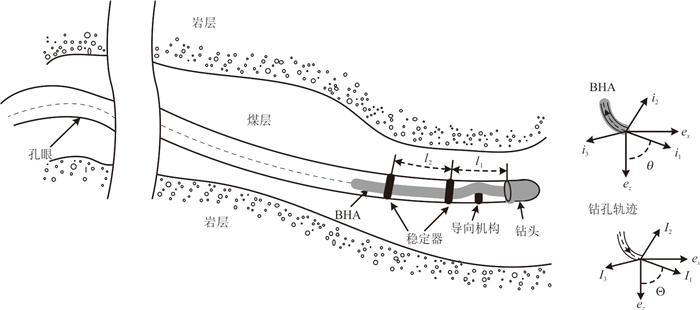
Sliding directional drilling is widely used in directional boreholes for tasks such as advance probing, detection of abnormal bodies related to geological hazards, and gas drainage, helping improve geological interpretation and drilling efficiency. This paper addresses the problem of reduced trajectory tracking accuracy caused by complex formation disturbances during sliding directional drilling, and proposes an extended-state-observer-based model predictive control method for trajectory tracking. First, the kinematic behavior of the drilling tool is analyzed and a trajectory extension model for sliding drilling is built. Based on this model, a trajectory prediction model is constructed, and an objective function that minimizes trajectory error is designed to develop the MPC controller. Then, to reduce steady tracking errors caused by formation disturbances, an extended state observer with disturbance estimation is designed to compensate the control input. Simulation results show that the proposed provides disturbance compensation, high tracking accuracy, and strong robustness, with practical value for improving exploration efficiency and reducing designed to operational risk.
Sliding directional drilling is widely used in directional boreholes for tasks such as advance probing, detection of abnormal bodies related to geological hazards, and gas drainage, helping improve geological interpretation and drilling efficiency. This paper addresses the problem of reduced trajectory tracking accuracy caused by complex formation disturbances during sliding directional drilling, and proposes an extended-state-observer-based model predictive control method for trajectory tracking. First, the kinematic behavior of the drilling tool is analyzed and a trajectory extension model for sliding drilling is built. Based on this model, a trajectory prediction model is constructed, and an objective function that minimizes trajectory error is designed to develop the MPC controller. Then, to reduce steady tracking errors caused by formation disturbances, an extended state observer with disturbance estimation is designed to compensate the control input. Simulation results show that the proposed provides disturbance compensation, high tracking accuracy, and strong robustness, with practical value for improving exploration efficiency and reducing designed to operational risk.
2026, 51(8): 3027-3036.
doi: 10.3799/dqkx.2026.064
Abstract:
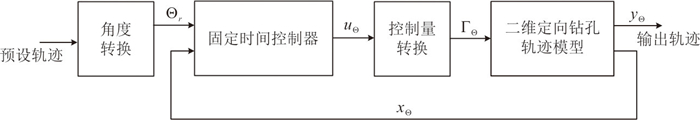
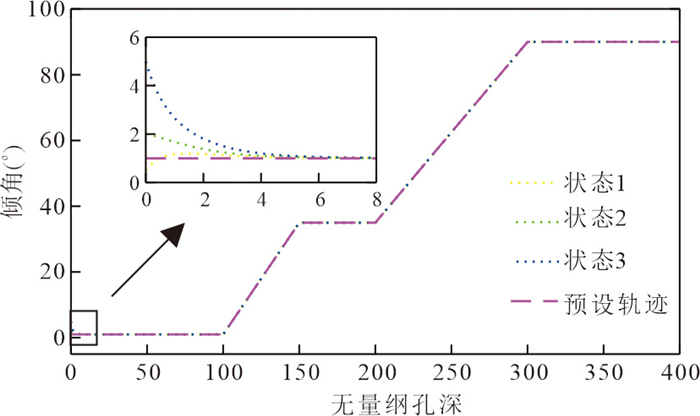
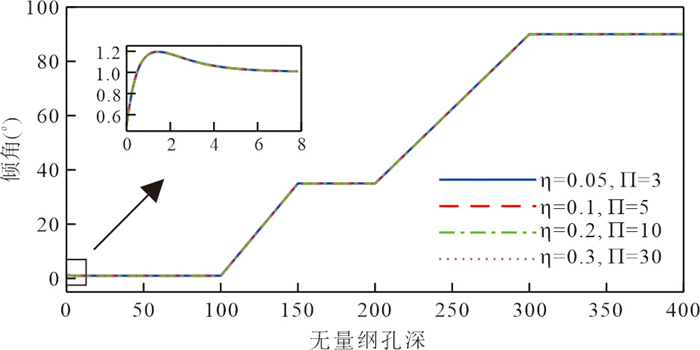
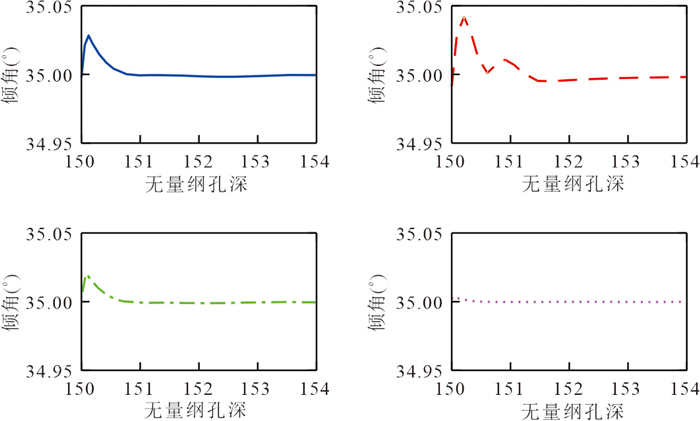
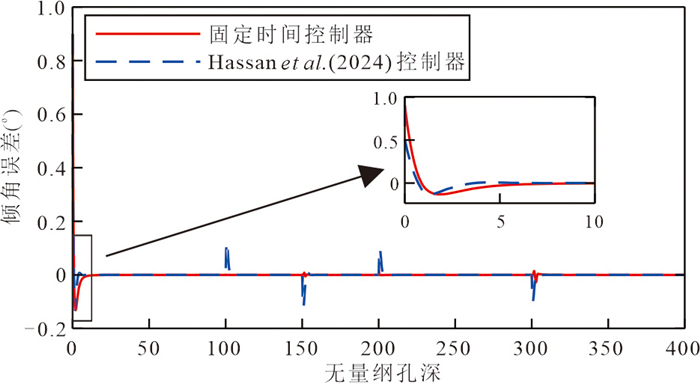
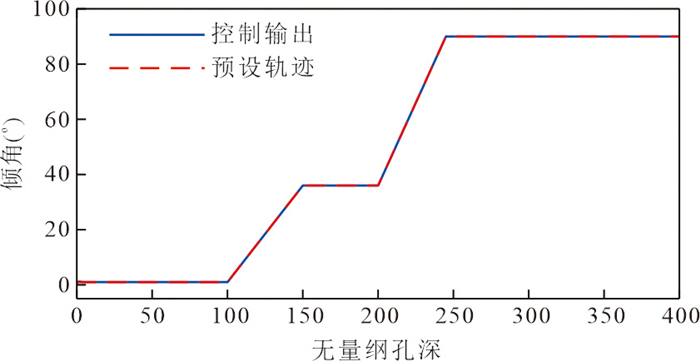
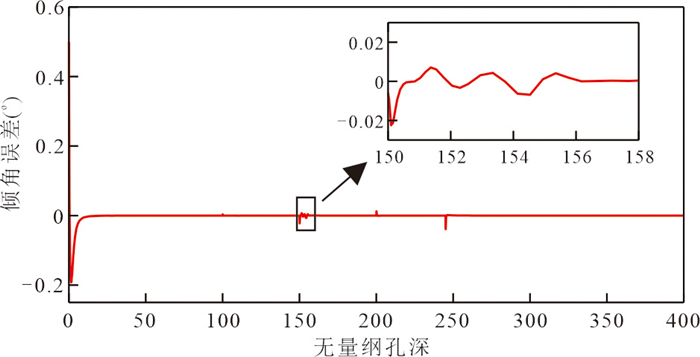
Rotary steering technology, with the advantages of controllable inclination building, high borehole quality, and strong adaptability to complex formations, has been applied in complex environments such as coal mines, engineering geology, and oil-gas exploration. This paper focuses on tasks like advanced working face exploration and geological anomaly identification in the aforementioned fields. To address the issues of target point deviation and trajectory deviation accumulation caused by the lag in inclination adjustment response, a fixed-time tracking control method for the two-dimensional trajectory of directional drilling holes oriented to rotary steering systems is proposed. Firstly, based on the time-delay differential equation describing borehole extension, a state-space representation of the directional drilling trajectory model is established. Then, a nonlinear controller with a power feedback term is designed to achieve rapid convergence of trajectory errors. Furthermore, a Lyapunov function is constructed to derive the upper bound of the convergence time, proving that the closed-loop system has fixed-time convergence characteristics. Finally, simulation experiments demonstrate that the proposed method features fast convergence speed, high trajectory control accuracy, and strong robustness, and has good application value in enhancing exploration efficiency and reducing operational risks.
Rotary steering technology, with the advantages of controllable inclination building, high borehole quality, and strong adaptability to complex formations, has been applied in complex environments such as coal mines, engineering geology, and oil-gas exploration. This paper focuses on tasks like advanced working face exploration and geological anomaly identification in the aforementioned fields. To address the issues of target point deviation and trajectory deviation accumulation caused by the lag in inclination adjustment response, a fixed-time tracking control method for the two-dimensional trajectory of directional drilling holes oriented to rotary steering systems is proposed. Firstly, based on the time-delay differential equation describing borehole extension, a state-space representation of the directional drilling trajectory model is established. Then, a nonlinear controller with a power feedback term is designed to achieve rapid convergence of trajectory errors. Furthermore, a Lyapunov function is constructed to derive the upper bound of the convergence time, proving that the closed-loop system has fixed-time convergence characteristics. Finally, simulation experiments demonstrate that the proposed method features fast convergence speed, high trajectory control accuracy, and strong robustness, and has good application value in enhancing exploration efficiency and reducing operational risks.
2026, 51(8): 3037-3047.
doi: 10.3799/dqkx.2026.002
Abstract:
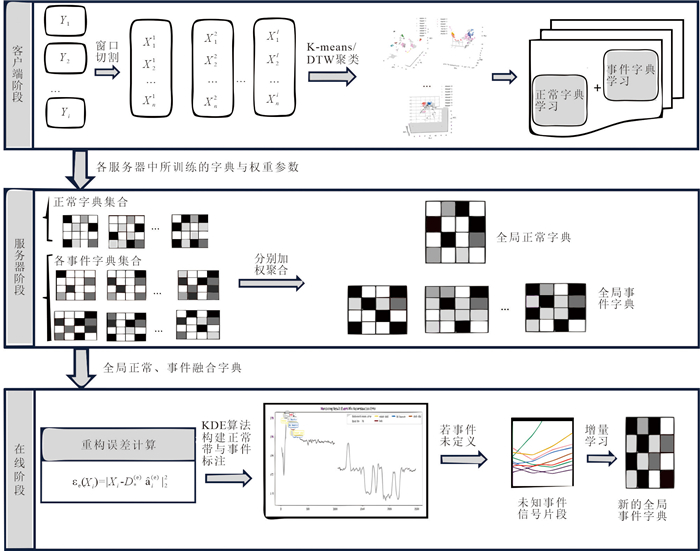
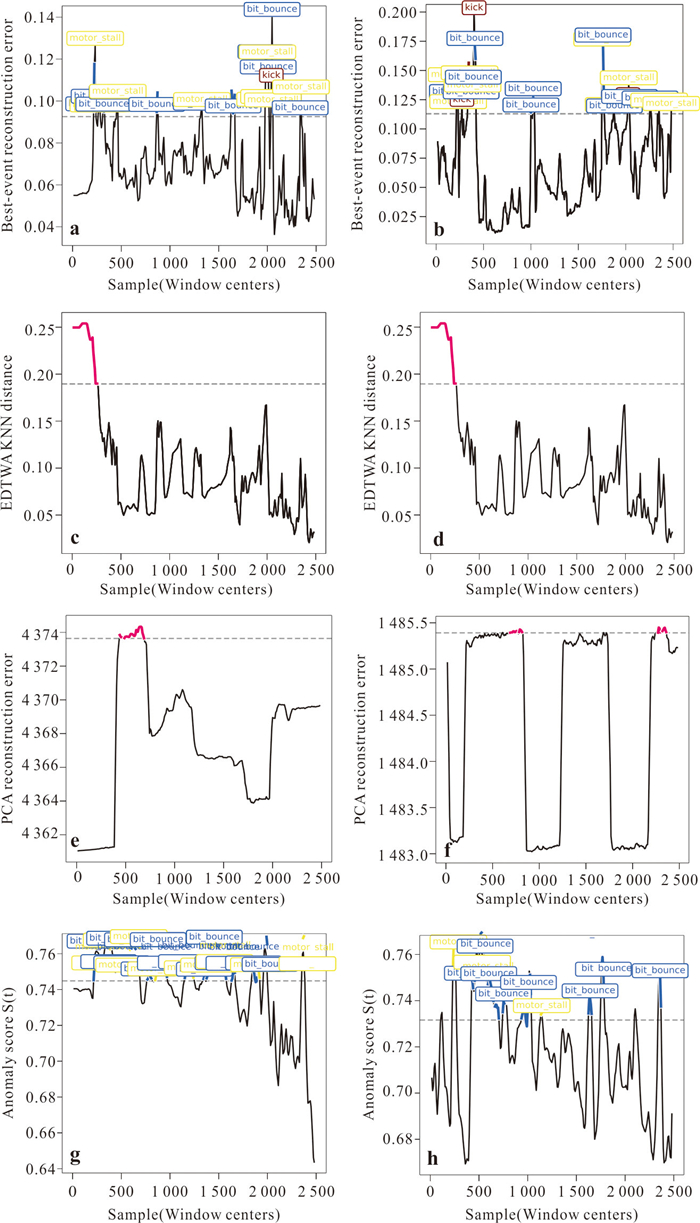
To address practical challenges in geological drilling, including pronounced inter-well distribution shifts, stringent privacy constraints, and the lack of manual annotations, this paper proposes an intelligent monitoring method based on federated dictionary learning. Centered on sparse dictionary representations, the proposed approach integrates an event-driven heuristic scoring and alignment mechanism to enable interpretable discrimination and abnormal pattern recognition without requiring human-labeled data. Meanwhile, under a data-locality constraint where raw data never leave local sites, the method incorporates collaborative multi-well dictionary training and a sample-size-weighted server-side aggregation scheme to enhance robustness and cross-well generalization across heterogeneous drilling environments. Experiments are conducted on field logging data collected from multiple real-world drilling projects, where a multi-well federated dataset is constructed for evaluation. The results demonstrate that the proposed method achieves superior monitoring performance under multi-well settings, with an average separability score of 4.018 and an average weakly supervised precision of 0.804, indicating stable identification of typical abnormal events in the absence of annotations. These findings substantiate the effectiveness of the event labeling mechanism in improving model interpretability and cross-well generalization, and provide a feasible and effective technical pathway for distributed intelligent monitoring in complex geological environments.
To address practical challenges in geological drilling, including pronounced inter-well distribution shifts, stringent privacy constraints, and the lack of manual annotations, this paper proposes an intelligent monitoring method based on federated dictionary learning. Centered on sparse dictionary representations, the proposed approach integrates an event-driven heuristic scoring and alignment mechanism to enable interpretable discrimination and abnormal pattern recognition without requiring human-labeled data. Meanwhile, under a data-locality constraint where raw data never leave local sites, the method incorporates collaborative multi-well dictionary training and a sample-size-weighted server-side aggregation scheme to enhance robustness and cross-well generalization across heterogeneous drilling environments. Experiments are conducted on field logging data collected from multiple real-world drilling projects, where a multi-well federated dataset is constructed for evaluation. The results demonstrate that the proposed method achieves superior monitoring performance under multi-well settings, with an average separability score of 4.018 and an average weakly supervised precision of 0.804, indicating stable identification of typical abnormal events in the absence of annotations. These findings substantiate the effectiveness of the event labeling mechanism in improving model interpretability and cross-well generalization, and provide a feasible and effective technical pathway for distributed intelligent monitoring in complex geological environments.
2026, 51(8): 3048-3064.
doi: 10.3799/dqkx.2026.175
Abstract:
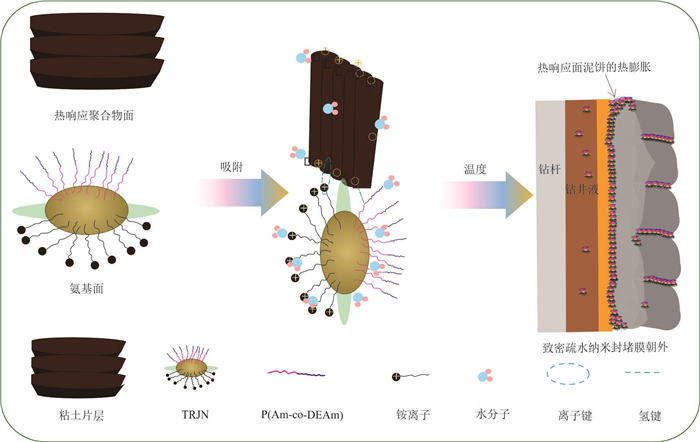
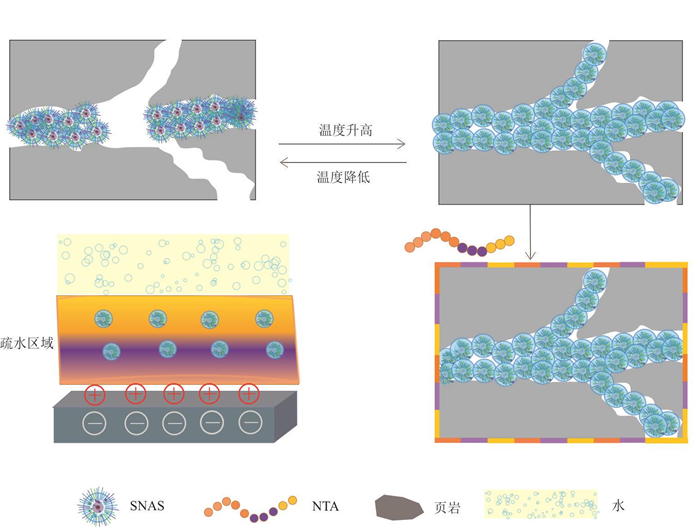
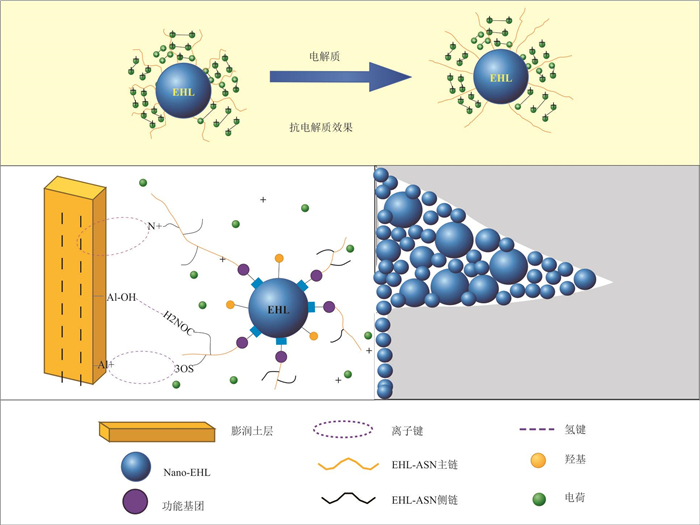
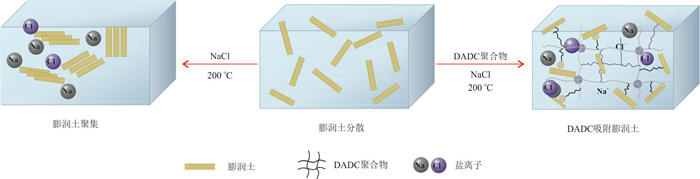
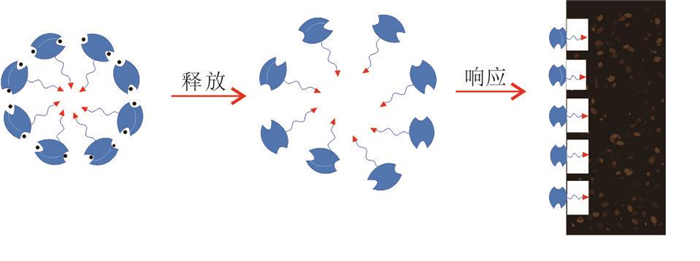
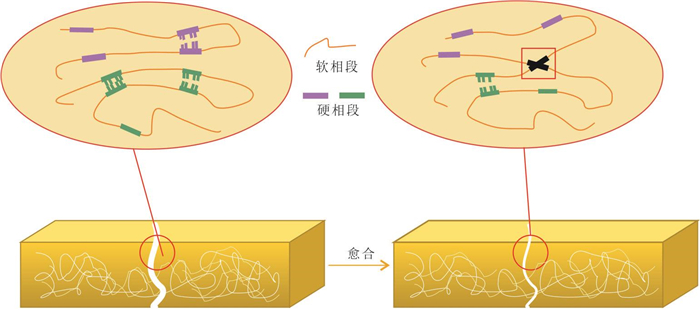
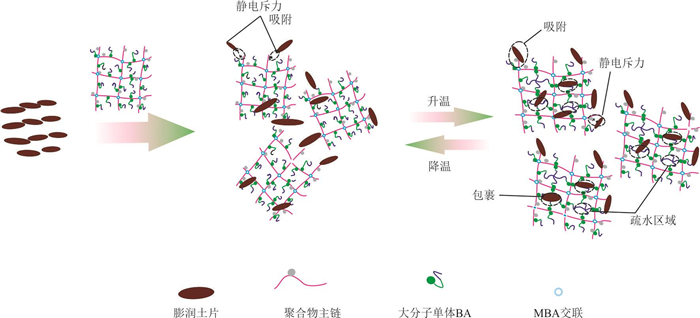
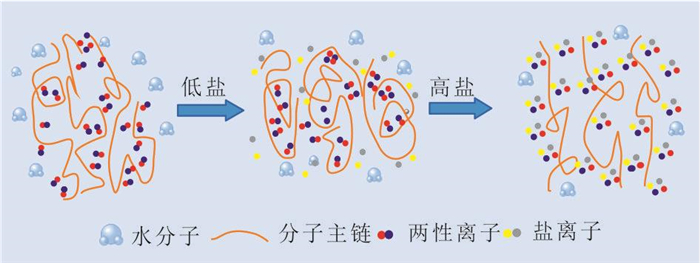
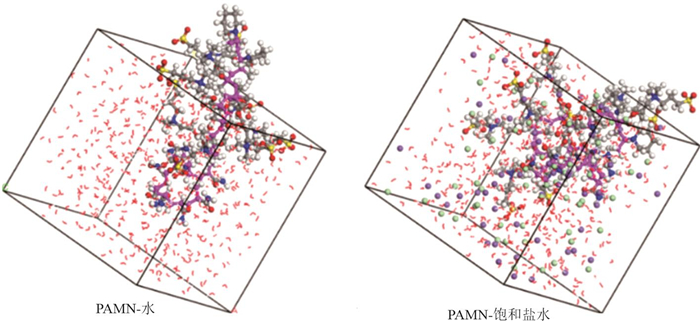
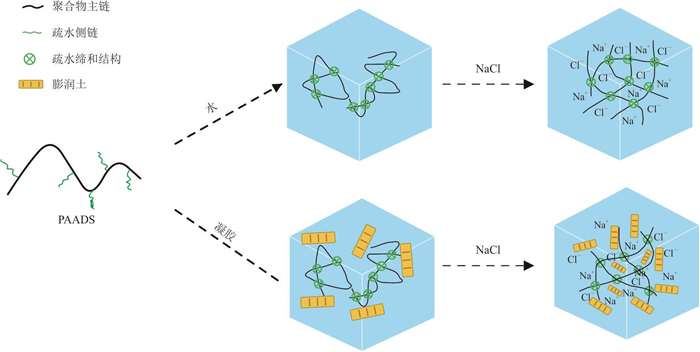
Compared with traditional water-based drilling fluids, intelligent water-based drilling fluids possess intelligent features such as "self-recognition, self-regulation, and self-adaptation", and are expected to fundamentally break through the technical bottlenecks currently faced in the drilling fluid field. They represent a more promising direction for future development. Based on a literature review, this paper systematically summarizes research progress on key additives for intelligent water-based drilling fluids: including flow-type modifiers, loss reducers, shale inhibitors, viscosity enhancers, and leak-sealing materials: across three dimensions: molecular design, response mechanisms, and performance evaluation. Furthermore, addressing critical technical challenges associated with various intelligent additives, it outlines future development directions to provide theoretical guidance for constructing intelligent drilling fluid systems.
Compared with traditional water-based drilling fluids, intelligent water-based drilling fluids possess intelligent features such as "self-recognition, self-regulation, and self-adaptation", and are expected to fundamentally break through the technical bottlenecks currently faced in the drilling fluid field. They represent a more promising direction for future development. Based on a literature review, this paper systematically summarizes research progress on key additives for intelligent water-based drilling fluids: including flow-type modifiers, loss reducers, shale inhibitors, viscosity enhancers, and leak-sealing materials: across three dimensions: molecular design, response mechanisms, and performance evaluation. Furthermore, addressing critical technical challenges associated with various intelligent additives, it outlines future development directions to provide theoretical guidance for constructing intelligent drilling fluid systems.
An Intelligent Inferring Method of Deep Formation Drillability Based on Drillability Knowledge Graph
2026, 51(8): 3065-3075.
doi: 10.3799/dqkx.2026.144
Abstract:
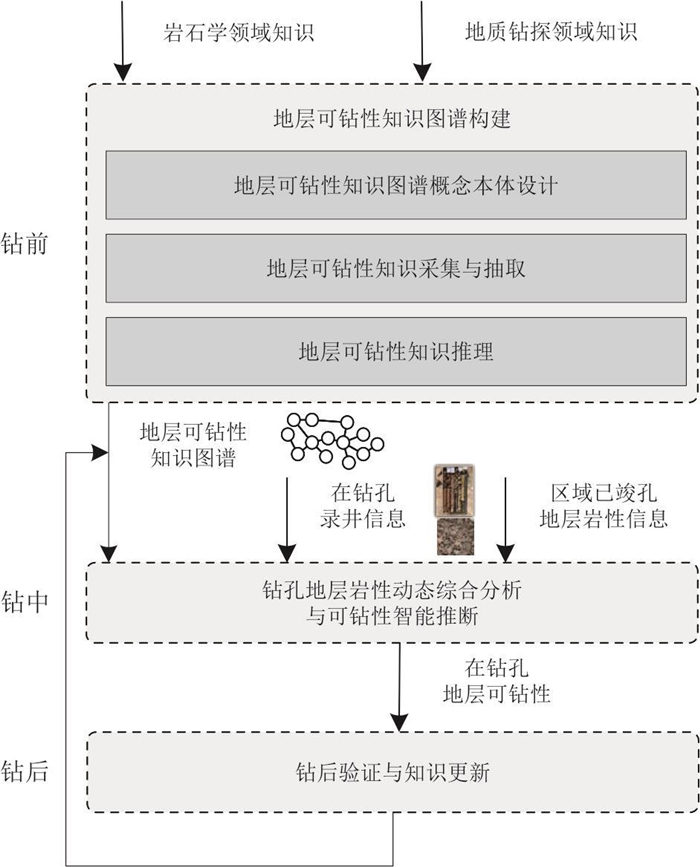
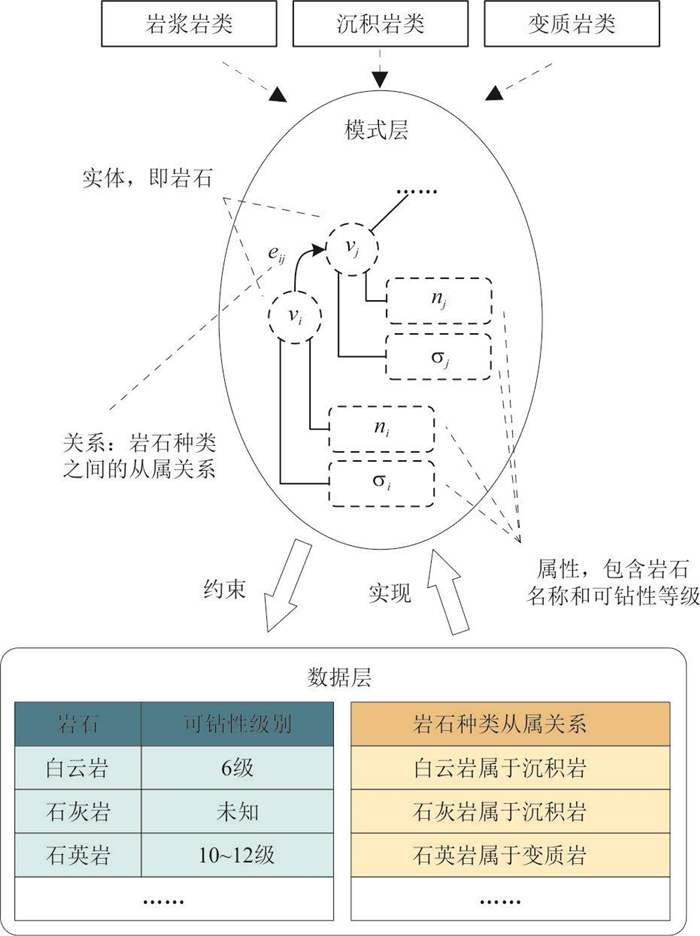
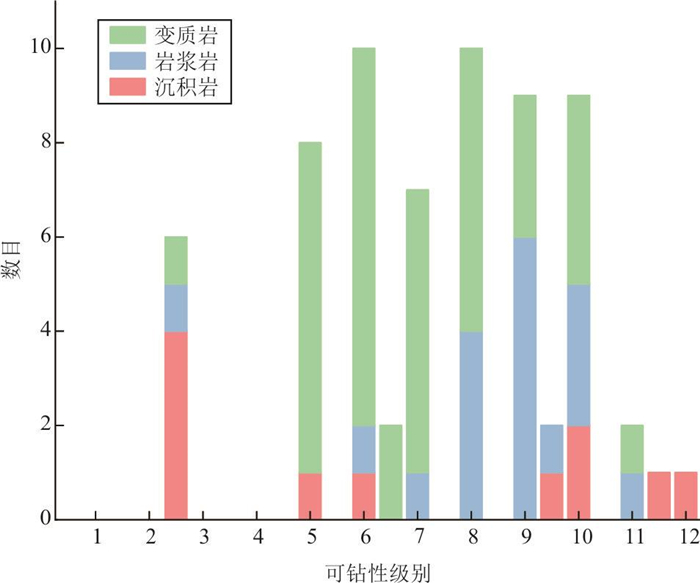
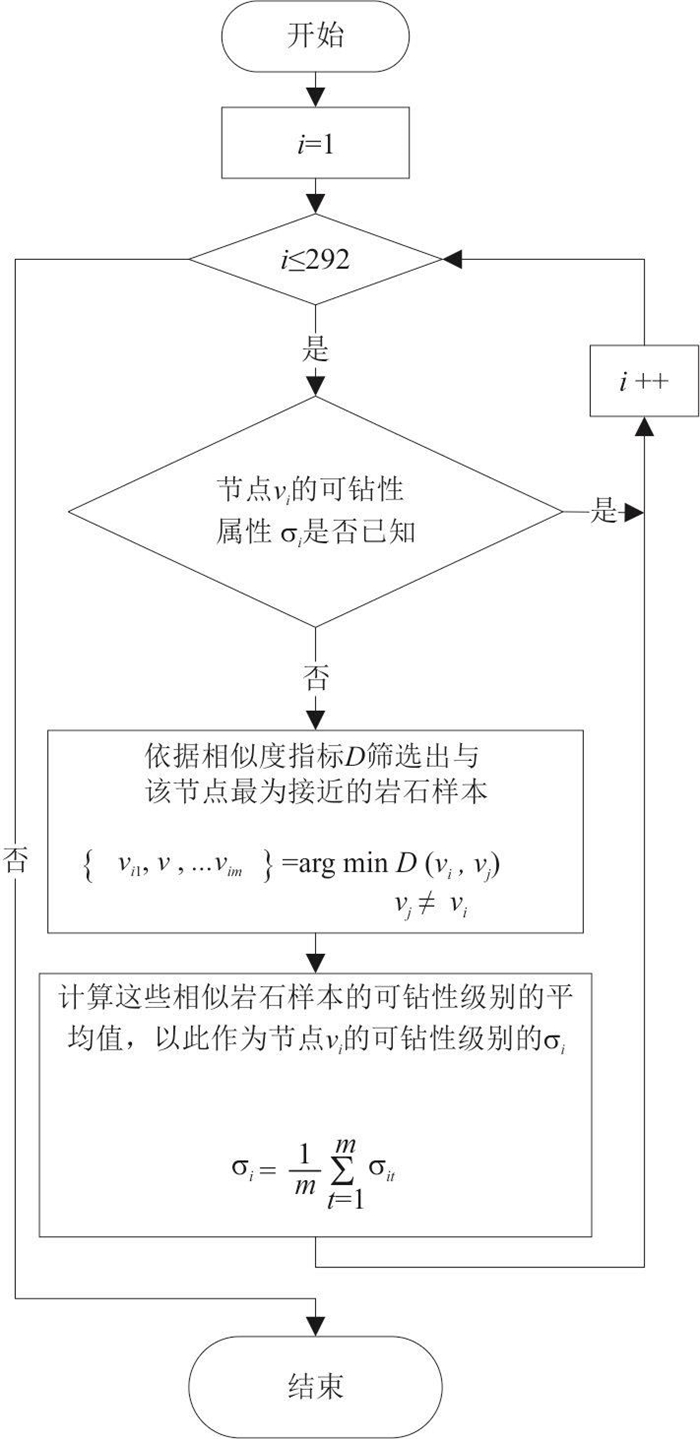
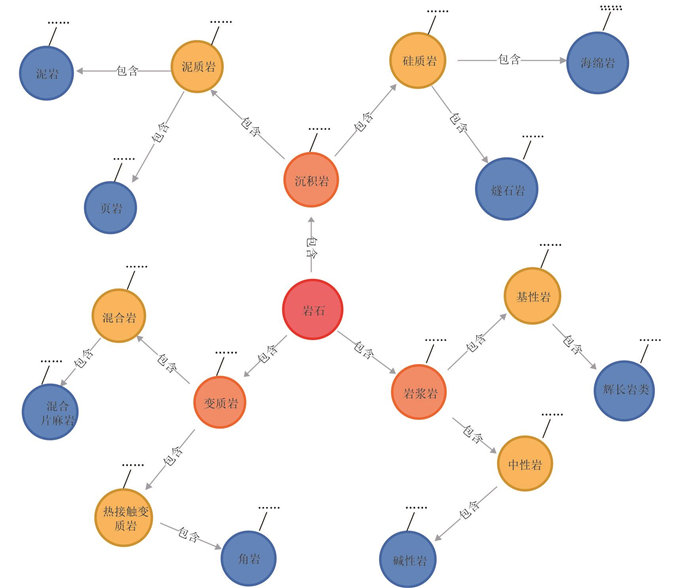
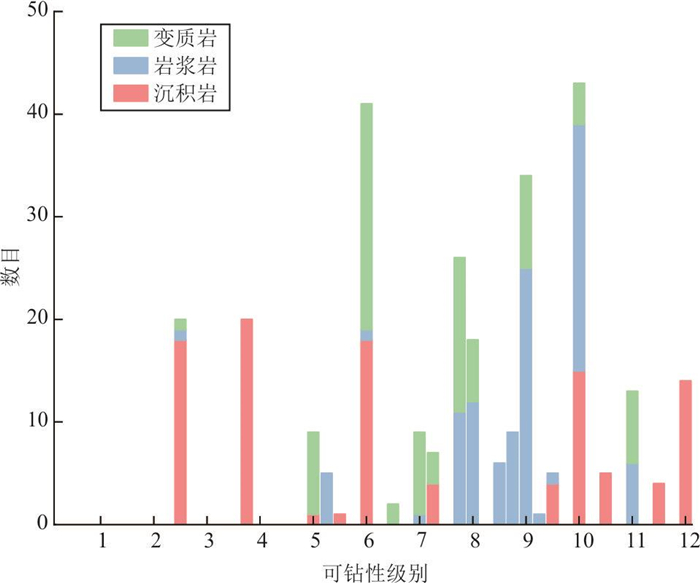
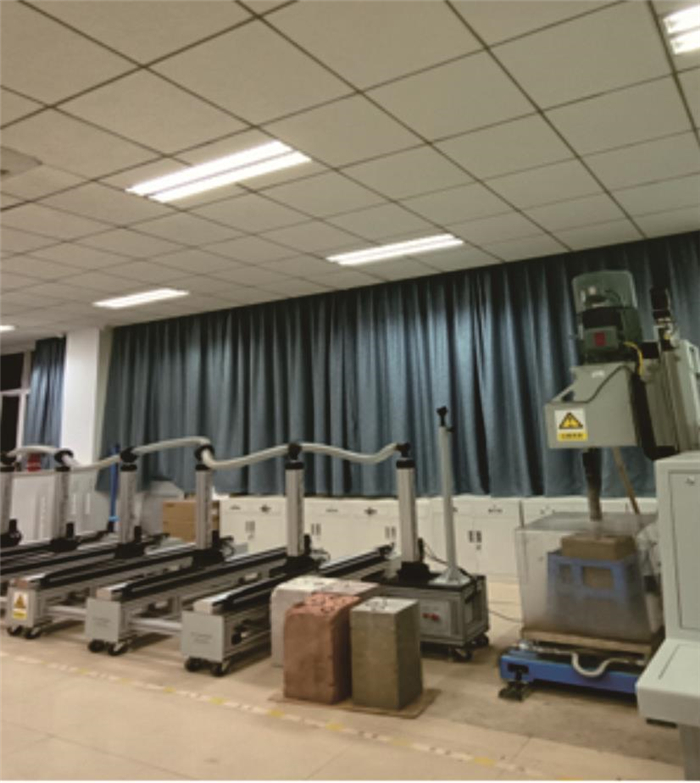
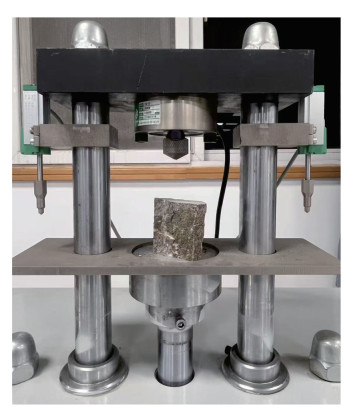
The formation drillability, as a key indicator for measuring the ease or difficulty of drilling the formation during the drilling process, serves as an important basis for rationally selecting drilling methods and optimizing drilling operational parameters. Addressing the issues of high cost in acquiring drillability information during deep geological drilling and the lack of corresponding formation drillability range standards for many rocks, this paper proposes an intelligent inference method for deep drilling formation drillability based on a drillability knowledge graph. Firstly, a drillability knowledge graph incorporating the key characteristics of rocks is constructed, and a drillability reasoning algorithm based on rock similarity measurement is designed. This approach extends the 67 rock drillability levels specified in the geomining industry standards to 292 known types of rocks. Secondly, through dynamic analysis of borehole formation lithology and intelligent inference of drillability, the distribution of formation lithology is analyzed in real-time, and the drillability level of the formation being drilled is inferred. Finally, the effectiveness of the proposed method is verified through micro-drilling experiments and indentation hardness tests. This method lays an important foundation for the intelligent control of the deep geological drilling process.
The formation drillability, as a key indicator for measuring the ease or difficulty of drilling the formation during the drilling process, serves as an important basis for rationally selecting drilling methods and optimizing drilling operational parameters. Addressing the issues of high cost in acquiring drillability information during deep geological drilling and the lack of corresponding formation drillability range standards for many rocks, this paper proposes an intelligent inference method for deep drilling formation drillability based on a drillability knowledge graph. Firstly, a drillability knowledge graph incorporating the key characteristics of rocks is constructed, and a drillability reasoning algorithm based on rock similarity measurement is designed. This approach extends the 67 rock drillability levels specified in the geomining industry standards to 292 known types of rocks. Secondly, through dynamic analysis of borehole formation lithology and intelligent inference of drillability, the distribution of formation lithology is analyzed in real-time, and the drillability level of the formation being drilled is inferred. Finally, the effectiveness of the proposed method is verified through micro-drilling experiments and indentation hardness tests. This method lays an important foundation for the intelligent control of the deep geological drilling process.
2026, 51(8): 3076-3086.
doi: 10.3799/dqkx.2026.112
Abstract:
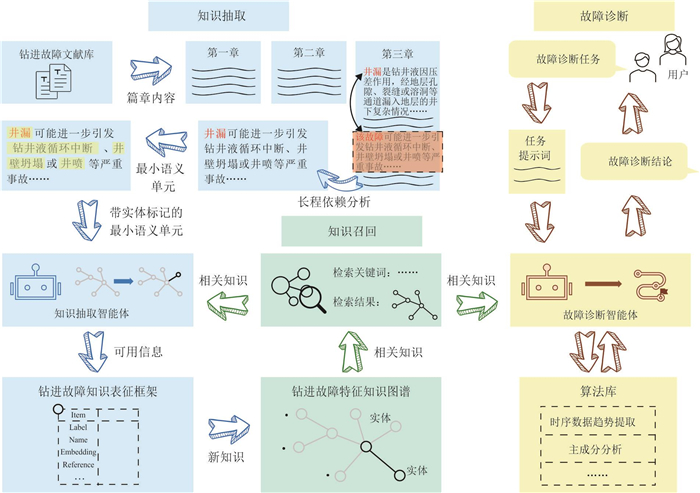
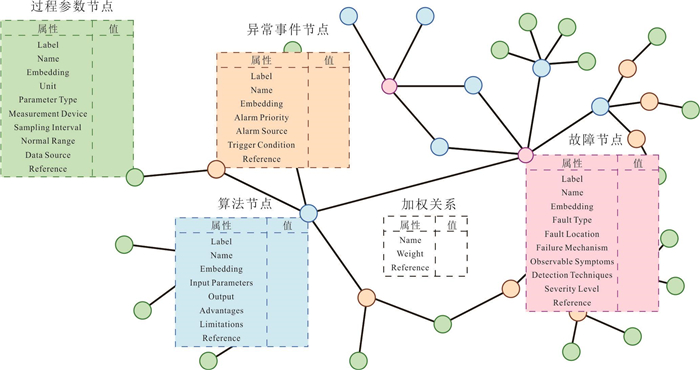
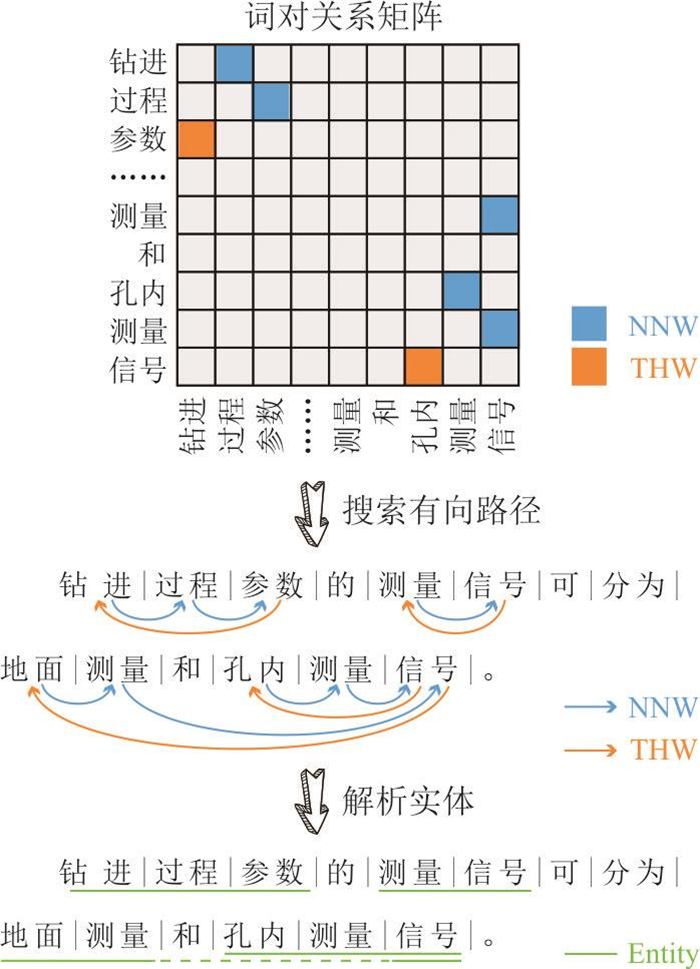
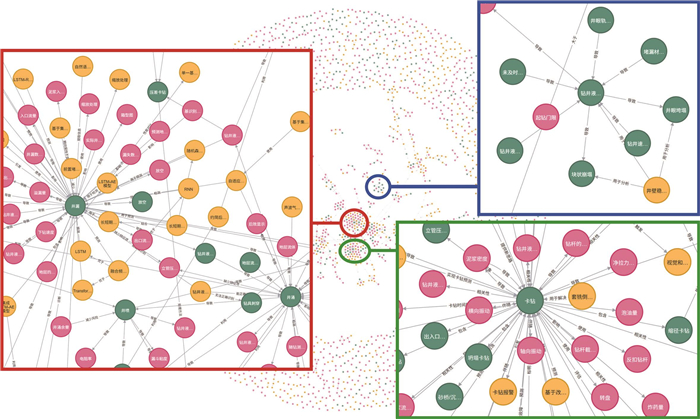
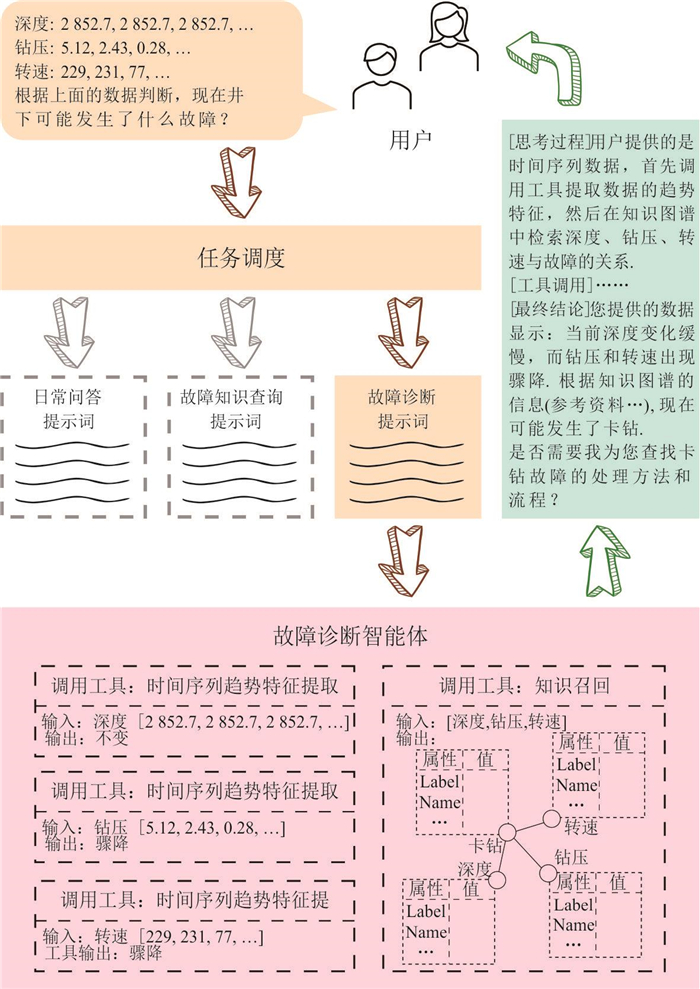
Geological drilling involves high complexity and risk, making interpretable and interactive fault diagnosis systems essential for ensuring operational safety and efficiency. This paper proposes a structured representation framework for the complex knowledge and failure mechanisms of geological drilling to enable structured representation and storage of drilling knowledge. To construct a knowledge graph for the characteristics of geological drilling faults, long-range dependency analysis and composite-structure entity recognition are developed to automatically extract professional knowledge from drilling fault literature. Based on the constructed knowledge graph, a knowledge-driven drilling fault diagnosis system is further developed.Knowledge extraction from 21 publicly available publications results in a fault feature knowledge graph containing 3 121 nodes and 1 301 relations. Experimental results demonstrate that the proposed system achieves performance comparable to ChatGPT-5.2 on five drilling fault knowledge query tasks and outperforms mainstream commercial large language models on two fault diagnosis tasks.
Geological drilling involves high complexity and risk, making interpretable and interactive fault diagnosis systems essential for ensuring operational safety and efficiency. This paper proposes a structured representation framework for the complex knowledge and failure mechanisms of geological drilling to enable structured representation and storage of drilling knowledge. To construct a knowledge graph for the characteristics of geological drilling faults, long-range dependency analysis and composite-structure entity recognition are developed to automatically extract professional knowledge from drilling fault literature. Based on the constructed knowledge graph, a knowledge-driven drilling fault diagnosis system is further developed.Knowledge extraction from 21 publicly available publications results in a fault feature knowledge graph containing 3 121 nodes and 1 301 relations. Experimental results demonstrate that the proposed system achieves performance comparable to ChatGPT-5.2 on five drilling fault knowledge query tasks and outperforms mainstream commercial large language models on two fault diagnosis tasks.
2026, 51(8): 3087-3101.
doi: 10.3799/dqkx.2026.228
Abstract:
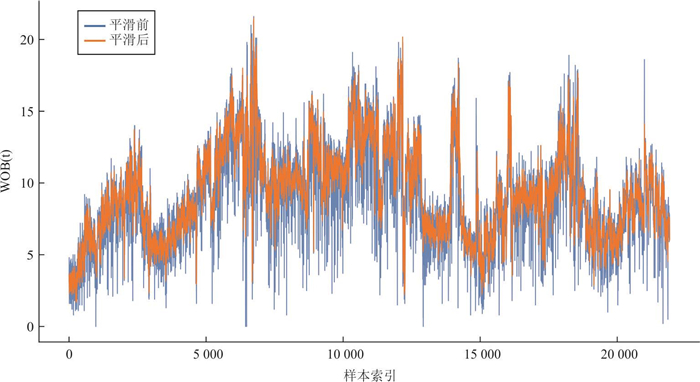
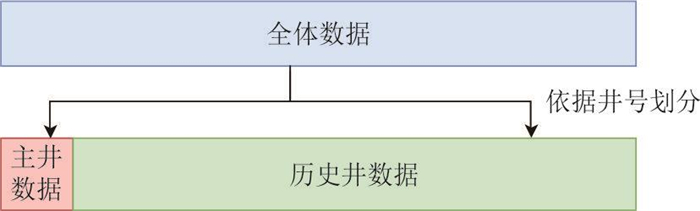
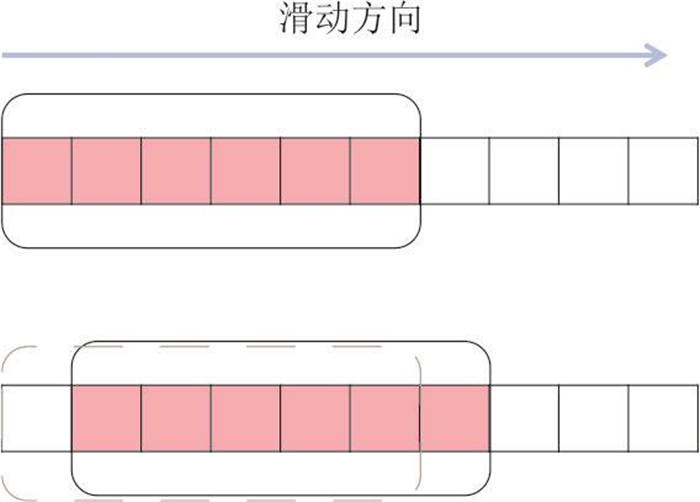
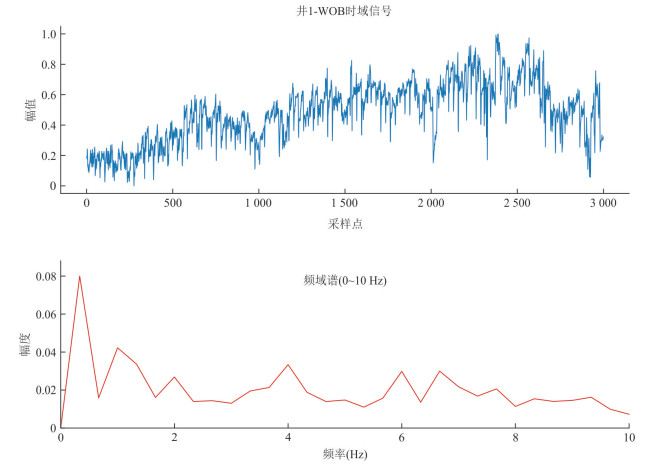
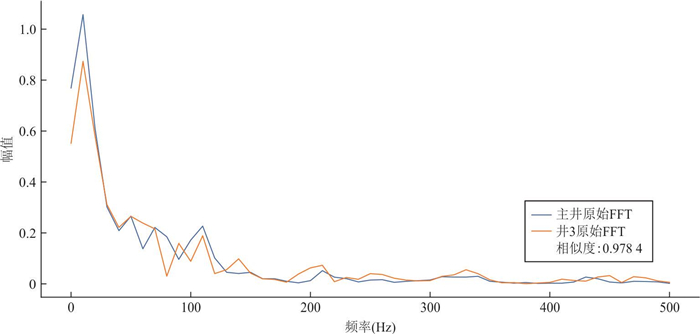
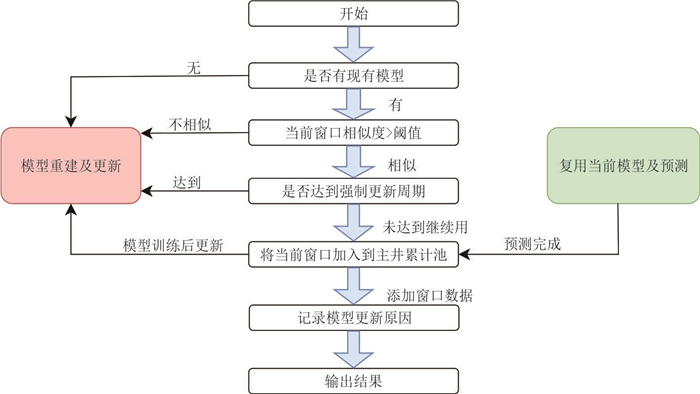
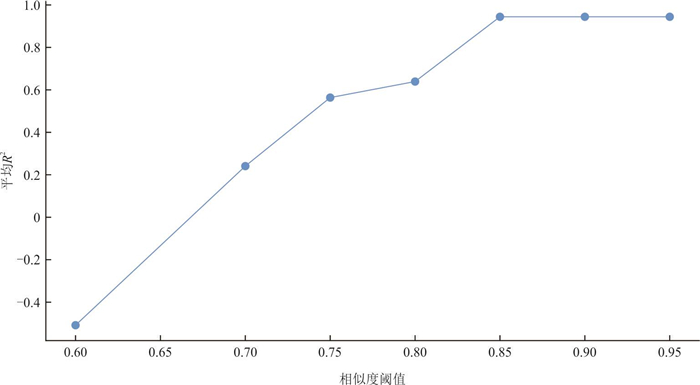
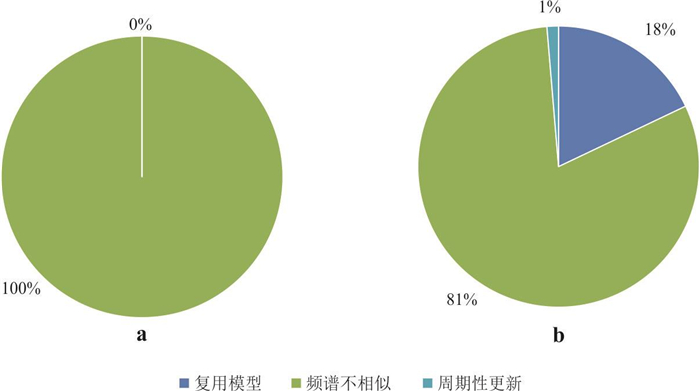
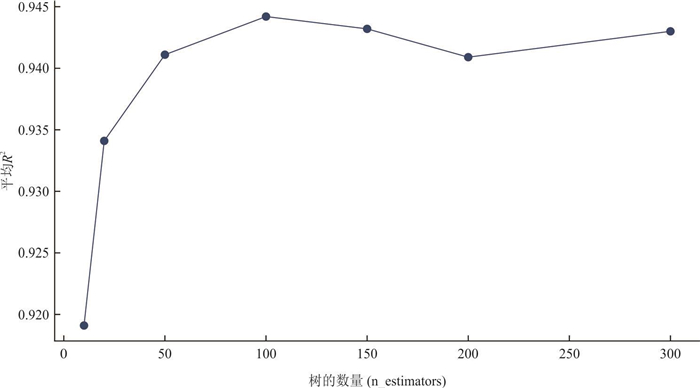
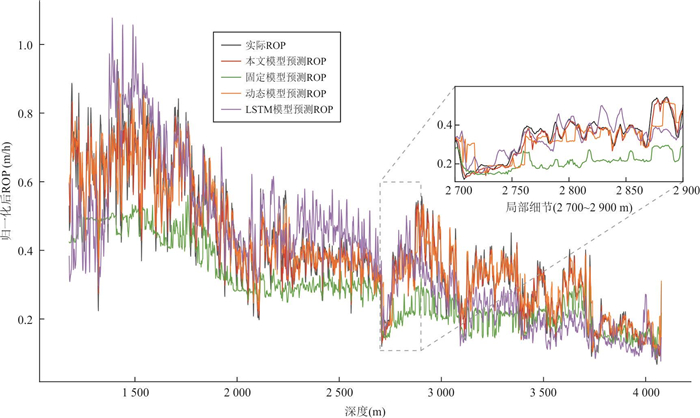
To address the challenges of non-stationary data streams and working condition drift in Rate of Penetration (ROP) prediction for deep complex formations, a dynamic modeling method based on frequency domain perception and adaptive feedback is proposed. The method utilizes sliding windows and Fast Fourier Transform (FFT) to extract frequency domain features from real-time data streams, quantifying the matching degree of working conditions between the main well and neighboring wells via cosine similarity. An innovative dynamic threshold mechanism based on\begin{document}$ {R}^{2} $\end{document} \begin{document}$ {R}^{2} $\end{document}
To address the challenges of non-stationary data streams and working condition drift in Rate of Penetration (ROP) prediction for deep complex formations, a dynamic modeling method based on frequency domain perception and adaptive feedback is proposed. The method utilizes sliding windows and Fast Fourier Transform (FFT) to extract frequency domain features from real-time data streams, quantifying the matching degree of working conditions between the main well and neighboring wells via cosine similarity. An innovative dynamic threshold mechanism based on
2026, 51(8): 3102-3117.
doi: 10.3799/dqkx.2026.218
Abstract:
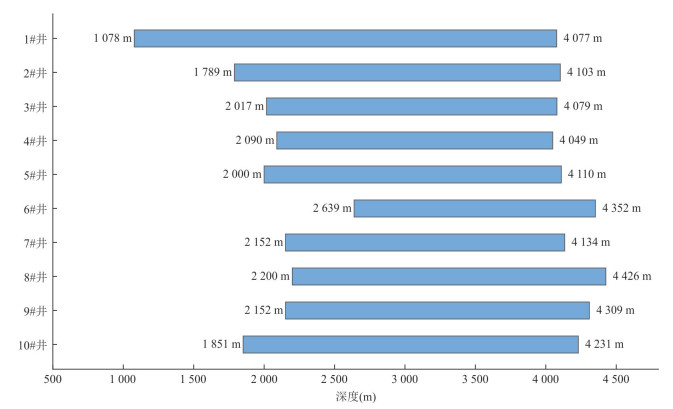
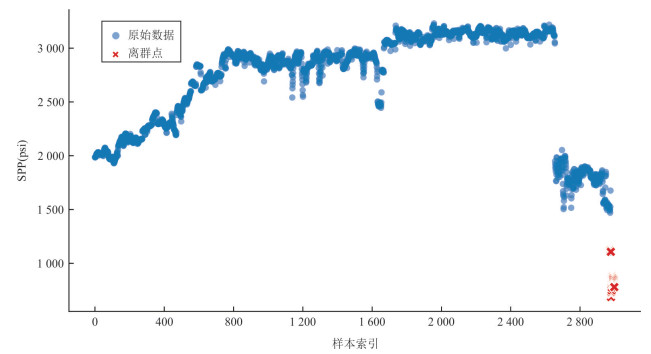
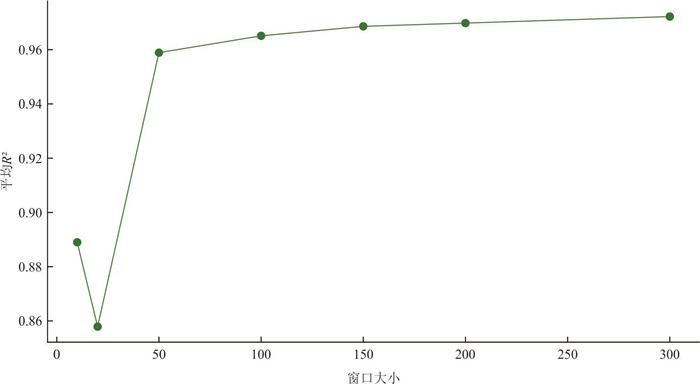
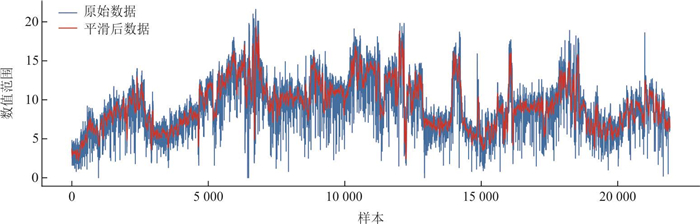
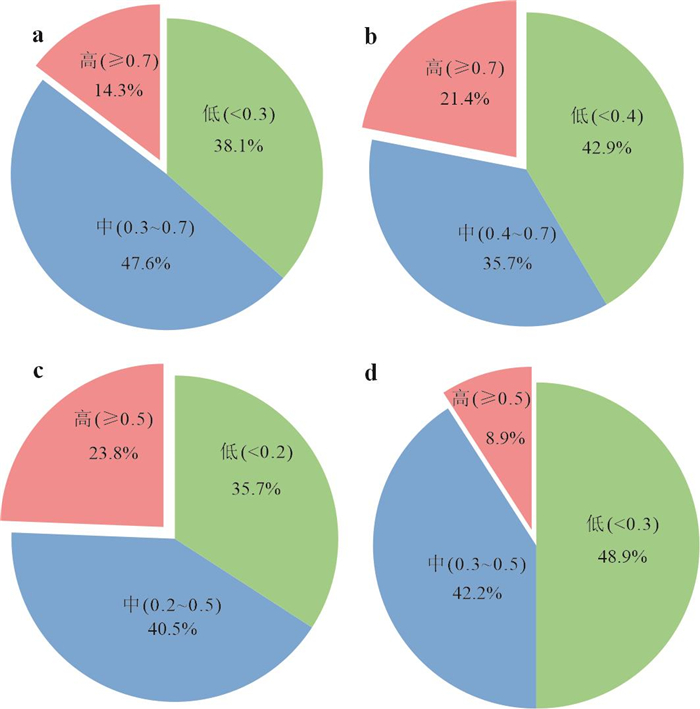
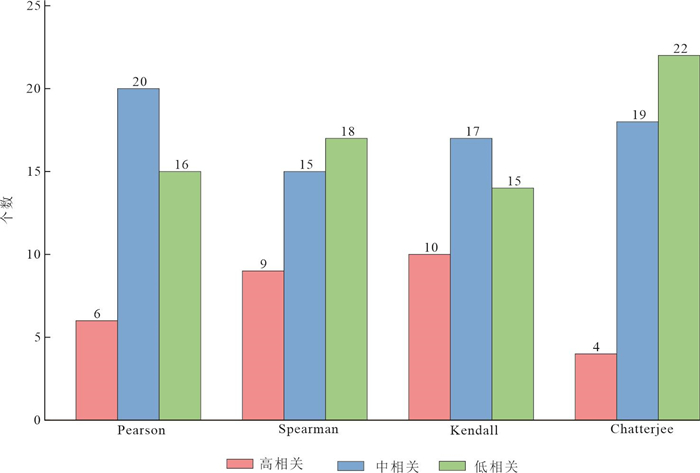
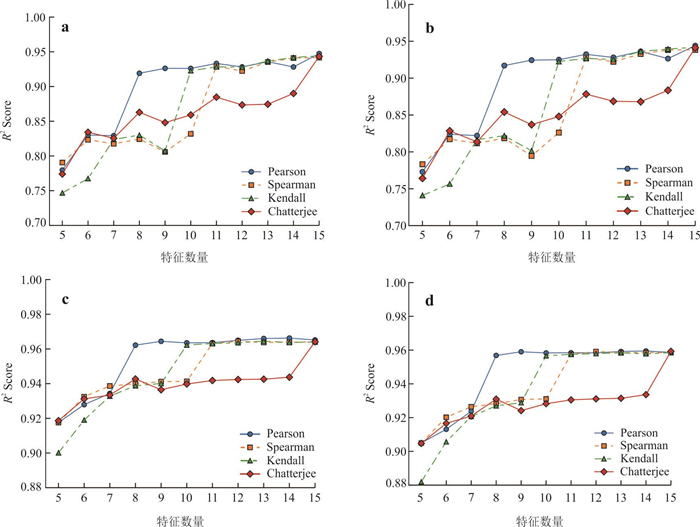
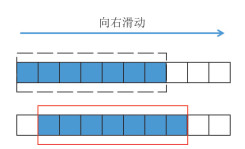
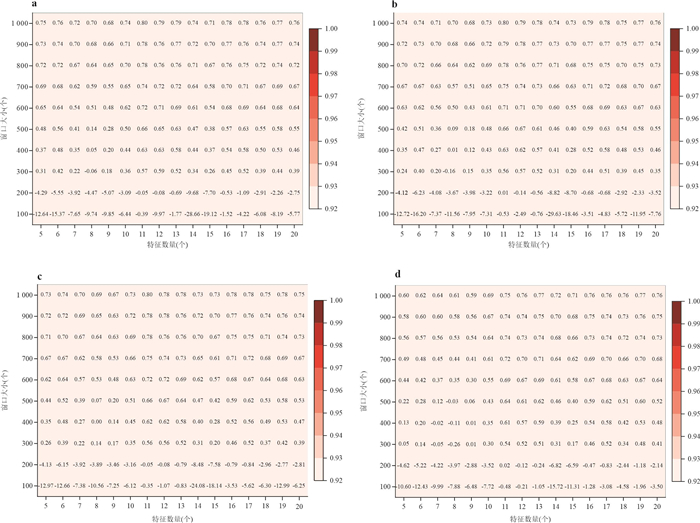
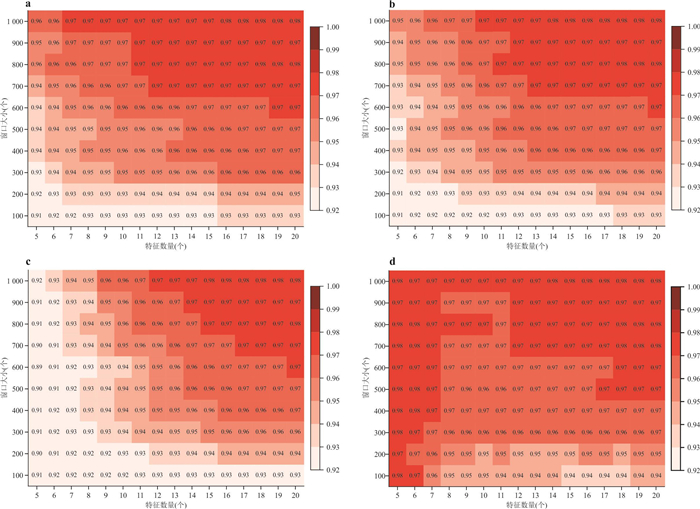
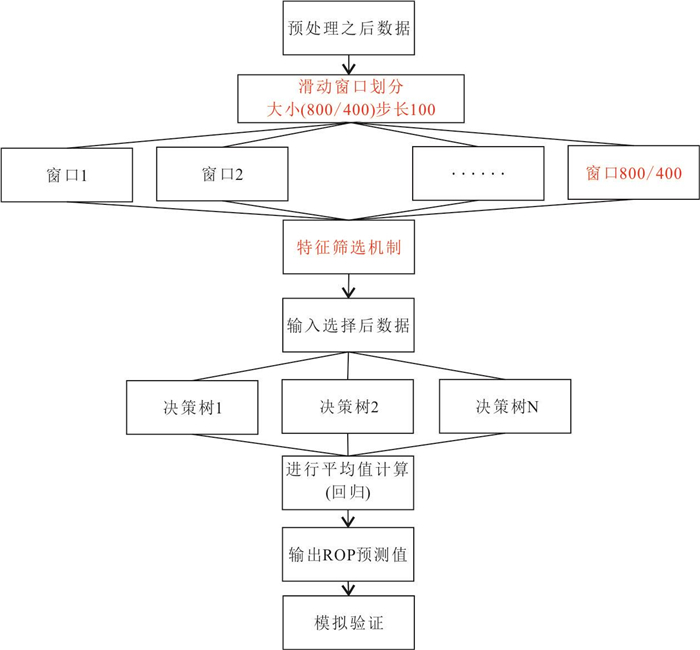
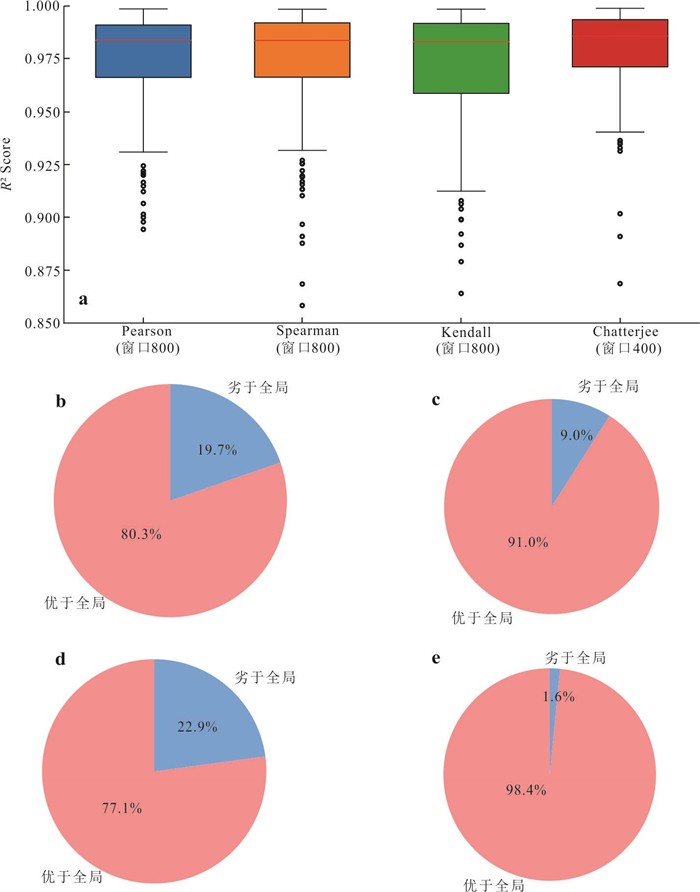
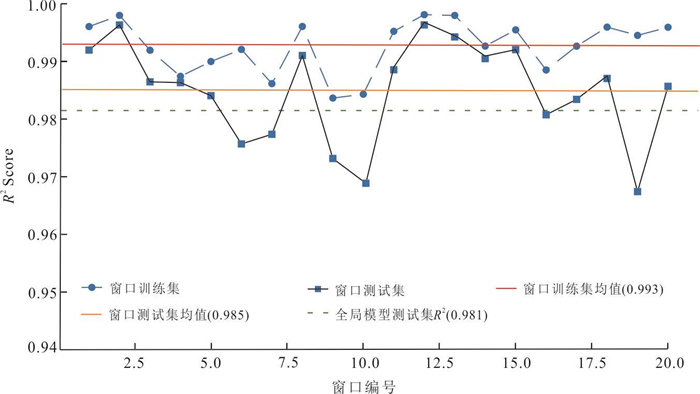
Aiming at the problems of low prediction accuracy of rate of penetration (ROP) during drilling in complex formations and strong non-monotonic, nonlinear coupling among parameters: traditional correlation coefficients such as Pearson and Spearman mainly measure linear or monotonic relationships, which cannot effectively characterize such complex dependencies and tend to result in underestimation of key features, this paper aims to develop a dynamic optimal correlation modeling algorithm. This approach is designed to enhance both the accuracy and engineering applicability of ROP prediction. Using 21, 912 data sets from ten oil and gas wells, we performed data preprocessing including median imputation for missing values, IQR-based outlier removal, and Savitzky-Golay smoothing. By comparing four correlation theories: Pearson, Spearman, Kendall, and Chatterjee: key parameters affecting ROP (such as mud density, solid content, and well depth) were identified. A sliding window technique (window size: 400, step size: 100) was introduced to achieve local dynamic modeling, with a Random Forest model serving as the core for regression prediction. Experimental results demonstrate that the Chatterjee algorithm performed best in screening the top 5 features. The architecture combining the sliding window technique with the Random Forest model achieved an average R2 of 0.985 on the window test set of the 10th test well, representing a significant improvement over global static modeling (R2=0.96). The resulting optimal correlation ROP modeling algorithm can adapt to abrupt formation changes and effectively capture local correlations between parameters. This provides a high-precision solution for real-time ROP optimization and it provides effective technical support for the transformation of drilling engineering from empirical trial-and-error to data-driven decision-making.
Aiming at the problems of low prediction accuracy of rate of penetration (ROP) during drilling in complex formations and strong non-monotonic, nonlinear coupling among parameters: traditional correlation coefficients such as Pearson and Spearman mainly measure linear or monotonic relationships, which cannot effectively characterize such complex dependencies and tend to result in underestimation of key features, this paper aims to develop a dynamic optimal correlation modeling algorithm. This approach is designed to enhance both the accuracy and engineering applicability of ROP prediction. Using 21, 912 data sets from ten oil and gas wells, we performed data preprocessing including median imputation for missing values, IQR-based outlier removal, and Savitzky-Golay smoothing. By comparing four correlation theories: Pearson, Spearman, Kendall, and Chatterjee: key parameters affecting ROP (such as mud density, solid content, and well depth) were identified. A sliding window technique (window size: 400, step size: 100) was introduced to achieve local dynamic modeling, with a Random Forest model serving as the core for regression prediction. Experimental results demonstrate that the Chatterjee algorithm performed best in screening the top 5 features. The architecture combining the sliding window technique with the Random Forest model achieved an average R2 of 0.985 on the window test set of the 10th test well, representing a significant improvement over global static modeling (R2=0.96). The resulting optimal correlation ROP modeling algorithm can adapt to abrupt formation changes and effectively capture local correlations between parameters. This provides a high-precision solution for real-time ROP optimization and it provides effective technical support for the transformation of drilling engineering from empirical trial-and-error to data-driven decision-making.
2026, 51(8): 3118-3131.
doi: 10.3799/dqkx.2026.168
Abstract:
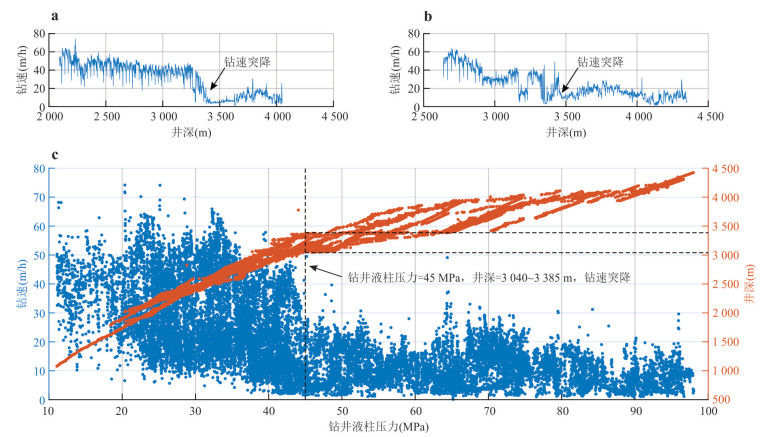
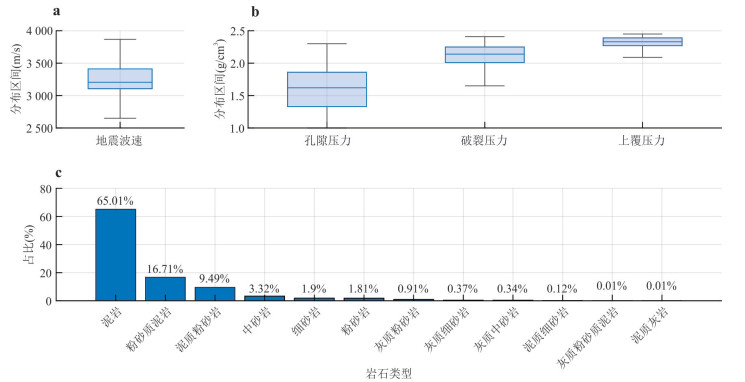
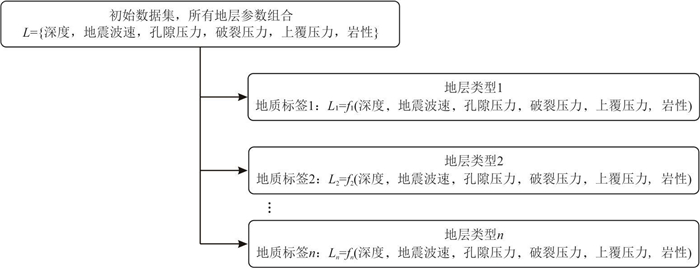
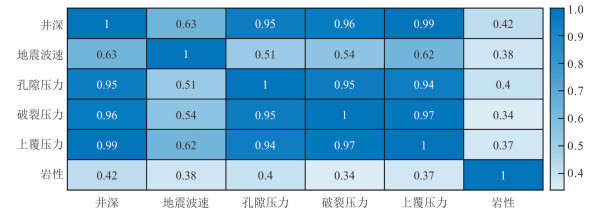
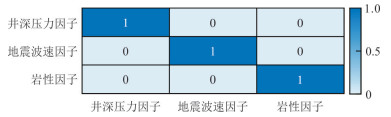
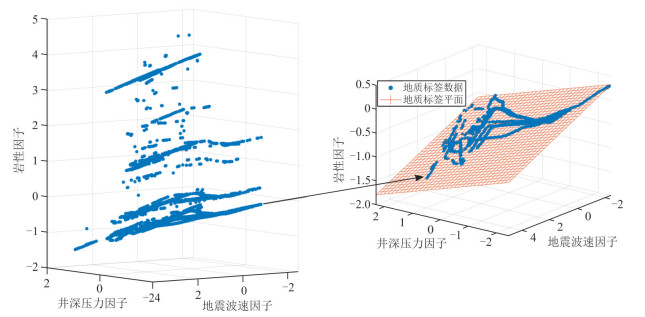
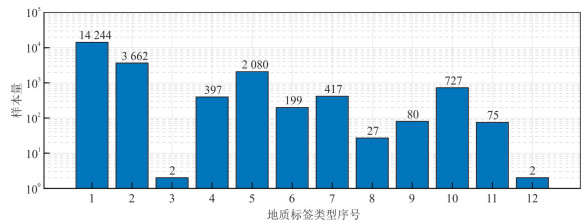
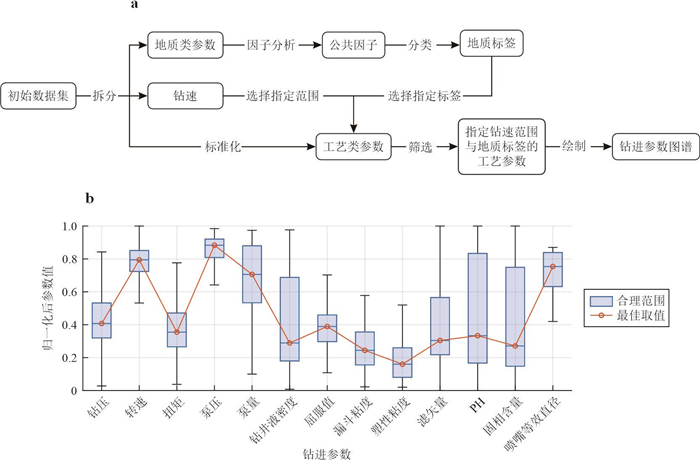
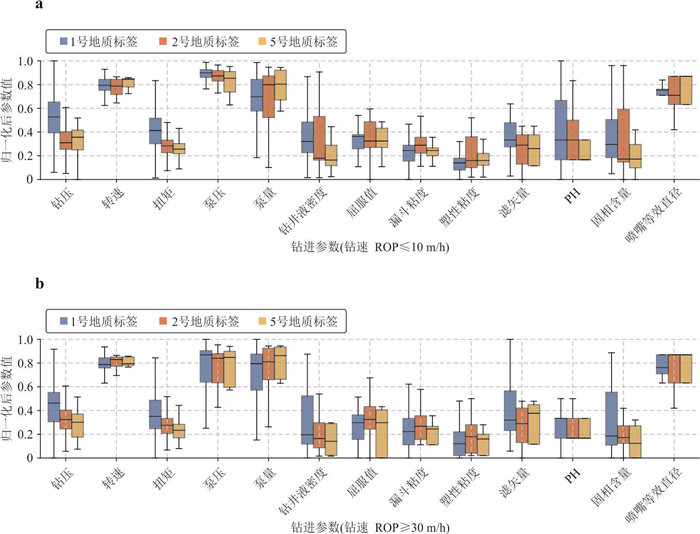
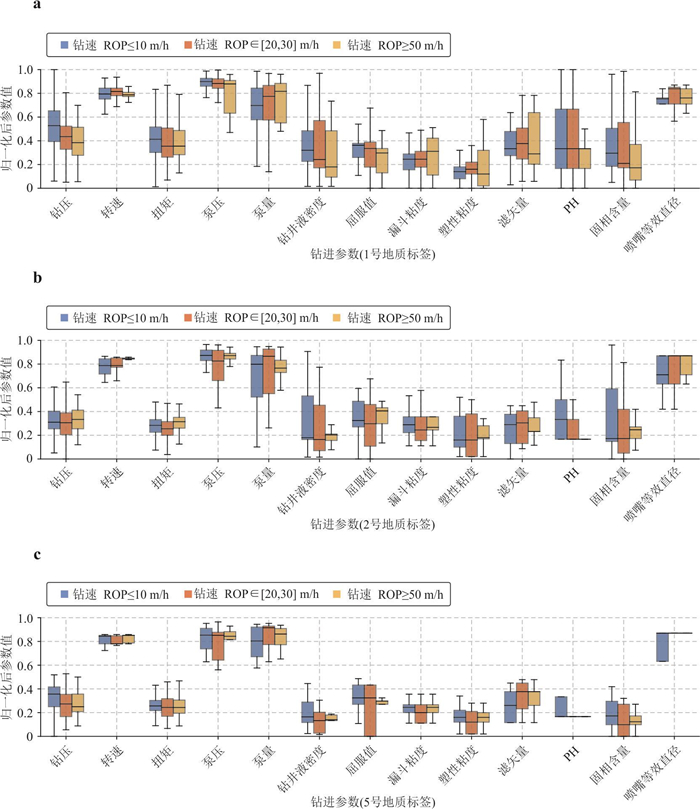
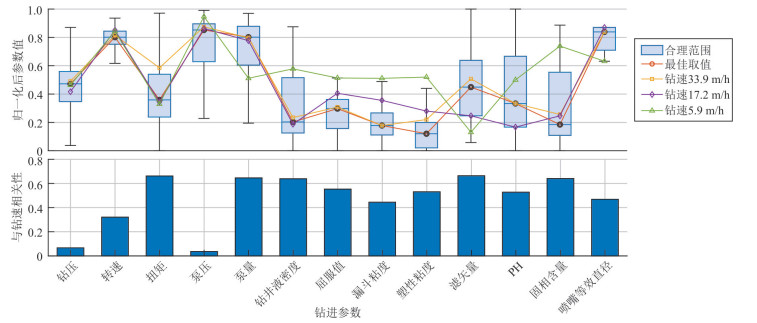
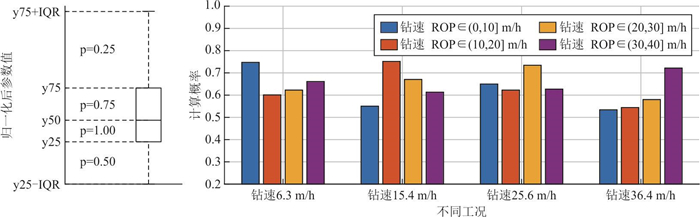
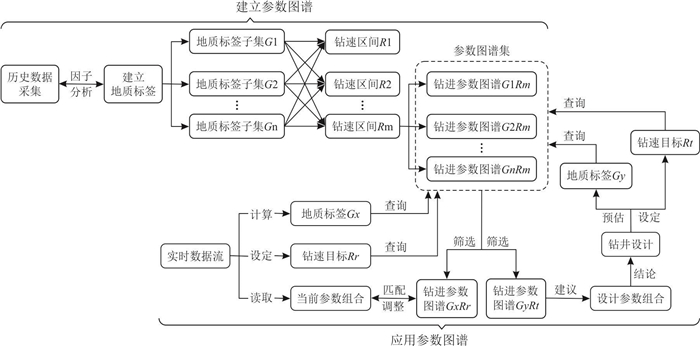
In response to the challenges of complex parameter coupling, rough formation description, and poor model interpretability in predicting and optimizing the rate of penetration (ROP) during drilling, this study aims to achieve geology-driven intelligent optimization of drilling parameters. A "Geological Label-Parameter Atlas" system integrating geological feature quantification and multi-parameter visualization analysis is proposed. Based on actual data from a block in the South China Sea, factor analysis is introduced to reduce multiple geological parameters, such as depth, pressure, seismic wave velocity, and lithology, into three common factors. Accordingly, 12 types of geological labels with clear physical meanings are constructed. The drilling parameter atlas, developed based on these geological labels and target ROP intervals, visually displays the reasonable value ranges and optimal values for over ten engineering parameters under different geological conditions. Based on this atlas, quantitative parameter optimization strategies can be formulated during actual drilling by comparing the deviation between current parameter curves and the atlas, while in the design stage, quantitative prediction of ROP intervals can be achieved by calculating the matching probability between design parameters and multiple sets of atlas.
In response to the challenges of complex parameter coupling, rough formation description, and poor model interpretability in predicting and optimizing the rate of penetration (ROP) during drilling, this study aims to achieve geology-driven intelligent optimization of drilling parameters. A "Geological Label-Parameter Atlas" system integrating geological feature quantification and multi-parameter visualization analysis is proposed. Based on actual data from a block in the South China Sea, factor analysis is introduced to reduce multiple geological parameters, such as depth, pressure, seismic wave velocity, and lithology, into three common factors. Accordingly, 12 types of geological labels with clear physical meanings are constructed. The drilling parameter atlas, developed based on these geological labels and target ROP intervals, visually displays the reasonable value ranges and optimal values for over ten engineering parameters under different geological conditions. Based on this atlas, quantitative parameter optimization strategies can be formulated during actual drilling by comparing the deviation between current parameter curves and the atlas, while in the design stage, quantitative prediction of ROP intervals can be achieved by calculating the matching probability between design parameters and multiple sets of atlas.
2026, 51(8): 3132-3144.
doi: 10.3799/dqkx.2026.113
Abstract:
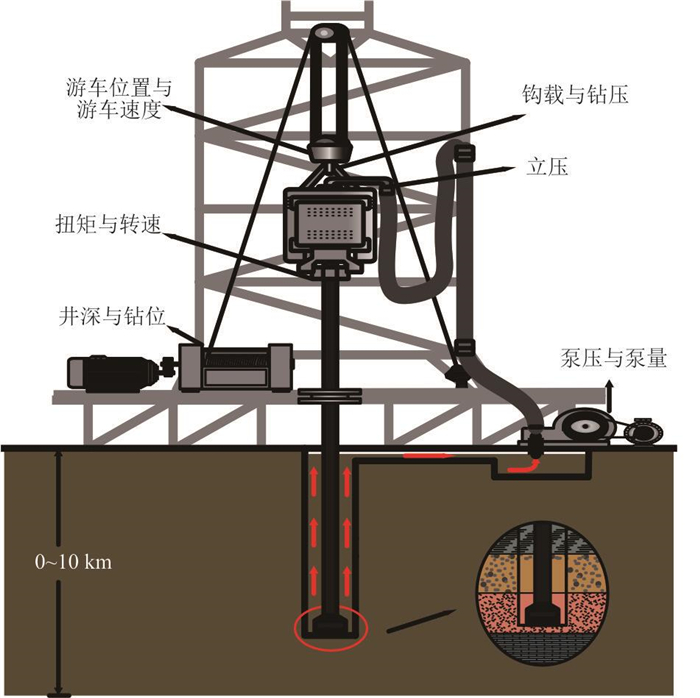
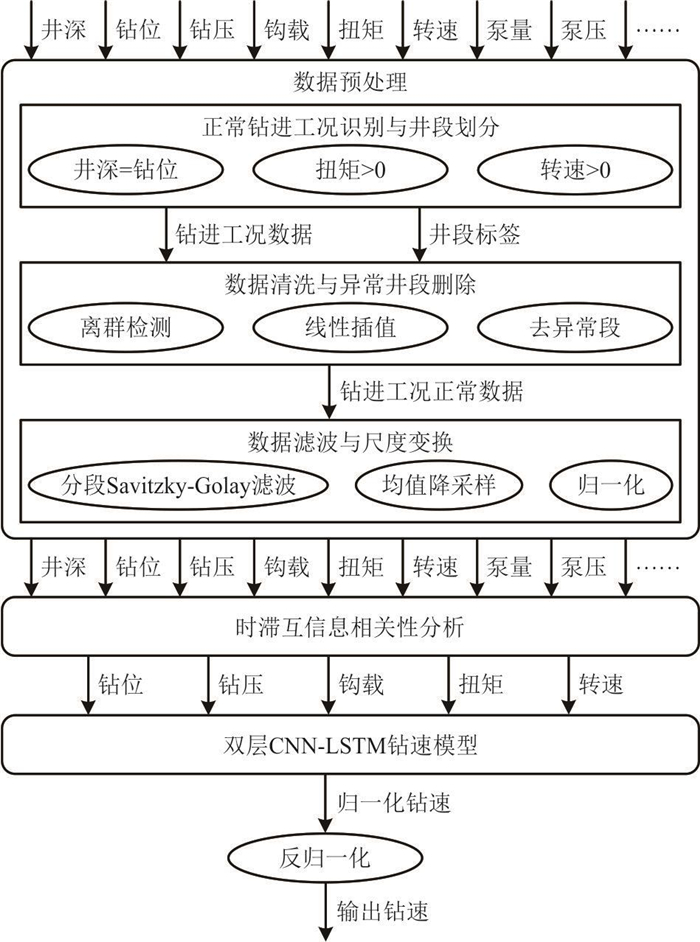
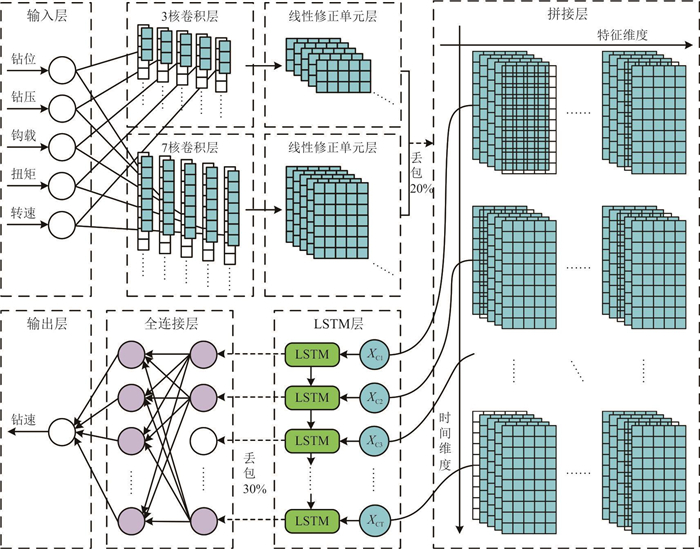
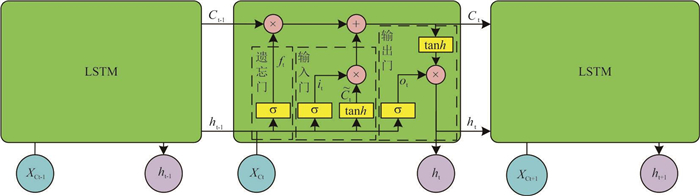
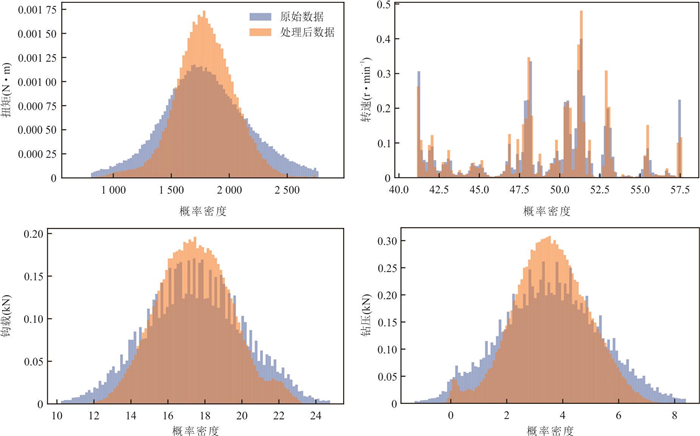
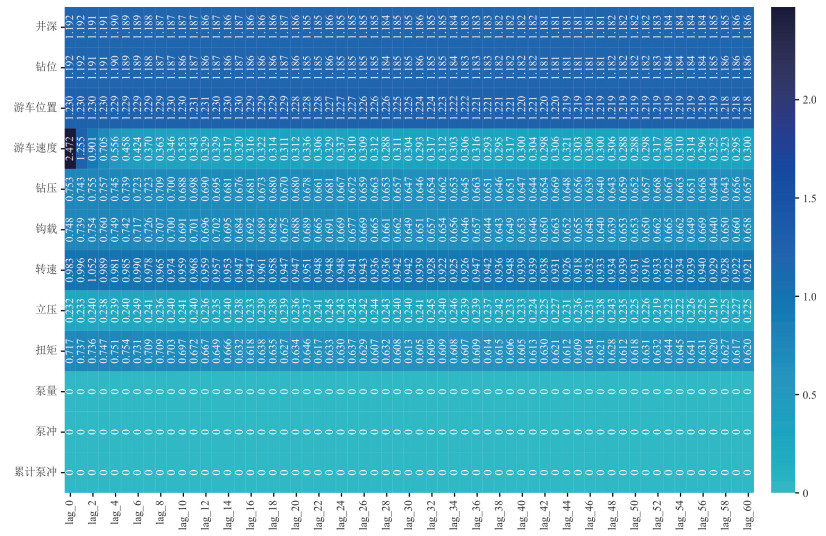
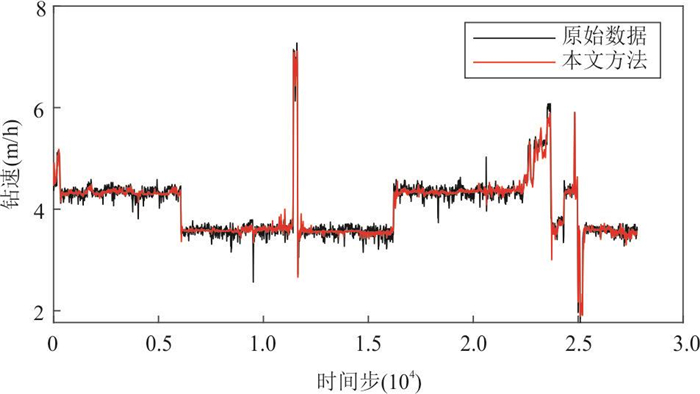
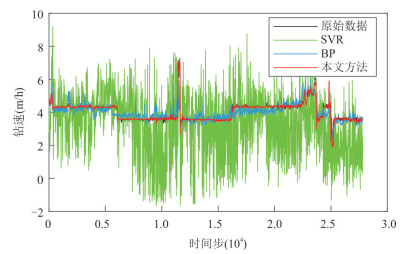
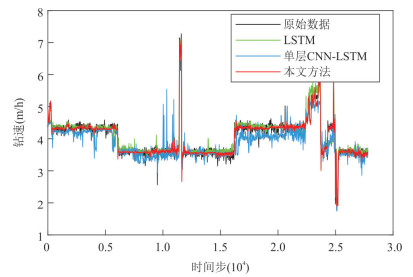
Rate of penetration (ROP) is a key indicator for evaluating drilling efficiency. Its variation is jointly influenced by multiple drilling parameters and exhibits strong coupling and pronounced nonlinear characteristics. The ROP at the current time step is determined not only by the instantaneous drilling parameters and formation conditions, but also closely related to the historical evolution of ROP, drilling parameters, and drilling states over previous time steps, showing evident temporal dependence and sequence memory effects. To address the challenges posed by complex operating conditions, high noise levels in real drilling data, and the difficulty of traditional models in effectively capturing long-term temporal dependencies, this study investigates real drilling operations from a drilling site in Xiangyang and proposes a dual-layer CNN-LSTM-based ROP modeling method. First, to cope with the coexistence of multiple drilling conditions in raw data, a normal drilling condition identification and automatic well-section segmentation approach is developed. Combined with abnormal data cleaning, segment-wise filtering, and scale transformation, a systematic data preprocessing scheme is established. Second, a time-lagged mutual information analysis is employed to quantitatively analyze the nonlinear and temporal correlations between ROP and multiple drilling parameters, based on which the model input variables and the length of the time window are determined. On this basis, a ROP modeling framework is constructed by integrating multi-scale convolutional feature extraction withtemporal sequence modeling through parallel dual-layer CNNs cascaded with an LSTM network. Experimental results demonstrate that the proposed model achieves superior accuracy and stability on real drilling data compared with traditional machine learning models and deep learning models with single network structures. The results indicate that the proposed approach can effectively capture the temporal evolution characteristics of ROP during drilling operations, providing a feasible data-driven solution for ROP modeling under complex drilling conditions.
Rate of penetration (ROP) is a key indicator for evaluating drilling efficiency. Its variation is jointly influenced by multiple drilling parameters and exhibits strong coupling and pronounced nonlinear characteristics. The ROP at the current time step is determined not only by the instantaneous drilling parameters and formation conditions, but also closely related to the historical evolution of ROP, drilling parameters, and drilling states over previous time steps, showing evident temporal dependence and sequence memory effects. To address the challenges posed by complex operating conditions, high noise levels in real drilling data, and the difficulty of traditional models in effectively capturing long-term temporal dependencies, this study investigates real drilling operations from a drilling site in Xiangyang and proposes a dual-layer CNN-LSTM-based ROP modeling method. First, to cope with the coexistence of multiple drilling conditions in raw data, a normal drilling condition identification and automatic well-section segmentation approach is developed. Combined with abnormal data cleaning, segment-wise filtering, and scale transformation, a systematic data preprocessing scheme is established. Second, a time-lagged mutual information analysis is employed to quantitatively analyze the nonlinear and temporal correlations between ROP and multiple drilling parameters, based on which the model input variables and the length of the time window are determined. On this basis, a ROP modeling framework is constructed by integrating multi-scale convolutional feature extraction withtemporal sequence modeling through parallel dual-layer CNNs cascaded with an LSTM network. Experimental results demonstrate that the proposed model achieves superior accuracy and stability on real drilling data compared with traditional machine learning models and deep learning models with single network structures. The results indicate that the proposed approach can effectively capture the temporal evolution characteristics of ROP during drilling operations, providing a feasible data-driven solution for ROP modeling under complex drilling conditions.
2026, 51(8): 3145-3157.
doi: 10.3799/dqkx.2026.146
Abstract:
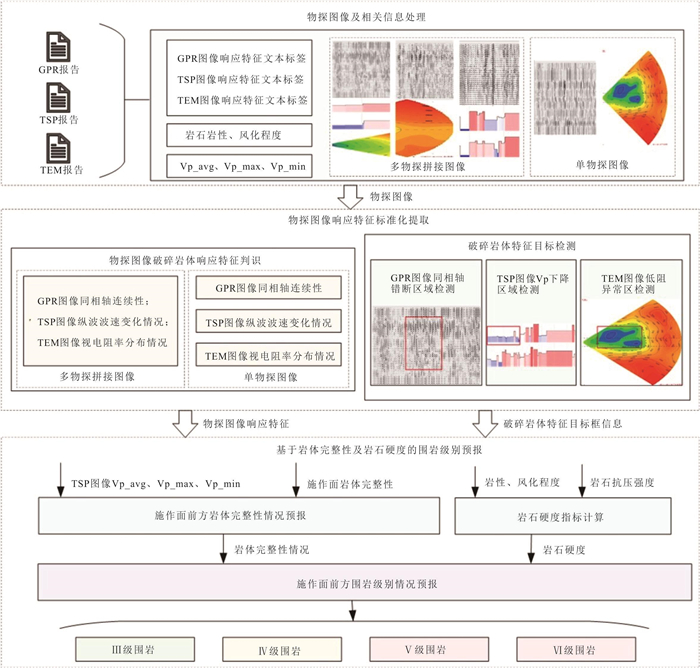
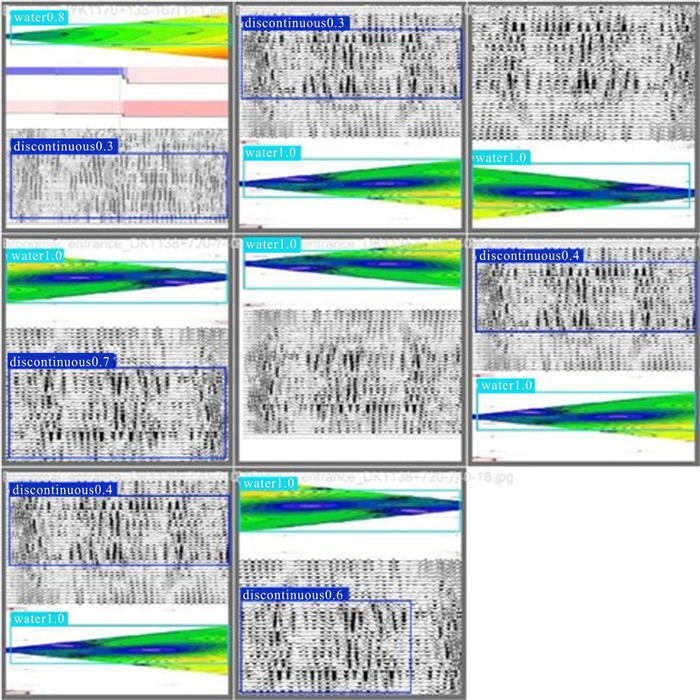
Deep geotechnical engineering involves complex, hidden geology and high risks, making accurate rock classification critical. This study presents an intelligent prediction method that fuses image-text multimodal geophysical data via mileage-aligned survey images. A cross-modal matching model extracts fractured-rock features, localized by an object detector. Text descriptors, bounding-box sequences, and geological parameters are combined into a unified vector; a multi-output random forest predicts rock classes along mileage. Mutual correction between text and detection reduces false alarms and missed detections. Field tests show 92% accuracy, supporting intelligent advance forecasting.
Deep geotechnical engineering involves complex, hidden geology and high risks, making accurate rock classification critical. This study presents an intelligent prediction method that fuses image-text multimodal geophysical data via mileage-aligned survey images. A cross-modal matching model extracts fractured-rock features, localized by an object detector. Text descriptors, bounding-box sequences, and geological parameters are combined into a unified vector; a multi-output random forest predicts rock classes along mileage. Mutual correction between text and detection reduces false alarms and missed detections. Field tests show 92% accuracy, supporting intelligent advance forecasting.
2026, 51(8): 3158-3169.
doi: 10.3799/dqkx.2026.125
Abstract:
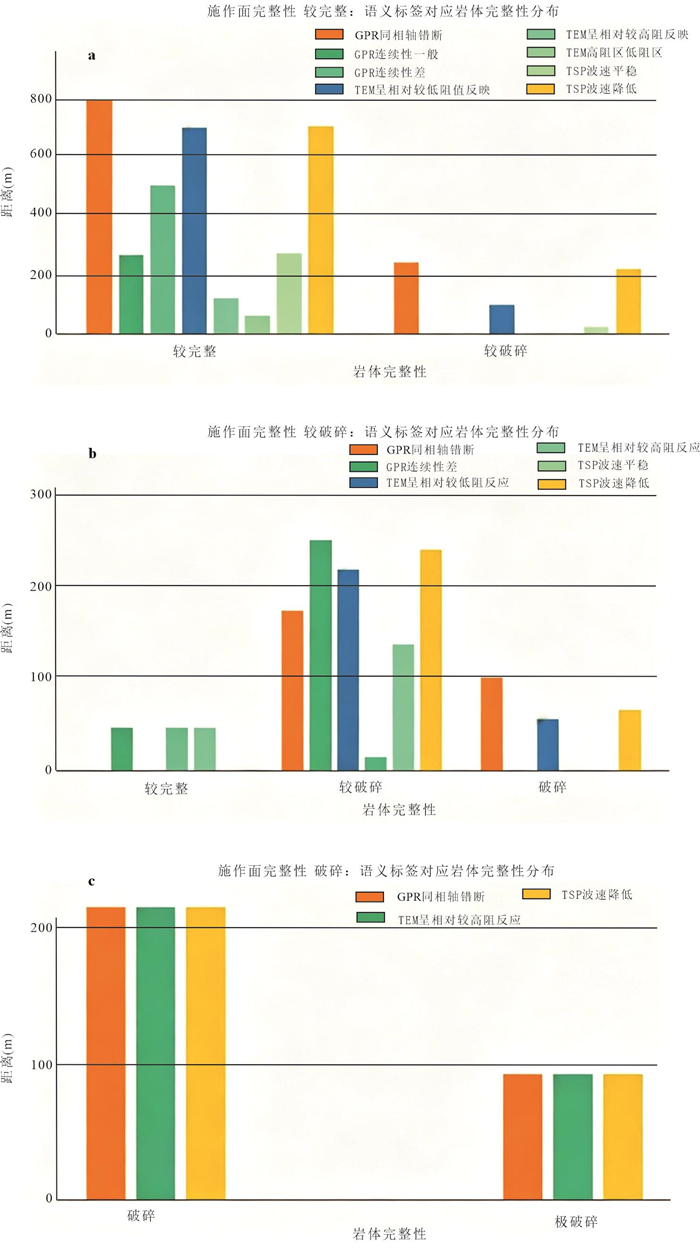
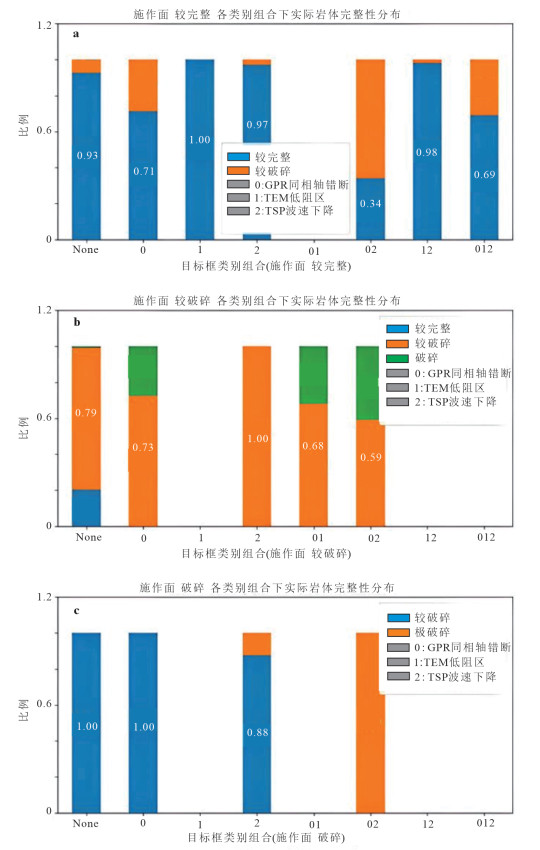
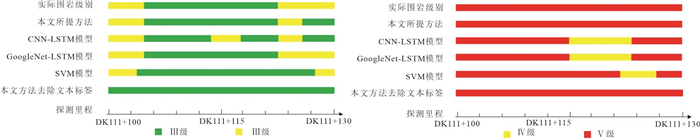
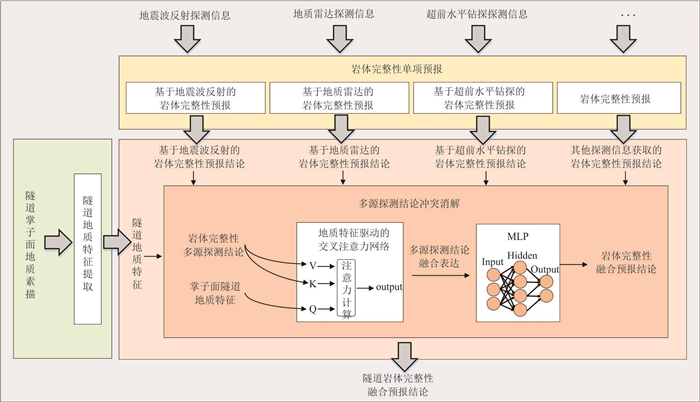
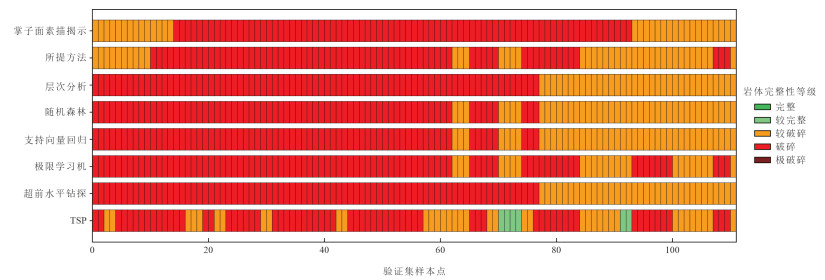
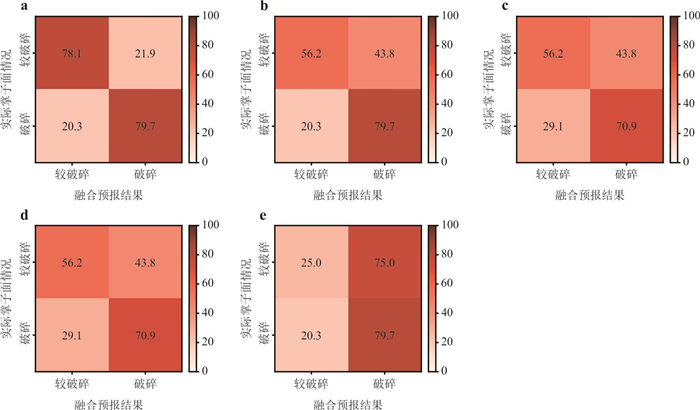
In deep geological engineering, accurate prediction of rock-mass integrity and sensing of geological conditions ahead are important for construction safety and efficiency. However, conclusions from multiple probing methods often conflict due to differences in sensing mechanisms, noise interference, and other factors, making effective fusion difficult. This paper proposes a geology-guided fusion method for rock-mass integrity prediction using multi-source probing information. Geological features serve as guidance, and a cross-attention mechanism adaptively adjusts the contribution of each probing conclusion under actual geological conditions, thereby resolving conflicts among multi-source results and generating a fused integrity prediction. Applied to a real deep tunnel project, the proposed method outperforms several commonly used methods in prediction accuracy and yields highly interpretable results.
In deep geological engineering, accurate prediction of rock-mass integrity and sensing of geological conditions ahead are important for construction safety and efficiency. However, conclusions from multiple probing methods often conflict due to differences in sensing mechanisms, noise interference, and other factors, making effective fusion difficult. This paper proposes a geology-guided fusion method for rock-mass integrity prediction using multi-source probing information. Geological features serve as guidance, and a cross-attention mechanism adaptively adjusts the contribution of each probing conclusion under actual geological conditions, thereby resolving conflicts among multi-source results and generating a fused integrity prediction. Applied to a real deep tunnel project, the proposed method outperforms several commonly used methods in prediction accuracy and yields highly interpretable results.
2026, 51(8): 3170-3180.
doi: 10.3799/dqkx.2026.102
Abstract:
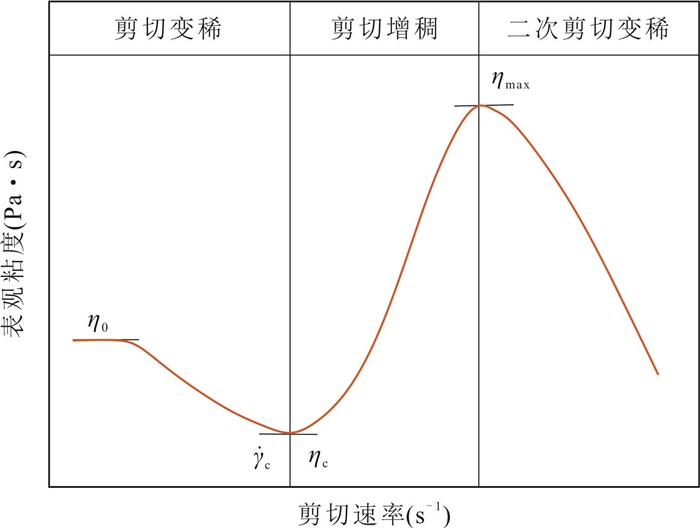
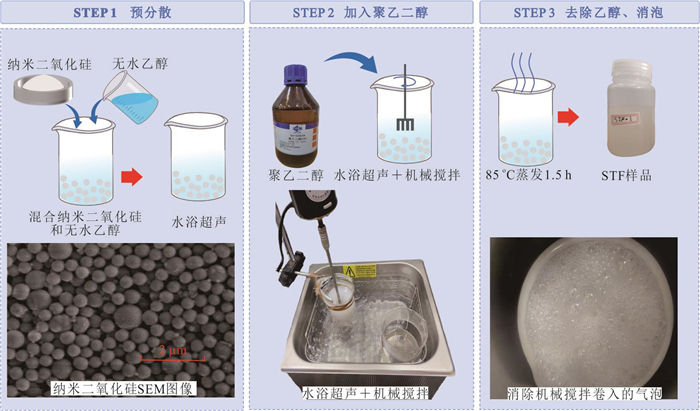
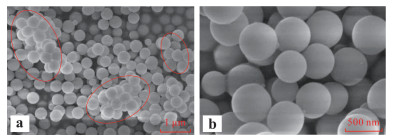
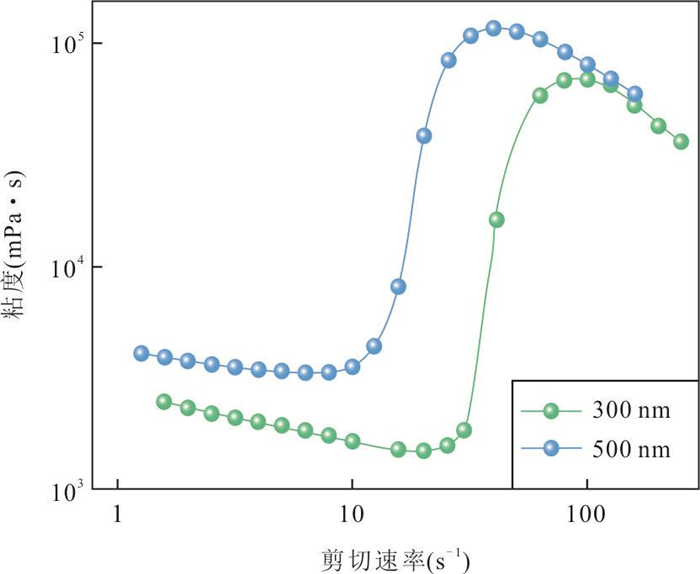
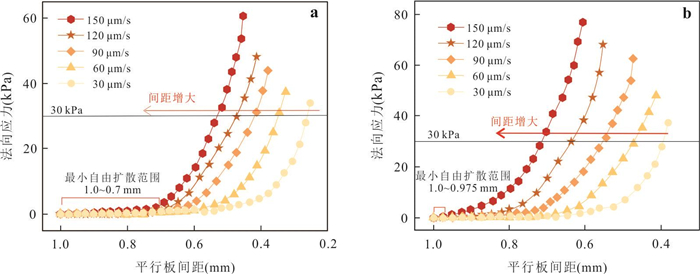
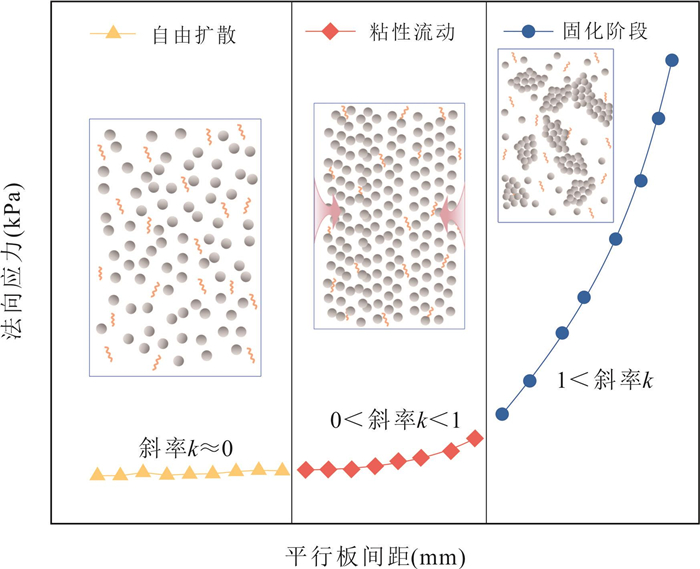
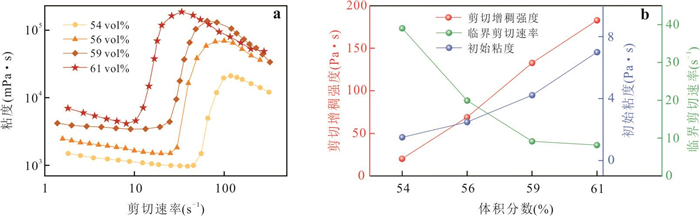
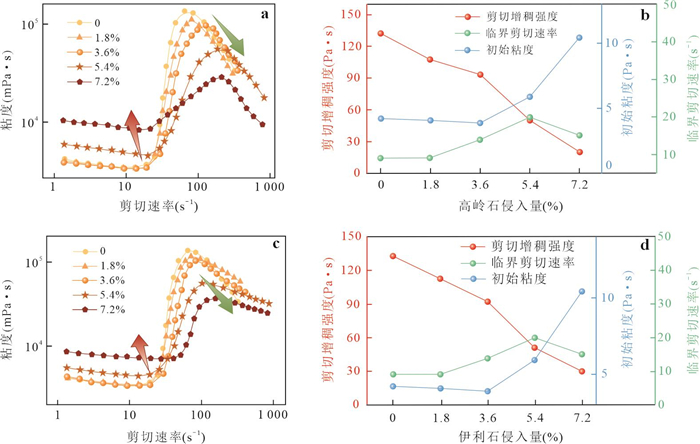
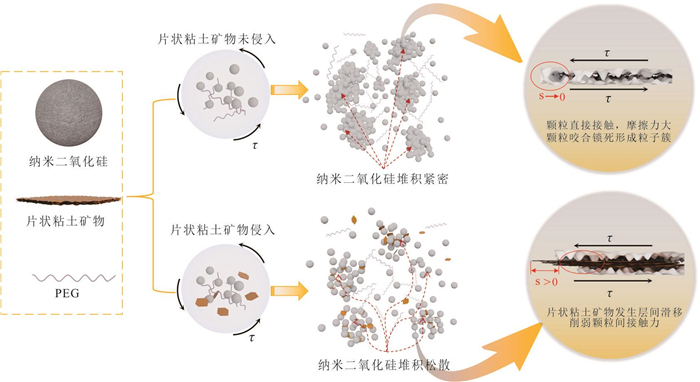
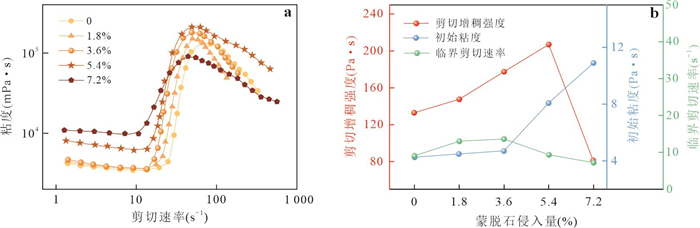
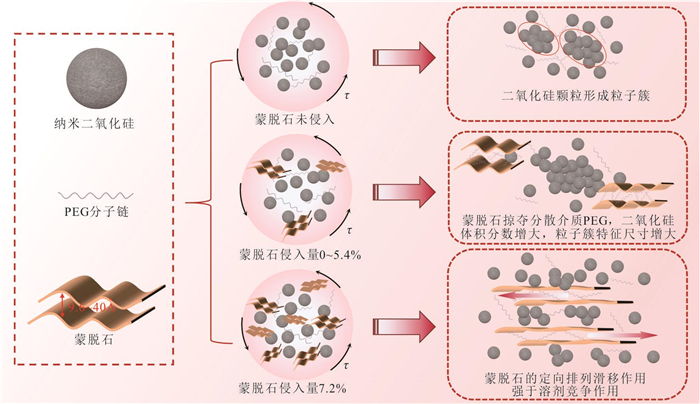
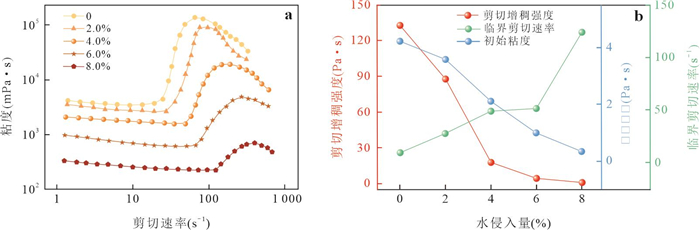
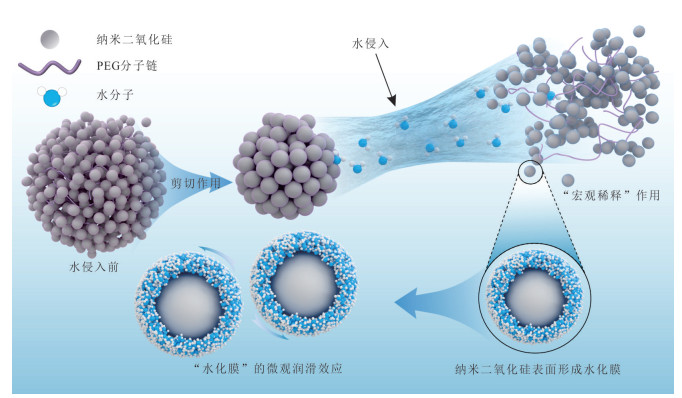
Drilling fluid loss results in significant material wastage and can lead to severe accidents such as borehole instability. To elucidate the effects of formation clay minerals and water intrusion on the shear thickening response of smart plugging drilling fluids, shear thickening fluids (STFs) were prepared using nano-silica and polyethylene glycol (PEG). The nano-silica was characterized by SEM, nitrogen adsorption-desorption and the balance bottle method.The STFs were characterized via squeeze flow and steady-state shear tests. Experiments were designed involving the intrusion of illite, kaolinite, and montmorillonite at concentrations of 0, 1.8%, 3.6%, 5.4%, and 7.2%, as well as water intrusion at 0, 2%, 4%, 6%, and 8%. The results indicate that the intrusion of kaolinite and illite reduced the maximum viscosity of the STF by 79.8% and 72.9%, respectively, due to the interlayer slippage effect. In contrast, the intrusion of 5.4% montmorillonite increased the thickening intensity of the STF by 56.4%. However, 8% water intrusion significantly diluted and inhibited the thickening characteristics of the STF, causing a 99.6% decrease in shear thickening intensity. This study provides a theoretical reference for the application of shear-thickening-based smart plugging drilling fluids.
Drilling fluid loss results in significant material wastage and can lead to severe accidents such as borehole instability. To elucidate the effects of formation clay minerals and water intrusion on the shear thickening response of smart plugging drilling fluids, shear thickening fluids (STFs) were prepared using nano-silica and polyethylene glycol (PEG). The nano-silica was characterized by SEM, nitrogen adsorption-desorption and the balance bottle method.The STFs were characterized via squeeze flow and steady-state shear tests. Experiments were designed involving the intrusion of illite, kaolinite, and montmorillonite at concentrations of 0, 1.8%, 3.6%, 5.4%, and 7.2%, as well as water intrusion at 0, 2%, 4%, 6%, and 8%. The results indicate that the intrusion of kaolinite and illite reduced the maximum viscosity of the STF by 79.8% and 72.9%, respectively, due to the interlayer slippage effect. In contrast, the intrusion of 5.4% montmorillonite increased the thickening intensity of the STF by 56.4%. However, 8% water intrusion significantly diluted and inhibited the thickening characteristics of the STF, causing a 99.6% decrease in shear thickening intensity. This study provides a theoretical reference for the application of shear-thickening-based smart plugging drilling fluids.
2026, 51(8): 3181-3190.
doi: 10.3799/dqkx.2025.249
Abstract:
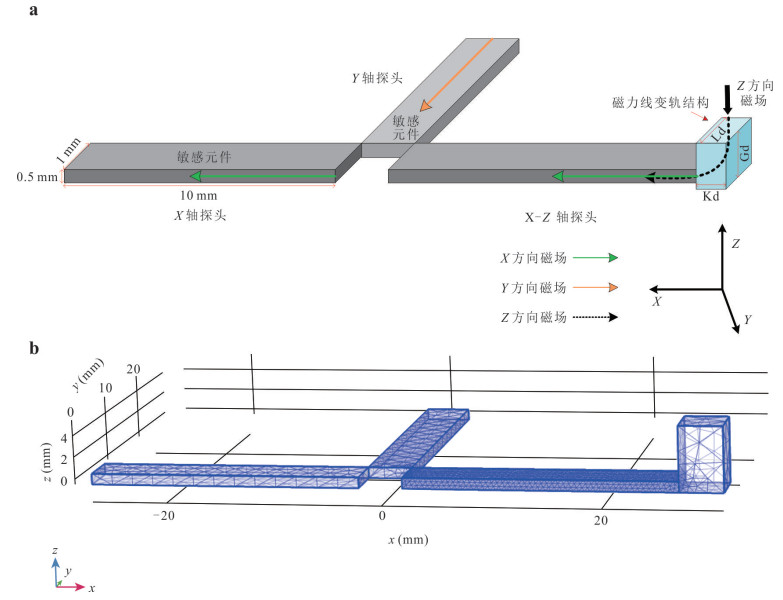
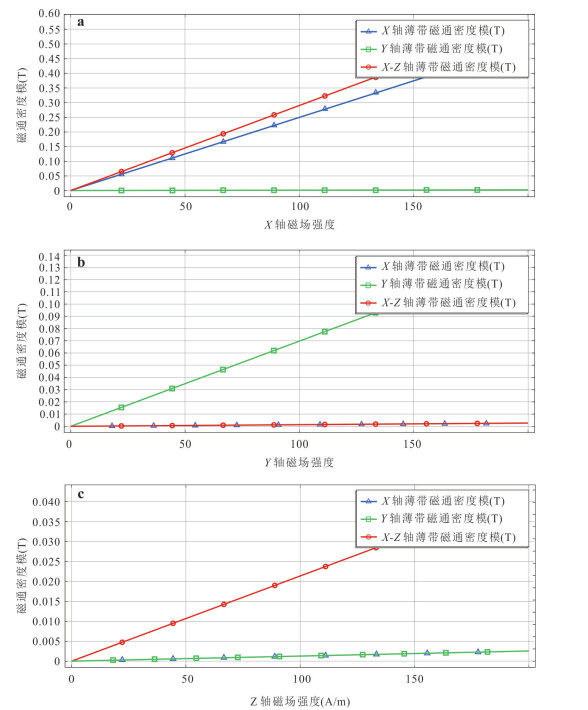
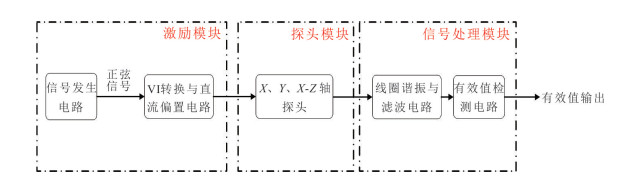
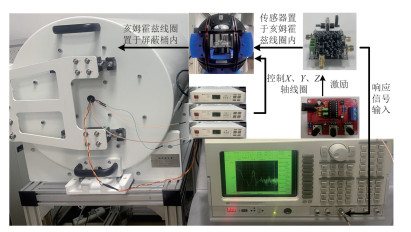
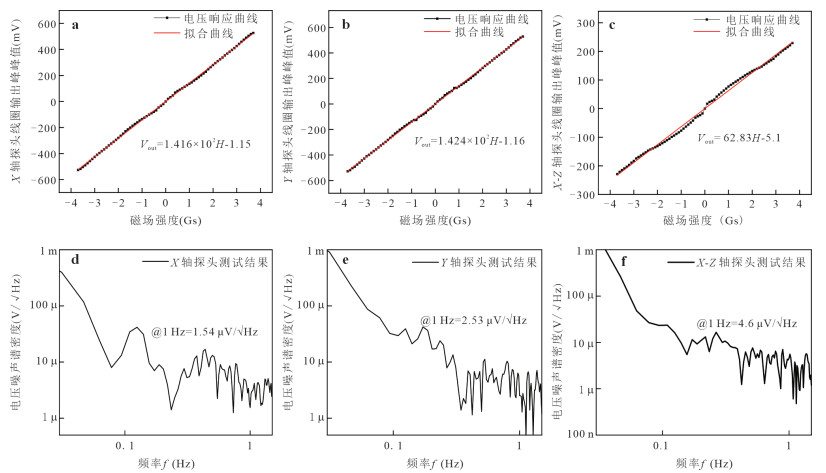
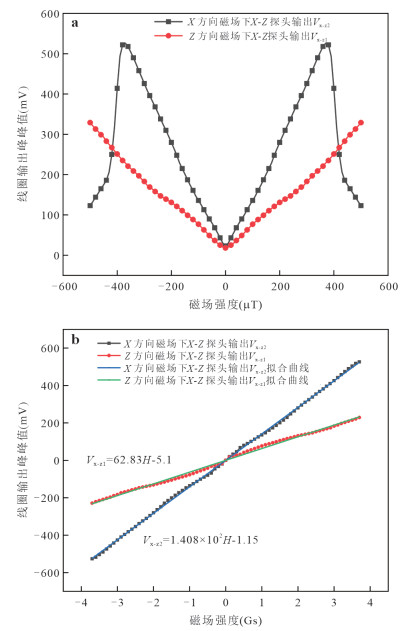
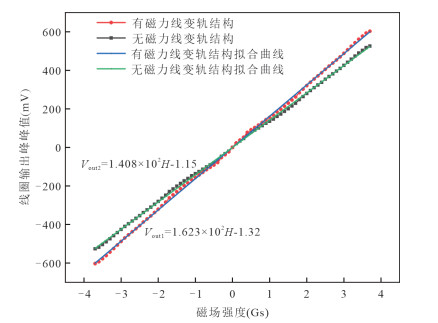
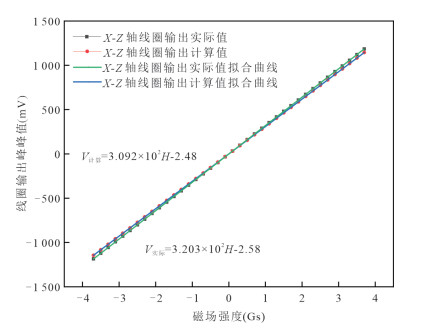
The geomagnetic field exhibits a stable distribution within the Earth's interior, with its direction and intensity serving as a natural reference benchmark. Geomagnetic detection technology provides reliable navigation solutions for complex environments such as deep underground and underwater settings, demonstrating particular advantages in autonomy, concealment, and interference resistance. In geomagnetic navigation detection, triaxial magnetometers are commonly used to acquire the spatial distribution information of the magnetic field, thereby inverting position information. Hence, the accuracy of triaxial magnetometers is one of the key performance indicators in geomagnetic navigation detection. However, conventional triaxial magnetic sensors suffer from large size, complex fabrication processes, and difficulty in ensuring orthogonality. These factors frequently introduce measurement errors that are challenging to correct, thereby limiting precision improvements. To address this, this paper proposes a planar triaxial GMI magnetic sensor design based on the principles of magnetic flux line reorientation and magnetic flux line aggregation. This design orthogonally arranges three magnetic probes within a plane. By employing a magnetic flux line deflection structure, it enables planar measurement of three-dimensional magnetic fields, effectively mitigating errors arising from the inherent orthogonality challenges of conventional triaxial sensors. The constructed triaxial magnetic probes underwent simulation analysis, with the signal composition of each probe resolved and corresponding signal calculation methods derived. Experimental results demonstrate a measurement range of ±370 µT, with output voltage sensitivities of 1 416 Ⅴ/T, 1 424 Ⅴ/T, and 628.3 Ⅴ/T for the X, Y, and Z axes respectively. This approach achieves planar integrated measurement of three-dimensional magnetic fields while maintaining measurement accuracy, notably enhancing detection precision in the Z-direction. It thus provides a novel pathway for developing high-performance triaxial magnetic sensors.
The geomagnetic field exhibits a stable distribution within the Earth's interior, with its direction and intensity serving as a natural reference benchmark. Geomagnetic detection technology provides reliable navigation solutions for complex environments such as deep underground and underwater settings, demonstrating particular advantages in autonomy, concealment, and interference resistance. In geomagnetic navigation detection, triaxial magnetometers are commonly used to acquire the spatial distribution information of the magnetic field, thereby inverting position information. Hence, the accuracy of triaxial magnetometers is one of the key performance indicators in geomagnetic navigation detection. However, conventional triaxial magnetic sensors suffer from large size, complex fabrication processes, and difficulty in ensuring orthogonality. These factors frequently introduce measurement errors that are challenging to correct, thereby limiting precision improvements. To address this, this paper proposes a planar triaxial GMI magnetic sensor design based on the principles of magnetic flux line reorientation and magnetic flux line aggregation. This design orthogonally arranges three magnetic probes within a plane. By employing a magnetic flux line deflection structure, it enables planar measurement of three-dimensional magnetic fields, effectively mitigating errors arising from the inherent orthogonality challenges of conventional triaxial sensors. The constructed triaxial magnetic probes underwent simulation analysis, with the signal composition of each probe resolved and corresponding signal calculation methods derived. Experimental results demonstrate a measurement range of ±370 µT, with output voltage sensitivities of 1 416 Ⅴ/T, 1 424 Ⅴ/T, and 628.3 Ⅴ/T for the X, Y, and Z axes respectively. This approach achieves planar integrated measurement of three-dimensional magnetic fields while maintaining measurement accuracy, notably enhancing detection precision in the Z-direction. It thus provides a novel pathway for developing high-performance triaxial magnetic sensors.
2026, 51(8): 3191-3200.
doi: 10.3799/dqkx.2025.202
Abstract:
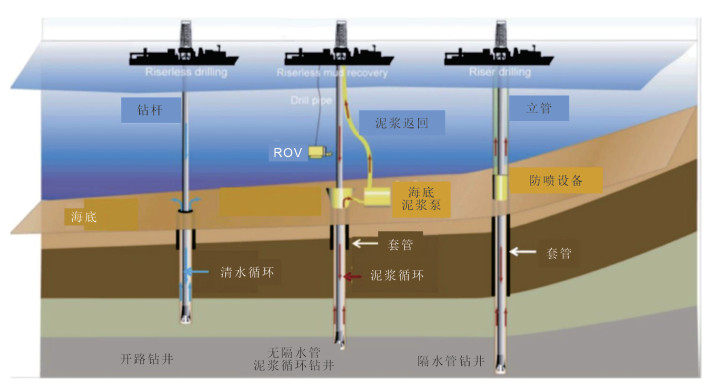
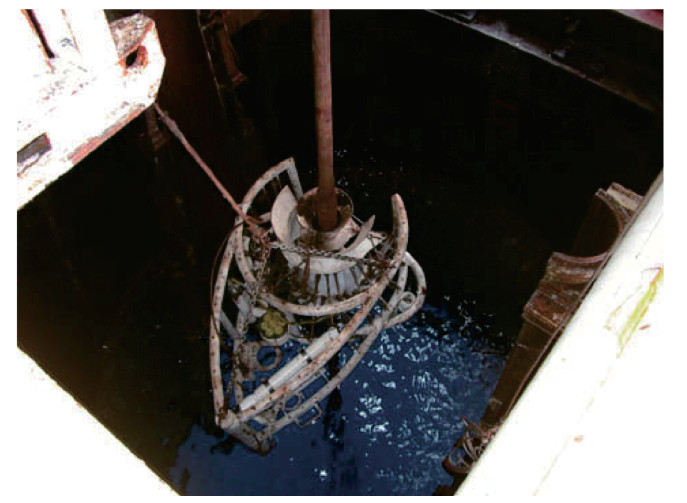
Over the past 60 years, the implementation of a series of deep-sea drilling programs has yielded remarkable advancements in our understanding of the Earth and oceans. This paper reviews the evolution of deep-sea drilling technology, examining key techniques such as dynamic positioning, heave compensation for drill strings, borehole re-entry, mud circulation systems under deep-water conditions, and various rock coring methods. Aligning with China's strategic initiatives to tackle deep-sea drilling challenges, the paper summarizes the application of these technologies during trial voyages and the scientific insights gained.Drawing upon the "Mengxiang" ocean drilling vessel, key development areas have been identified for deep-sea drilling technology, encompassing AI-assisted operations, materials resistant to high temperatures and pressures in the deep sea, high-precision detection, and high-speed communication, offering a valuable reference for future research and application in deep-sea drilling technology.
Over the past 60 years, the implementation of a series of deep-sea drilling programs has yielded remarkable advancements in our understanding of the Earth and oceans. This paper reviews the evolution of deep-sea drilling technology, examining key techniques such as dynamic positioning, heave compensation for drill strings, borehole re-entry, mud circulation systems under deep-water conditions, and various rock coring methods. Aligning with China's strategic initiatives to tackle deep-sea drilling challenges, the paper summarizes the application of these technologies during trial voyages and the scientific insights gained.Drawing upon the "Mengxiang" ocean drilling vessel, key development areas have been identified for deep-sea drilling technology, encompassing AI-assisted operations, materials resistant to high temperatures and pressures in the deep sea, high-precision detection, and high-speed communication, offering a valuable reference for future research and application in deep-sea drilling technology.
2026, 51(8): 3201-3212.
doi: 10.3799/dqkx.2025.205
Abstract:
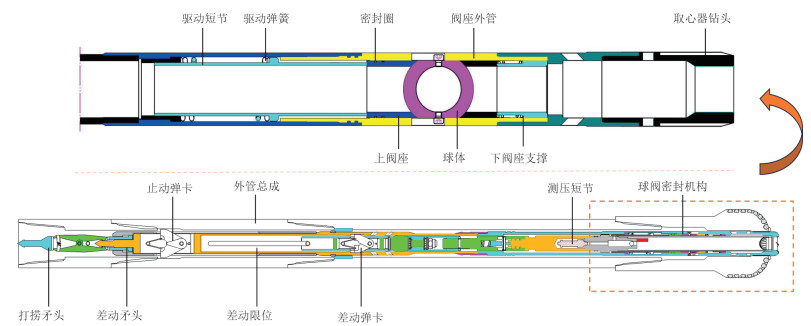
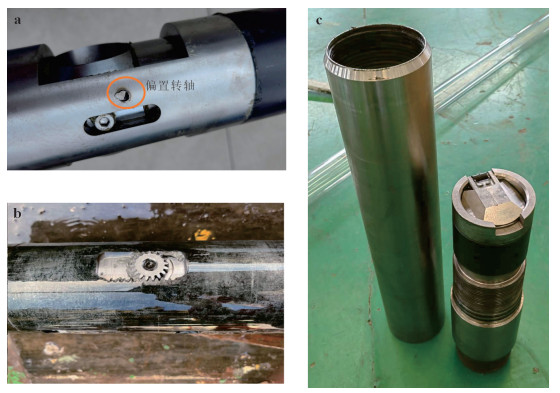
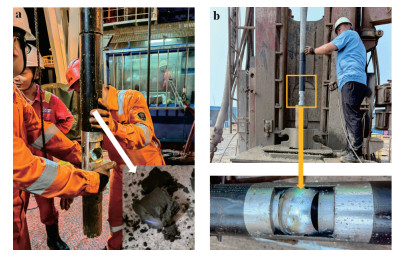
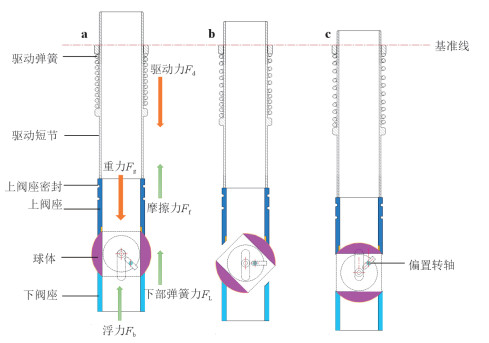
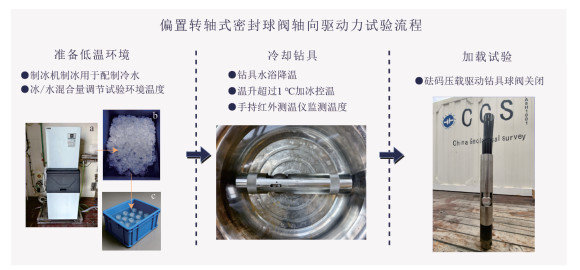
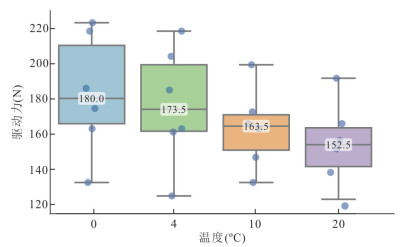
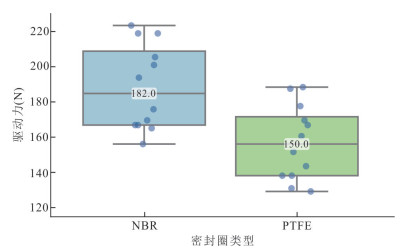
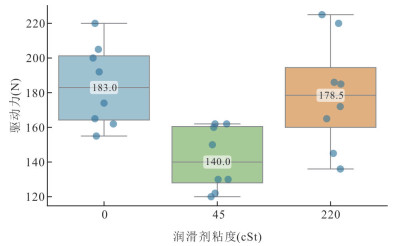
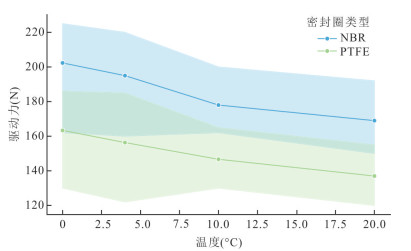
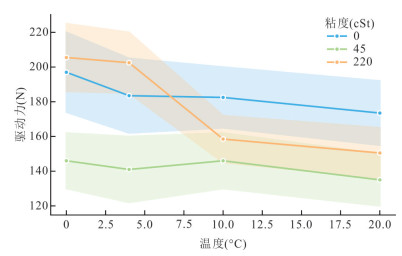
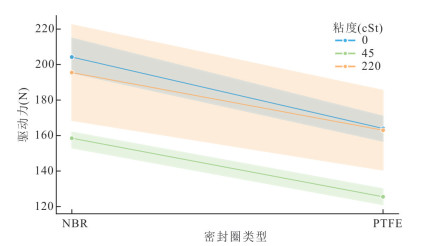
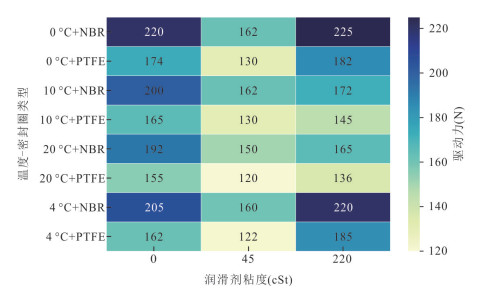
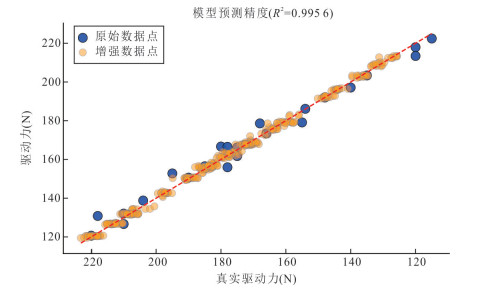
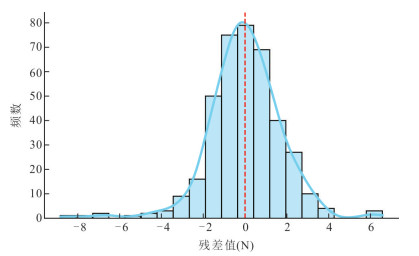
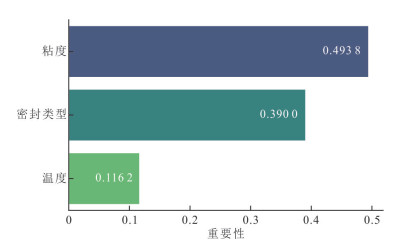
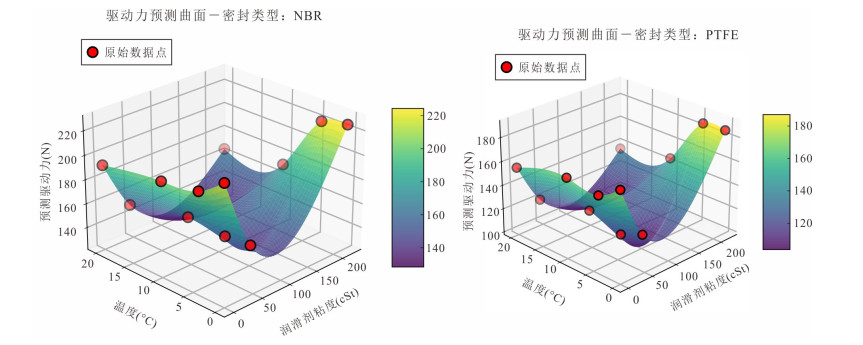
Pressure-Preserved Coring Tools are critical to deep-sea resource assessment and development, and the closure performance of their sealing ball valve directly determines the success of acquiring in situ core samples. Addressing the difficulty of accurately quantifying the ball-valve actuating force under multi-variable interaction effects, this study integrates experiments with machine learning to achieve quantitative prediction across multiple factors. Through comprehensive factorial experiments, we obtain driving-force data under multi-level operating conditions involving temperature, seal-ring type, and lubricant viscosity, and systematically analyze main effects and interactions. The results indicate that lubricant viscosity is the primary influencing factor, exhibiting strong coupling with temperature. Building on these findings, we employ data-augmentation techniques and a gradient boosting regressor to construct a multi-factor prediction model. The model attains an R2 exceeding 0.99, and quantitative feature-importance analysis yields a ranking consistent with experimental trends, validating the effectiveness of the approach. The results provide a reliable basis for the optimized design and materials selection of sealing systems in deep-sea Pressure-Preserved Coring Tools.
Pressure-Preserved Coring Tools are critical to deep-sea resource assessment and development, and the closure performance of their sealing ball valve directly determines the success of acquiring in situ core samples. Addressing the difficulty of accurately quantifying the ball-valve actuating force under multi-variable interaction effects, this study integrates experiments with machine learning to achieve quantitative prediction across multiple factors. Through comprehensive factorial experiments, we obtain driving-force data under multi-level operating conditions involving temperature, seal-ring type, and lubricant viscosity, and systematically analyze main effects and interactions. The results indicate that lubricant viscosity is the primary influencing factor, exhibiting strong coupling with temperature. Building on these findings, we employ data-augmentation techniques and a gradient boosting regressor to construct a multi-factor prediction model. The model attains an R2 exceeding 0.99, and quantitative feature-importance analysis yields a ranking consistent with experimental trends, validating the effectiveness of the approach. The results provide a reliable basis for the optimized design and materials selection of sealing systems in deep-sea Pressure-Preserved Coring Tools.
2026, 51(8): 3213-3223.
doi: 10.3799/dqkx.2026.236
Abstract:
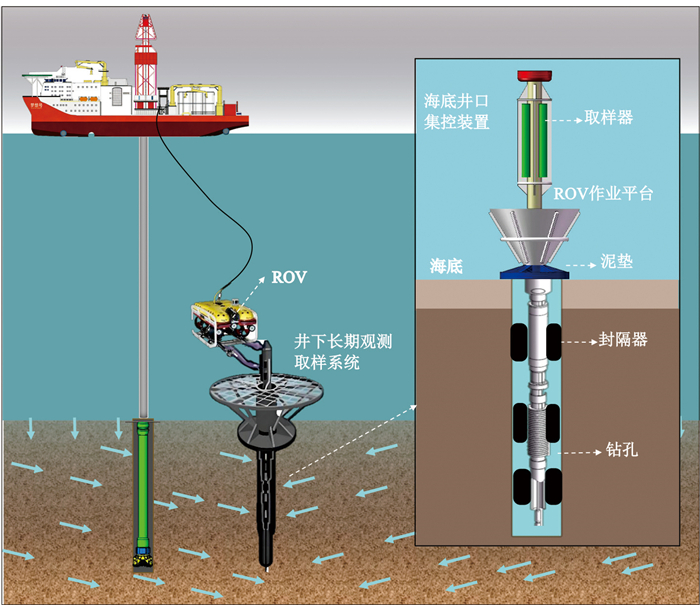
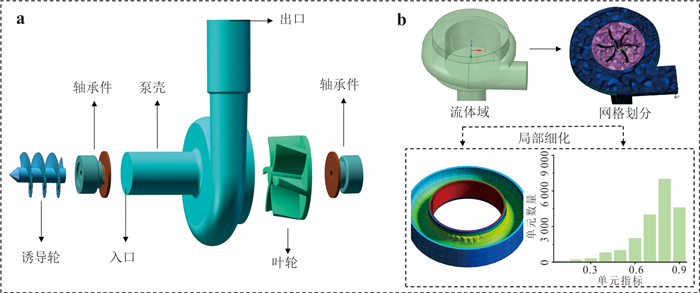
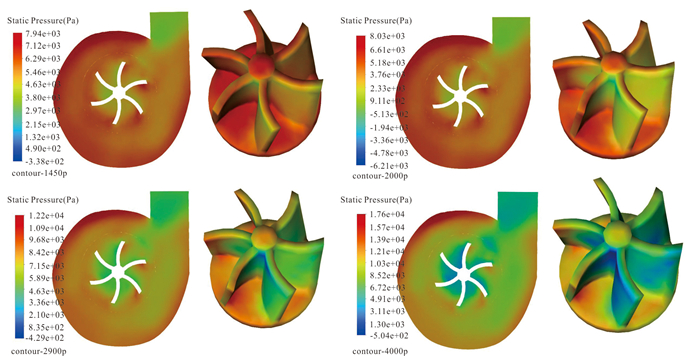
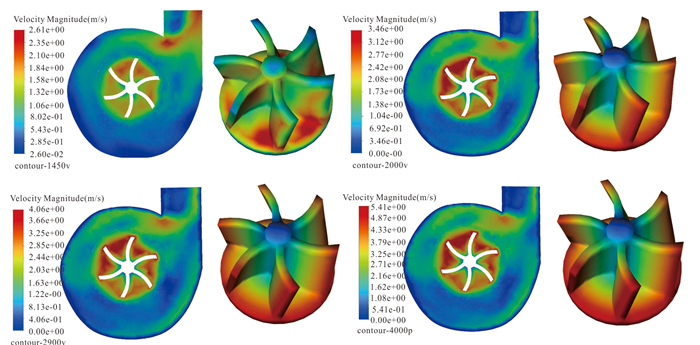
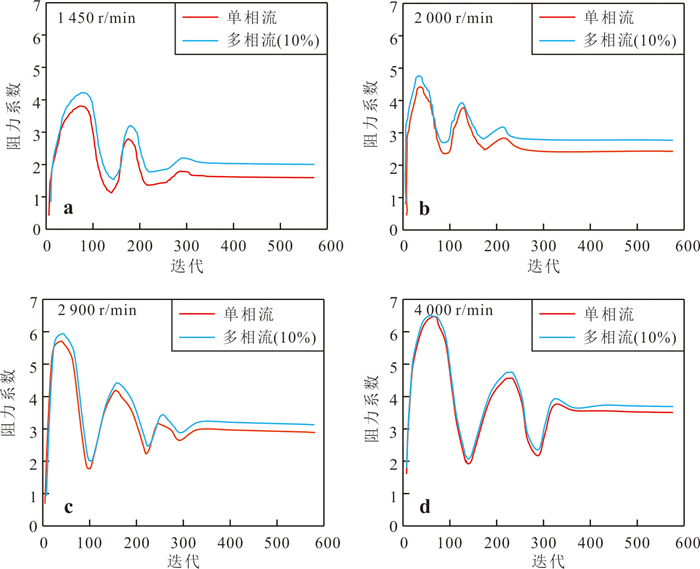
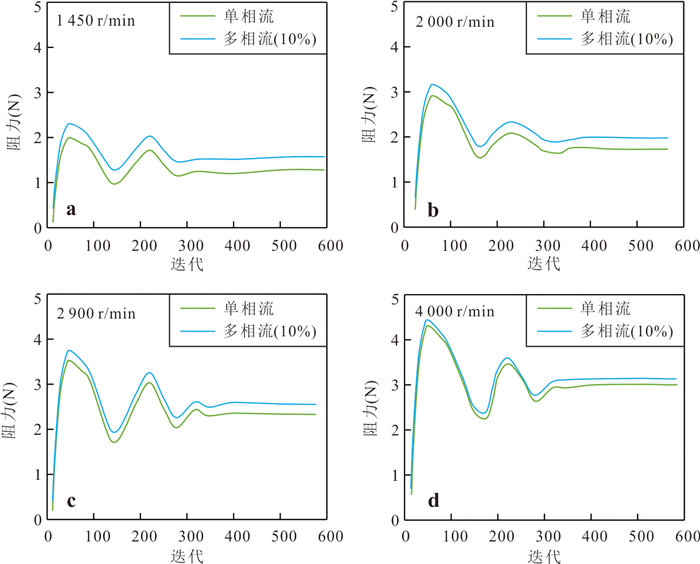
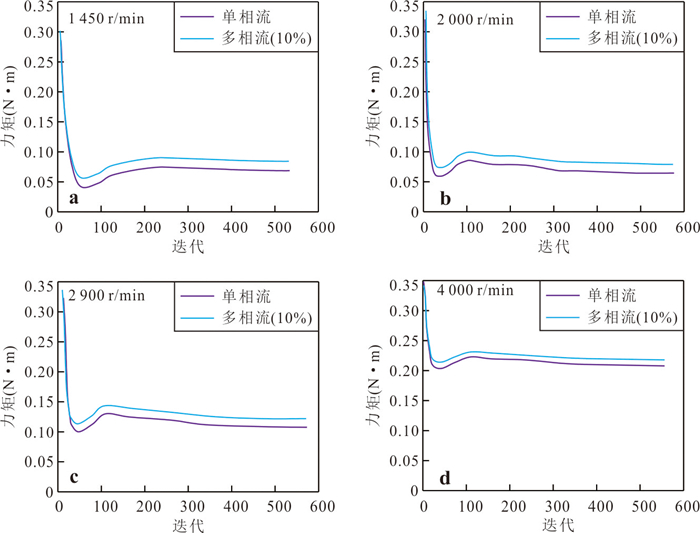
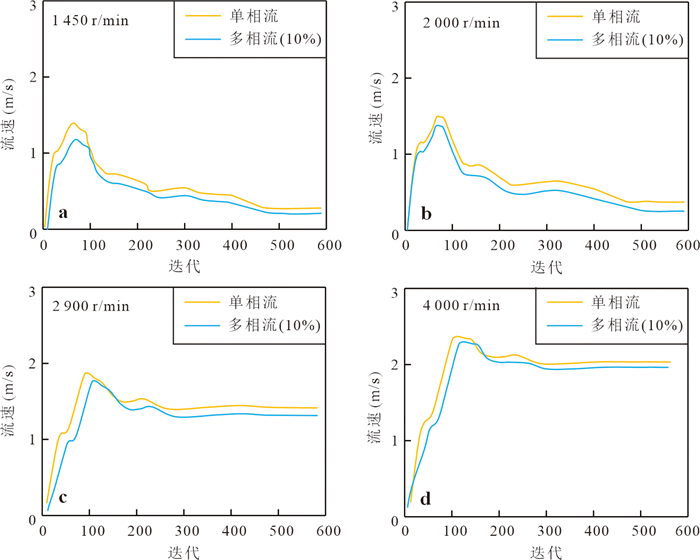
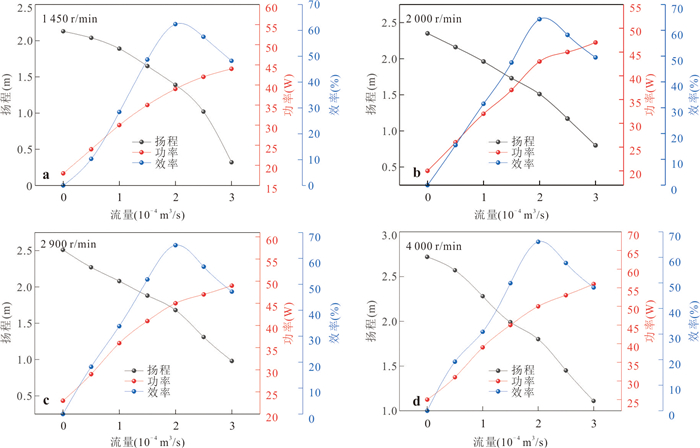
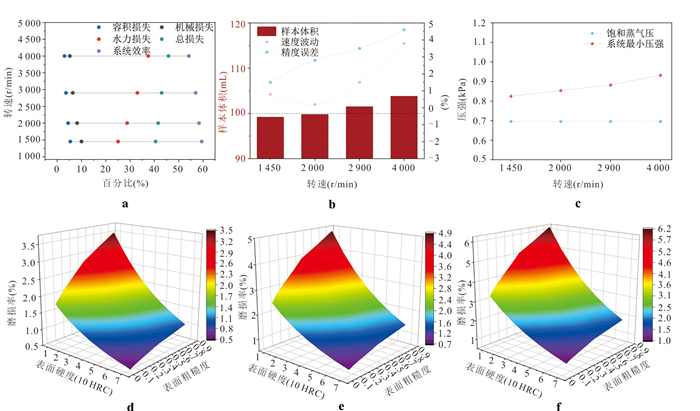
To enhance the stability and efficiency of the in-situ fluid sampling system for deep-sea drilling, this study, based on computational fluid dynamics (CFD) methods, constructed a three-dimensional turbulence model for the sampling centrifugal pump. A systematic analysis was conducted on its pressure distribution, velocity field, drag characteristics, and energy loss patterns within the rotational speed range of 1 450 r/min to 4 000 r/min. The results indicate that 2 000 r/min is the optimal rotational speed. At this speed, the pressure field within the pump reaches 8 030 Pa and is most stable, with a maximum flow velocity of 3.46 m/s and a reasonable velocity distribution. Furthermore, at this speed, the difference in drag coefficients between multiphase flow and single-phase flow is minimal, and the flow rate fluctuation is only 0.23%. The maximum error in sampling volume is 4.75%, demonstrating excellent flow stability and sampling accuracy. In terms of efficiency, the peak efficiency of the pump is approximately 62.7%, corresponding to an optimal flow rate of 2×10⁻⁴ m3/s. Additionally, the pump body is constructed from titanium alloy and the flow rate is controlled within the high-efficiency range, ensuring long-term reliable operation of the pump in complex deep-sea media environments.
To enhance the stability and efficiency of the in-situ fluid sampling system for deep-sea drilling, this study, based on computational fluid dynamics (CFD) methods, constructed a three-dimensional turbulence model for the sampling centrifugal pump. A systematic analysis was conducted on its pressure distribution, velocity field, drag characteristics, and energy loss patterns within the rotational speed range of 1 450 r/min to 4 000 r/min. The results indicate that 2 000 r/min is the optimal rotational speed. At this speed, the pressure field within the pump reaches 8 030 Pa and is most stable, with a maximum flow velocity of 3.46 m/s and a reasonable velocity distribution. Furthermore, at this speed, the difference in drag coefficients between multiphase flow and single-phase flow is minimal, and the flow rate fluctuation is only 0.23%. The maximum error in sampling volume is 4.75%, demonstrating excellent flow stability and sampling accuracy. In terms of efficiency, the peak efficiency of the pump is approximately 62.7%, corresponding to an optimal flow rate of 2×10⁻⁴ m3/s. Additionally, the pump body is constructed from titanium alloy and the flow rate is controlled within the high-efficiency range, ensuring long-term reliable operation of the pump in complex deep-sea media environments.
2026, 51(8): 3224-3235.
doi: 10.3799/dqkx.2026.098
Abstract:
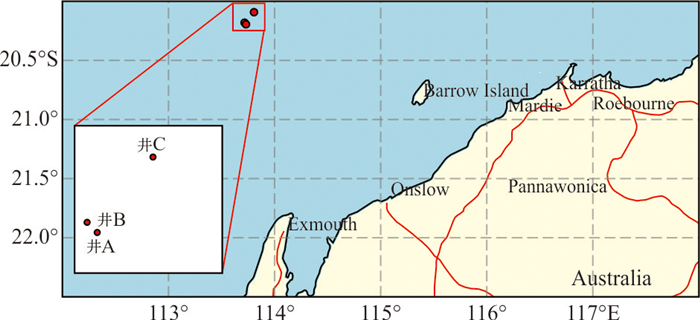
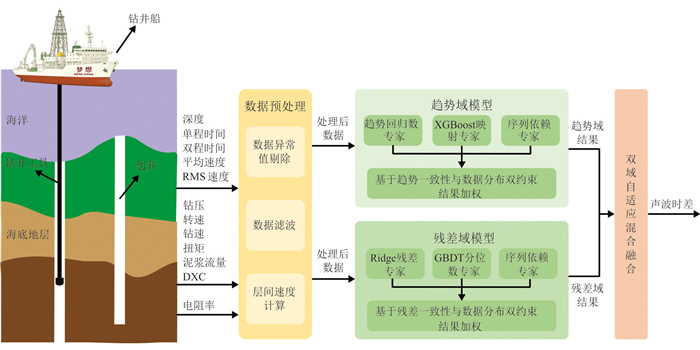
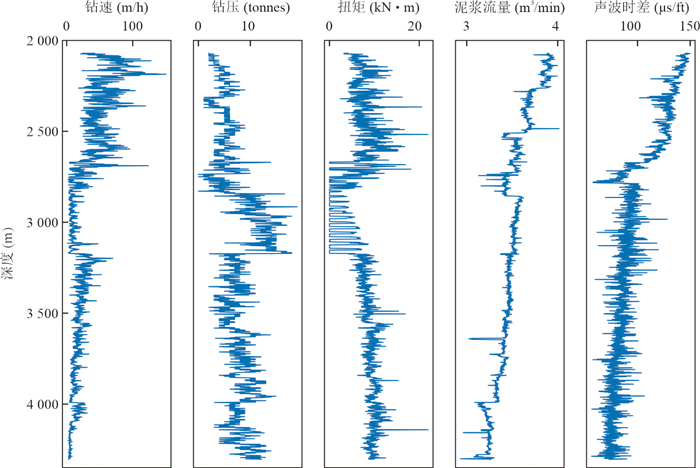
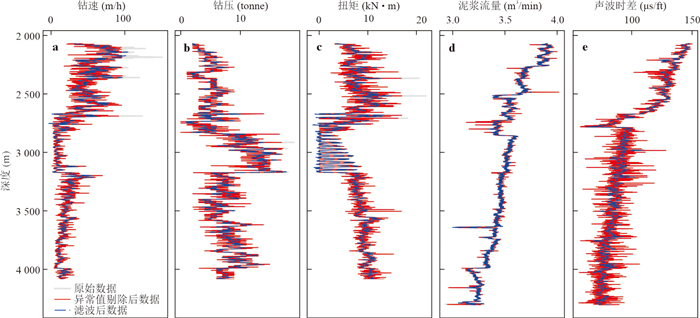
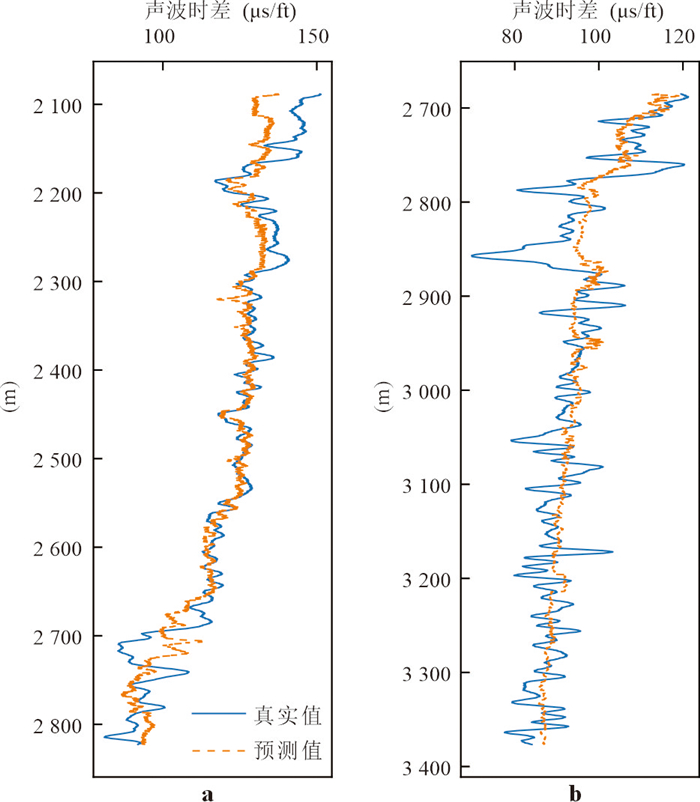
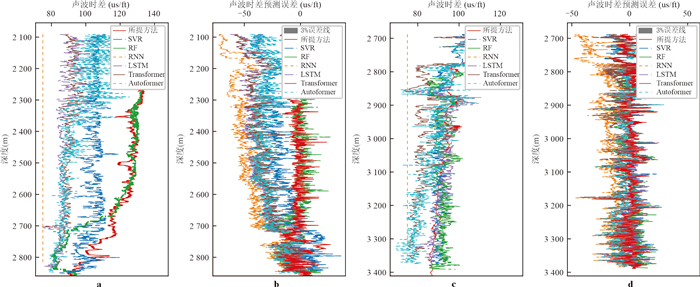
In deepwater drilling operations, the acquisition of logging parameters such as sonic transit time (DTCO) is associated with high cost and operational constraints, while conventional data-driven soft-sensing methods often exhibit limited generalization capability in cross-well applications. To address these challenges, this study proposes adual-domain adaptive mixture-of-experts-based soft measurement method for sonic transit time in deep-sea drilling processes. This method integrates multi-source drilling data and constructs separate multi-expert soft measurement models for acoustic travel time based on low-frequency migratory trend domains and high-frequency residual domains. Building on this, adaptive mixed weights are introduced to dynamically assess the reliability of the two domains using multi-source unsupervised signals, thereby achieving adaptive fusion of acoustic travel times. Comparative experiments conducted on multiple real drilling datasets demonstrate that the proposed method consistently outperforms benchmark models, including SVR, RF, RNN, LSTM, and Transformer, in terms of cross-well prediction accuracy and stability, achieving an average error reduction of approximately 15%. This method effectively balances prediction accuracy with the stability of cross-well application whilst relying solely on pre-drilling exploration and drilling data, and is suitable for real-time sonic transit time soft measurement in deep-sea drilling environments.
In deepwater drilling operations, the acquisition of logging parameters such as sonic transit time (DTCO) is associated with high cost and operational constraints, while conventional data-driven soft-sensing methods often exhibit limited generalization capability in cross-well applications. To address these challenges, this study proposes adual-domain adaptive mixture-of-experts-based soft measurement method for sonic transit time in deep-sea drilling processes. This method integrates multi-source drilling data and constructs separate multi-expert soft measurement models for acoustic travel time based on low-frequency migratory trend domains and high-frequency residual domains. Building on this, adaptive mixed weights are introduced to dynamically assess the reliability of the two domains using multi-source unsupervised signals, thereby achieving adaptive fusion of acoustic travel times. Comparative experiments conducted on multiple real drilling datasets demonstrate that the proposed method consistently outperforms benchmark models, including SVR, RF, RNN, LSTM, and Transformer, in terms of cross-well prediction accuracy and stability, achieving an average error reduction of approximately 15%. This method effectively balances prediction accuracy with the stability of cross-well application whilst relying solely on pre-drilling exploration and drilling data, and is suitable for real-time sonic transit time soft measurement in deep-sea drilling environments.
2026, 51(8): 3236-3250.
doi: 10.3799/dqkx.2022.386
Abstract:
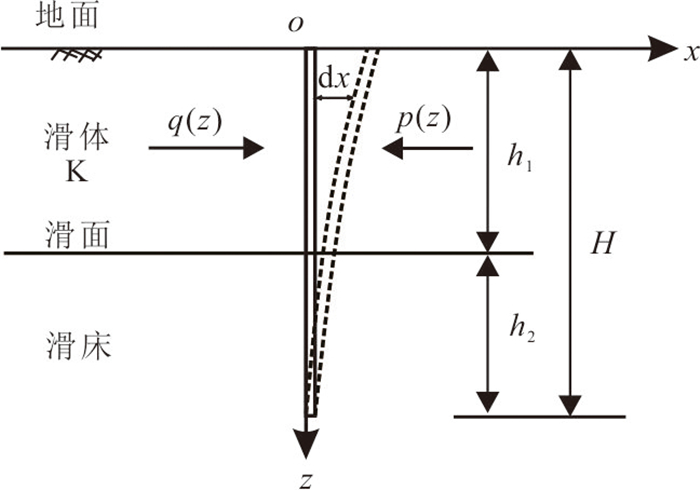
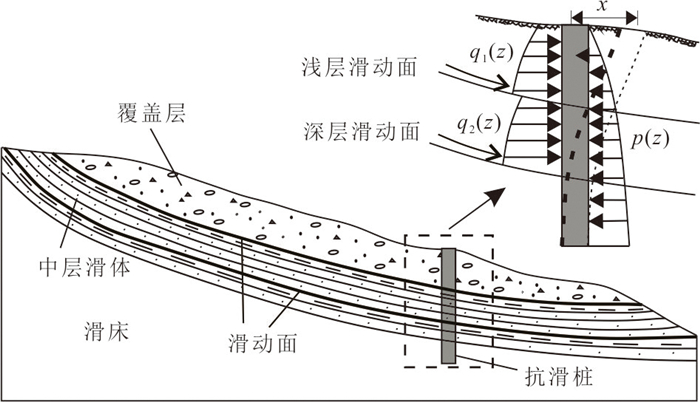
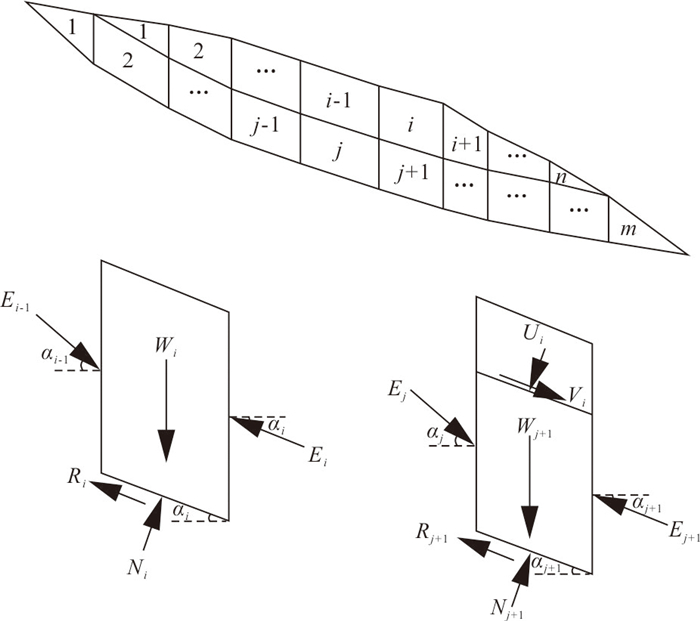
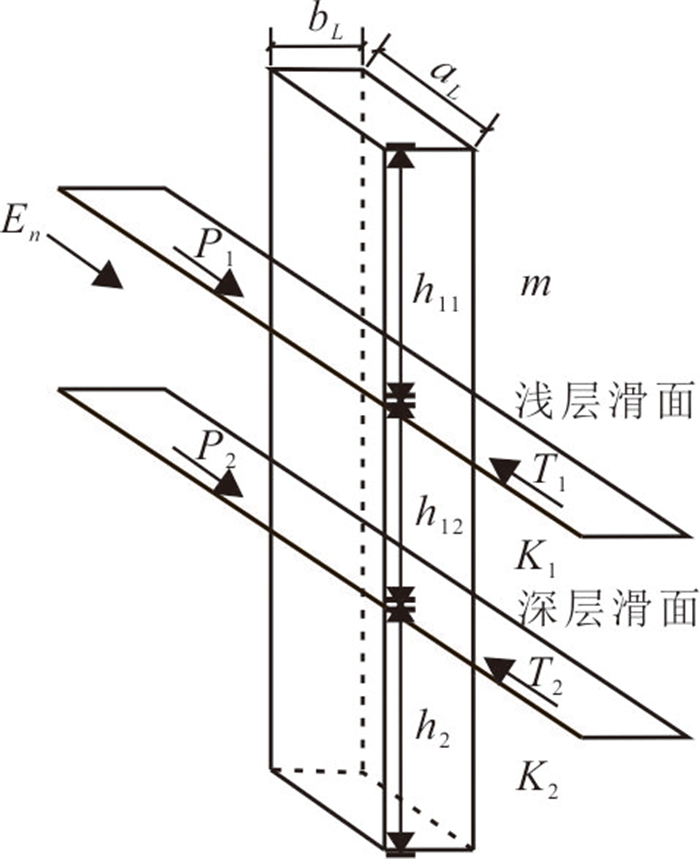
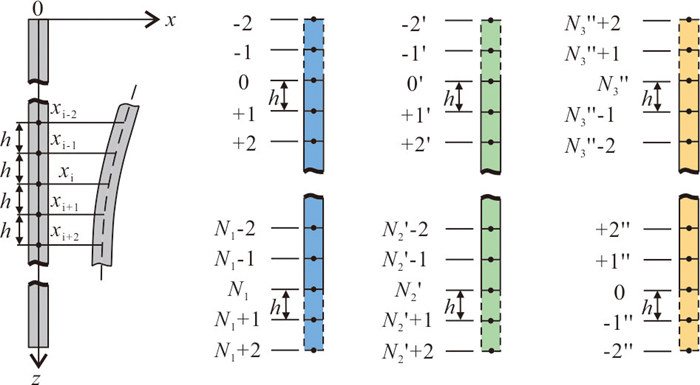
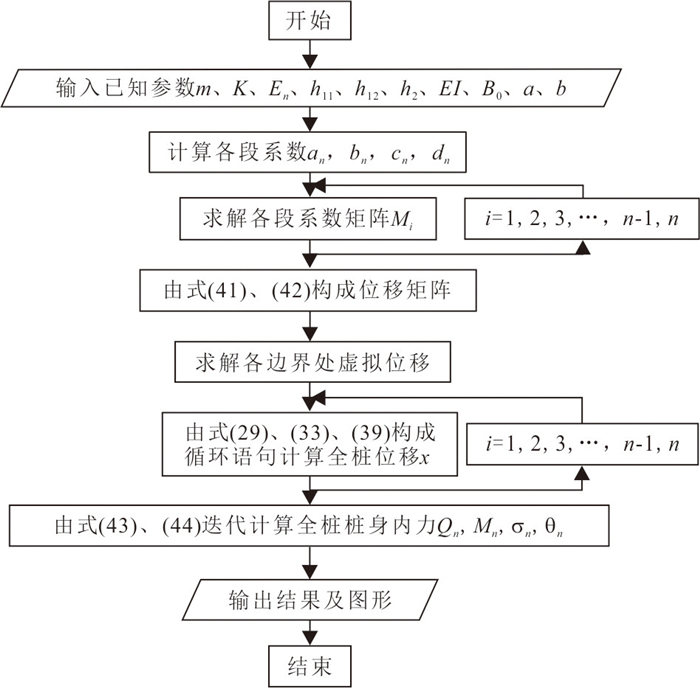
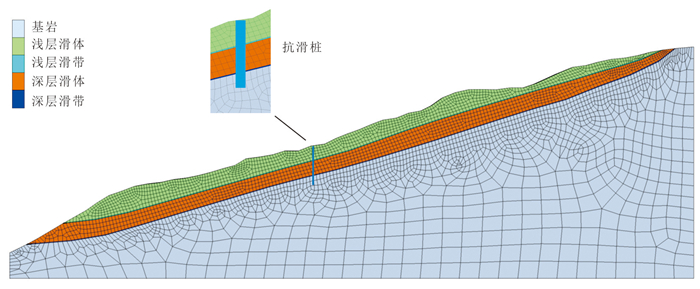
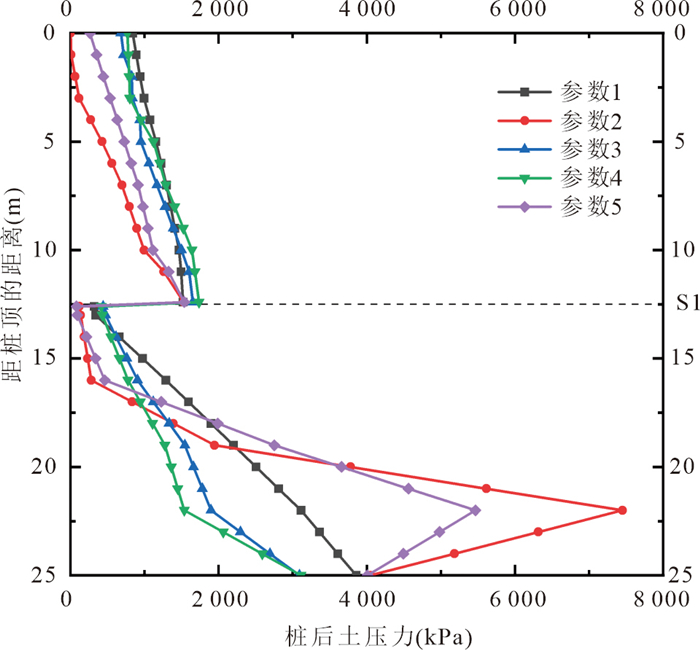
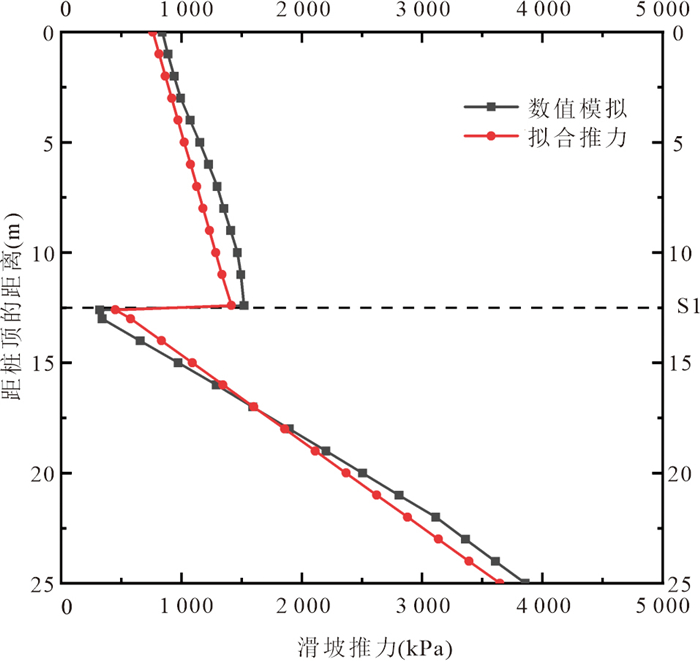
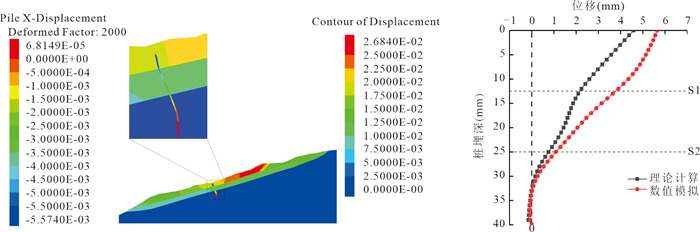
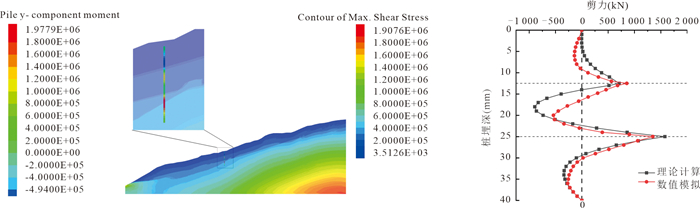
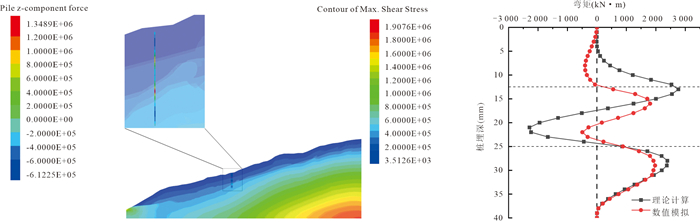
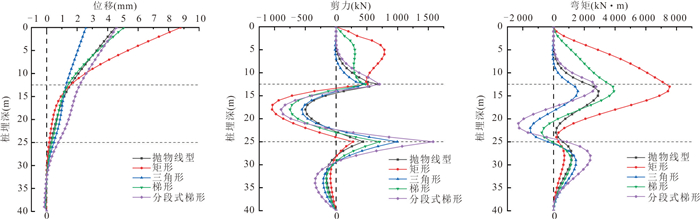
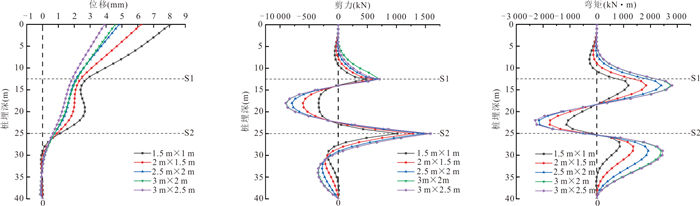
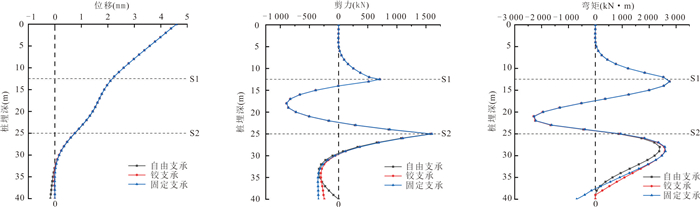
Existing theoretical analysis of the deformation and internal force of anti-sliding piles are mostly designed for single-sliding zone landslides, while most of the accumulation layer landslides in the Three Gorges reservoir area develop double sliding zones. Considering the difference in material composition of landslides with double sliding zones, a generalized model for the interaction between landslides with double sliding zones and anti-sliding is constructed. to study the internal force and deformation of anti-sliding piles. Then a calculation method of landslide thrust under double-layer sliding condition is proposed to derive the equations of deformation and internal force of anti-slide pile in landslides with double sliding zones based on the foundation coefficient method and the finite difference principle. Numerical simulation method was used to research the distribution laws of landslide thrust and verify the newly proposed approach via the Majiagou landslide as example. The results of the theoretical and numerical simulation methods well show the sliding characteristics of landslides with double sliding zones. Meanwhile, the distribution of the deformation and internal forces show a great regularity: the displacement of the pile decreases gradually from the top to bottom accompanied by reverse bending phenomenon, the shear force and bending moment of the pile exist two maximum values and one minimum value, and the maximum values of the shear force are located at the sliding surface while the maximum values of the bending moment are located 2~3 m below the sliding surface, and the minimum value is located in the deep sliding body. In addition, the distribution of landslide thrust and the vital design parameters of anti-sliding piles are important factors that affect the mechanical characteristics of the pile. The proposed method can provide a theoretical reference for the design of anti-sliding piles of landslide with double sliding zones.
Existing theoretical analysis of the deformation and internal force of anti-sliding piles are mostly designed for single-sliding zone landslides, while most of the accumulation layer landslides in the Three Gorges reservoir area develop double sliding zones. Considering the difference in material composition of landslides with double sliding zones, a generalized model for the interaction between landslides with double sliding zones and anti-sliding is constructed. to study the internal force and deformation of anti-sliding piles. Then a calculation method of landslide thrust under double-layer sliding condition is proposed to derive the equations of deformation and internal force of anti-slide pile in landslides with double sliding zones based on the foundation coefficient method and the finite difference principle. Numerical simulation method was used to research the distribution laws of landslide thrust and verify the newly proposed approach via the Majiagou landslide as example. The results of the theoretical and numerical simulation methods well show the sliding characteristics of landslides with double sliding zones. Meanwhile, the distribution of the deformation and internal forces show a great regularity: the displacement of the pile decreases gradually from the top to bottom accompanied by reverse bending phenomenon, the shear force and bending moment of the pile exist two maximum values and one minimum value, and the maximum values of the shear force are located at the sliding surface while the maximum values of the bending moment are located 2~3 m below the sliding surface, and the minimum value is located in the deep sliding body. In addition, the distribution of landslide thrust and the vital design parameters of anti-sliding piles are important factors that affect the mechanical characteristics of the pile. The proposed method can provide a theoretical reference for the design of anti-sliding piles of landslide with double sliding zones.