
- 中文版:
- EI 100%收录
- 英文版
- SCI 100%收录


中国出版政府奖提名奖
中国百强科技报刊
湖北出版政府奖
中国高校百佳科技期刊
中国最美期刊
中国出版政府奖提名奖
中国百强科技报刊
湖北出版政府奖
中国高校百佳科技期刊
中国最美期刊
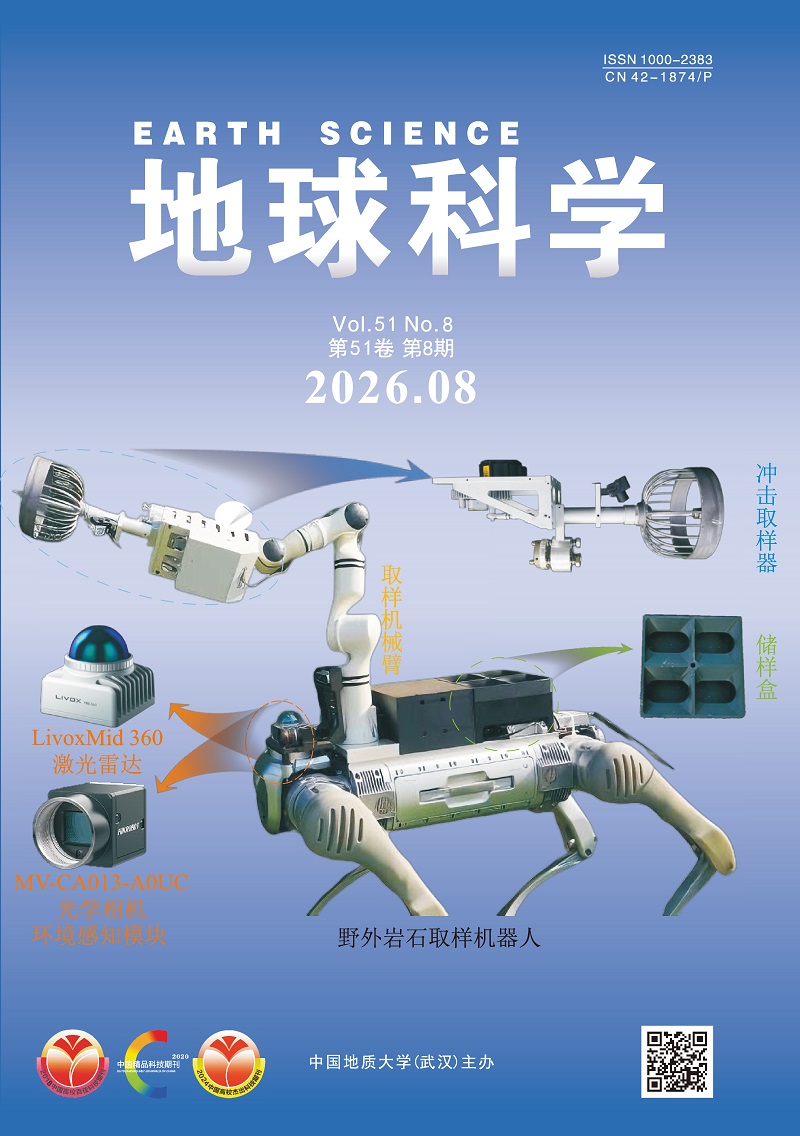
| Citation: | He Jiaqi, Wang Meng, Chen Chun, Cao Weihua, Li Yupeng, Zhang Zhiwu, Chen Yongqiao, Li Yan, Wang Yingchao, 2026. Multimodal Fusion Perception for Rock Sampling Robot in Field Environments. Earth Science, 51(8): 2927-2939. doi: 10.3799/dqkx.2026.057

|

|
Bar, A., Lohdefink, J., Kapoor, N., et al., 2020. The Vulnerability of Semantic Segmentation Networks to Adversarial Attacks in Autonomous Driving: Enhancing Extensive Environment Sensing. IEEE Signal Processing Magazine, 38(1): 42-52. https://doi.org/10.1109/msp.2020.2983666
|
|
Cadena, C., Carlone, L., Carrillo, H., et al., 2016. Past, Present, and Future of Simultaneous Localization and Mapping: Toward the Robust-Perception Age. IEEE Transactions on Robotics, 32(6): 1309-1332. https://doi.org/10.1109/tro.2016.2624754
|
|
Campos, C., Elvira, R., Rodriguez, J. J. G., et al., 2021. ORB-SLAM3: An Accurate Open-Source Library for Visual, Visual-Inertial, and Multimap SLAM. IEEE Transactions on Robotics, 37(6): 1874-1890. https://doi.org/10.1109/tro.2021.3075644
|
|
Engel, J., Koltun, V., Cremers, D., 2017. Direct Sparse Odometry, IEEE Transactions on Pattern Analysis and Machine Intelligence, 40(3): 611-625.
|
|
El Madawi, K., Rashed, H., El Sallab, A., et al., 2019. RGB and Lidar Fusion Based 3D Semantic Segmentation for Autonomous Driving. IEEE Intelligent Transportation Systems Conference(ITSC), Piscataway, N. J., Institute of Electrical and Electronics Engineers (IEEE), USA, 7-12.
|
|
Forster, C., Zhang, Z. C., Gassner, M., et al., 2016. SVO: Semidirect Visual Odometry for Monocular and Multicamera Systems. IEEE Transactions on Robotics, 33(2): 249-265. https://doi.org/10.1109/tro.2016.2623335
|
|
Gorai, A. K., Raval, S., Patel, A. K., et al., 2021. Design and Development of a Machine Vision System Using Artificial Neural Network-Based Algorithm for Automated Coal Characterization. International Journal of Coal Science & Technology, 8(4): 737-755. https://doi.org/10.1007/s40789-020-00370-9
|
|
Guo, Y. F., Xu, P., Li W., et al., 2025. 3D Perception and Reconstruction of Underground Coal Mine Roadways Based on Multi-Sensor Fusion. Earth Science. doi: 10.3799/dqkx.2025.274 (in Chinese with English abstract).
|
|
Hu, Q. Y., Yang, B., Xie, L. H., et al., 2021. Learning Semantic Segmentation of Large-Scale Point Clouds with Random Sampling. IEEE Transactions on Pattern Analysis and Machine Intelligence, 25: 1-1. https://doi.org/10.1109/tpami.2021.3083288
|
|
Lin, J. R., Zheng, C. R., Xu, W., et al., 2021. R $^2$ LIVE: A Robust, Real-Time, LiDAR-Inertial-Visual Tightly-Coupled State Estimator and Mapping. IEEE Robotics and Automation Letters, 6(4): 7469-7476. https://doi.org/10.1109/lra.2021.3095515
|
|
Li, K. L., Li, M., Hanebeck, U. D., 2021. Towards High-Performance Solid-State-LiDAR-Inertial Odometry and Mapping. IEEE Robotics and Automation Letters, 6(3): 5167-5174. https://doi.org/10.1109/lra.2021.3070251
|
|
Liu, X., Gong, G., Hu, X., et al., 2024. Cognitive Enhancement of Robot Path Planning and Environmental Perception Based on Gmapping Algorithm Optimization, Electronics, 13(5): 818(in Chinese with English abstract). doi: 10.3390/electronics13050818
|
|
Lin, F. F., Lin, T. L., Yao, Y., et al., 2025. VPA-Net: A Visual Perception Assistance Network for 3d Lidar Semantic Segmentation. Pattern Recognition, 158: 111014. https://doi.org/10.1016/j.patcog.2024.111014
|
|
Liu, H. W., Xu, G. Q., Liu, B., et al., 2025. A Real Time LiDAR-Visual-Inertial Object Level Semantic SLAM for Forest Environments. ISPRS Journal of Photogrammetry and Remote Sensing, 219: 71-90. https://doi.org/10.1016/j.isprsjprs.2024.11.013
|
|
Mur-Artal, R., Montiel, J. M. M., Tardos, J. D., 2015. ORB-SLAM: A Versatile and Accurate Monocular SLAM System. IEEE Transactions on Robotics, 31(5): 1147-1163. https://doi.org/10.1109/tro.2015.2463671
|
|
Pan, B. W., Sun, J. K., Leung, H. Y. T., et al., 2020. Cross-View Semantic Segmentation for Sensing Surroundings. IEEE Robotics and Automation Letters, 5(3): 4867-4873. https://doi.org/10.1109/lra.2020.3004325
|
|
Pang, Y. E., Li, X., Dong, Z. K., et al., 2024. Convolutional Neural Network-Based Model for Recognizing TBM Rock Chip Gradation. Automation in Construction, 163(1): 105414. https://doi.org/10.1016/j.autcon.2024.105414
|
|
Qin, T., Li, P. L., Shen, S. J., 2018. VINS-Mono: A Robust and Versatile Monocular Visual-Inertial State Estimator. IEEE Transactions on Robotics, 34(4): 1004-1020. https://doi.org/10.1109/tro.2018.2853729
|
|
Sun, K., Mohta, K., Pfrommer, B., et al., 2018. Robust Stereo Visual Inertial Odometry for Fast Autonomous Flight. IEEE Robotics and Automation Letters, 3(2): 965-972. https://doi.org/10.1109/lra.2018.2793349
|
|
Shin, Y. S., Park, Y. S., Kim, A., 2020. DVL-SLAM: Sparse Depth Enhanced Direct Visual-LiDAR SLAM. Autonomous Robots, 44(2): 115-130. https://doi.org/10.1007/s10514-019-09881-0
|
|
Wang, Y. Z., Sun, S. Y., 2021. Image-Based Rock Typing Using Grain Geometry Features. Computers & Geosciences, 149: 104703. https://doi.org/10.1016/j.cageo. 2021.104703 doi: 10.1016/j.cageo.2021.104703
|
|
Wang, Y., Zhang, J., Chen, Y. H., et al., 2024. An Automated Learning Method of Semantic Segmentation for Train Autonomous Driving Environment Understanding. IEEE Transactions on Industrial Informatics, 20(4): 6913-6922. https://doi.org/10.1109/tii.2024.3353874
|
|
Xie, T., Sun, Q. H., Sun, T., et al., 2025. DVDS: A Deep Visual Dynamic Slam System. Expert Systems with Applications, 260(10): 125438. https://doi.org/10.1016/j.eswa.2024.125438
|
|
Xu, X. B., Zhang, L., Yang J., et al., 2022. A Review of Multi-Sensor Fusion SLAM Systems Based on 3D LIDAR. Remote Sensing, 14(12): 2835. https://doi.org/10.3390/rs14122835
|
|
Xu, K., Hao, Y. F., Yuan, S. H., et al., 2025. AirSLAM: An Efficient and Illumination-Robust Point-Line Visual SLAM System. IEEE Transactions on Robotics, 41(5): 1673-1692. https://doi.org/10.1109/tro.2025.3539171
|
|
Yan, X., Gao, J., Zheng, C., et al., 2022. 2DPASS: 2D Priors Assisted Semantic Segmentation on Lidar Point Clouds. European Conference on Computer Vision (ECCV), Springer, Berlin, Germany, 677-695.
|
|
Yang, J. T., Kang, Z. Z., Yang, Z., et al., 2022. A Laboratory Open-Set Martian Rock Classification Method Based on Spectral Signatures. IEEE Transactions on Geoscience and Remote Sensing, 60: 1-15. https://doi.org/10.1109/tgrs.2022.3175996
|
|
Yao, X., Shi, J., Chen, J., et al., 2024. From Direct Exploration to AI Exploration: Evolution and Insight, Development and Research Centre, 15(4): 671-679 (in Chinese with English abstract).
|
|
Zhang, J., Kaess, M., Singh, S., 2017. A Real-Time Method for Depth Enhanced Visual Odometry. Autonomous Robots, 41(1): 31-43. https://doi.org/10.1007/s10514-015-9525-1
|
|
Zhang, J., Singh, S., 2018. Laser-Visual-Inertial Odometry and Mapping with High Robustness and Low Drift. Journal of Field Robotics, 35(8): 1242-1264. https://doi.org/10.1002/rob.21809
|
|
Zhao, L., Zhou, H., Zhu, X. G., et al., 2023. LIF-Seg: LiDAR and Camera Image Fusion for 3D LiDAR Semantic Segmentation. IEEE Transactions on Multimedia, 26: 1158-1168. https://doi.org/10.1109/tmm.2023.3277281
|
|
Zhu, H., Pan, B., Wu, W., et al., 2023. A Review of Rock Mass Discontinuity Information Collection and Identification Methods, Journal of Basic Science and Engineering, 31(6): 1339-1360 (in Chinese with English abstract).
|
|
Zhang, S., Shan, J. J., Liu, Y. B., 2025. Approximate Inference Particle Filtering for Mobile Robot SLAM. IEEE Transactions on Automation Science and Engineering, 22: 7967-7978. https://doi.org/10.1109/tase.2024.3475735
|
|
郭云飞, 徐鹏, 李伟, 等, 2026. 基于多传感器融合的煤矿井下巷道三维感知与重建方法. 地球科学. doi: 10.3799/dqkx.2025.274
|
|
姚晓峰, 施俊法, 陈骥, 等. 2024. 从"直接找矿"到"智能找矿": 脉络与启示, 矿产勘查, 15(4): 671-679.
|
|
朱合华, 潘柄屹, 武威, 等. 2023. 岩体结构面信息采集及识别方法研究进展, 应用基础与工程科学学报, 31(6): 1339-1360.
|
Figures(7) / Tables(2)

 DownLoad: